系统工程与电子技术 ›› 2026, Vol. 48 ›› Issue (10): 3372-3384.doi: 10.12305/j.issn.1001-506X.2026.10.10
• 传感器与信号处理 • 上一篇
苗青( ), 李武军(), 易伟()
收稿日期:2025-06-13
出版日期:2026-10-25
发布日期:2026-09-30
通讯作者:
李武军
E-mail:MiaoQing313@163.com;1224liwujun@gmail.com;kussoyi@gmail.com
作者简介:苗 青(2000—),女,博士研究生,主要研究方向为雷达信号处理及微弱目标探测基金资助:
Qing Miao(), Wujun Li(), Wei Yi()
Received:2025-06-13
Online:2026-10-25
Published:2026-09-30
Contact:
Wujun Li
E-mail:MiaoQing313@163.com;1224liwujun@gmail.com;kussoyi@gmail.com
摘要:
为解决平台运动及多视角雷达视域错位情况下的车载多雷达系统弱目标跟踪难题,提出车载雷达多帧检测前跟踪方法。提出跨坐标系状态转移范围搜索策略,通过建立不同时刻来自不同雷达量测数据的映射关系,充分利用目标的时空相关性进行能量积累提高信噪比。由于多部雷达的不同分布及视域错位,当目标运动在雷达视域边界,其存在状态可能改变。因此,提出多帧检测架构,可根据目标存在状态自适应调整检测门限。仿真和实测数据处理结果表明,所提算法能有效实现车载多雷达系统对微弱目标的准确跟踪。
中图分类号:
苗青, 李武军, 易伟. 车载多雷达多帧检测前跟踪算法[J]. 系统工程与电子技术, 2026, 48(10): 3372-3384.
Qing Miao, Wujun Li, Wei Yi. Automotive multi-radar multi-frame track-before-detect method[J]. Systems Engineering and Electronics, 2026, 48(10): 3372-3384.
图1
车载多雷达系统中的3个主要坐标系"
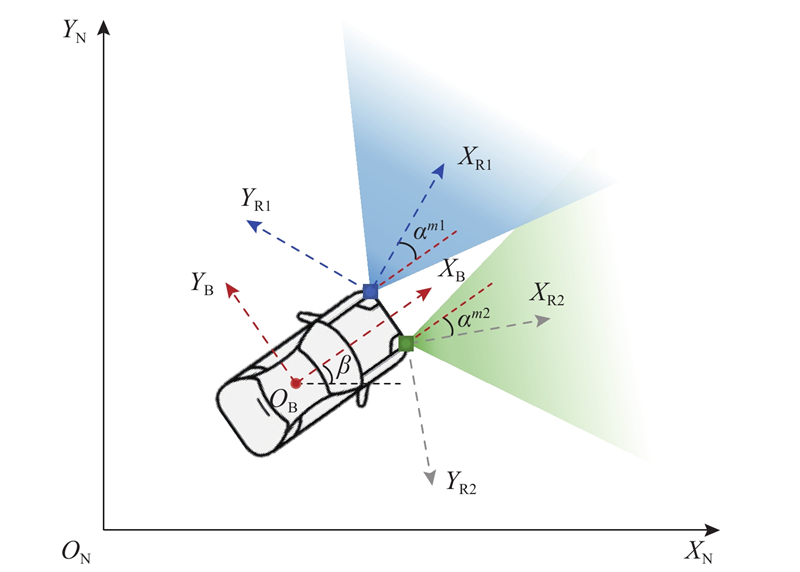
图2
ADT-MS-TBD算法结构框图"
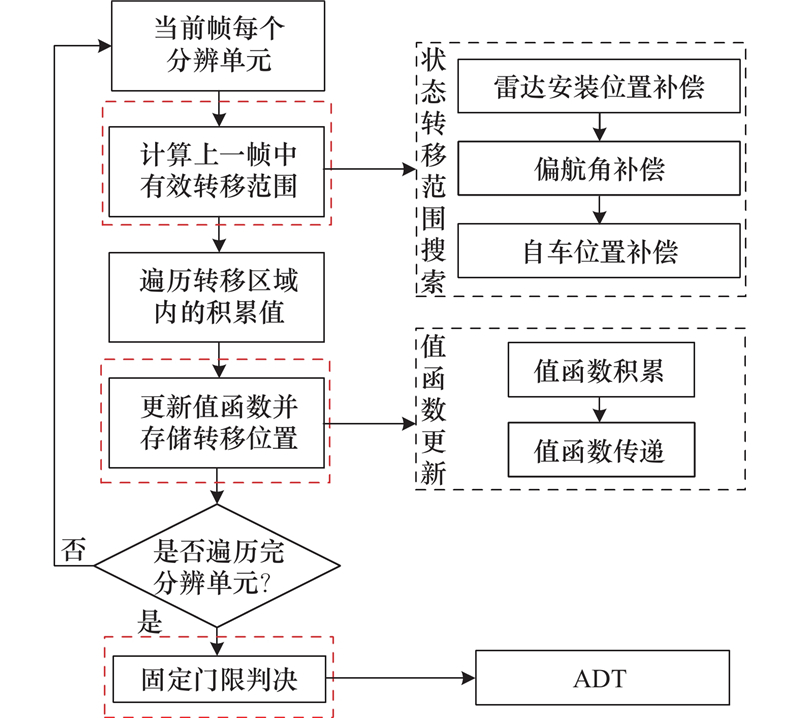
图3
ADT-MS-TBD算法值函数更新过程示意图"
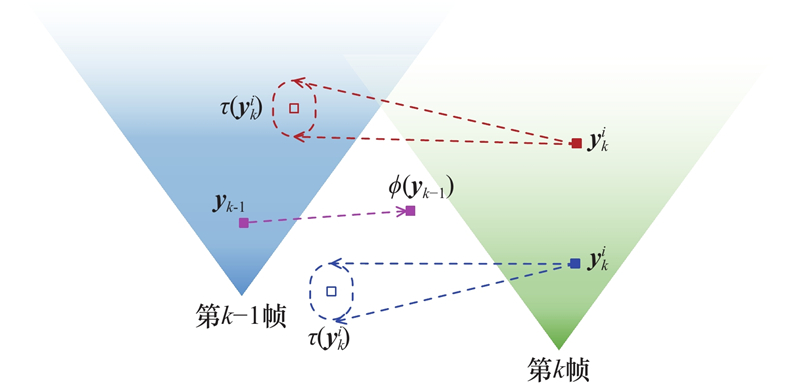
表1
车载多雷达系统仿真参数"
| 参数名称 | 参数值 | 参数名称 | 参数值 | |
| 0.5 | ||||
| 2 | ||||
| 1 |
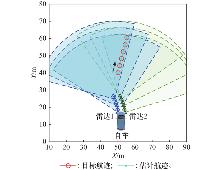
图4
场景1中 ADT-MS-TBD目标航迹估计"
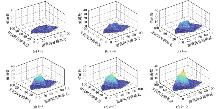
图5
导航坐标系中多帧值函数积累对比"
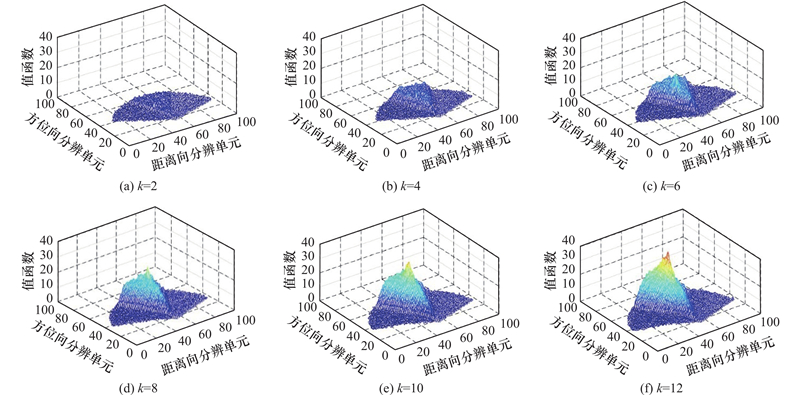
图6
场景1中算法性能对比"
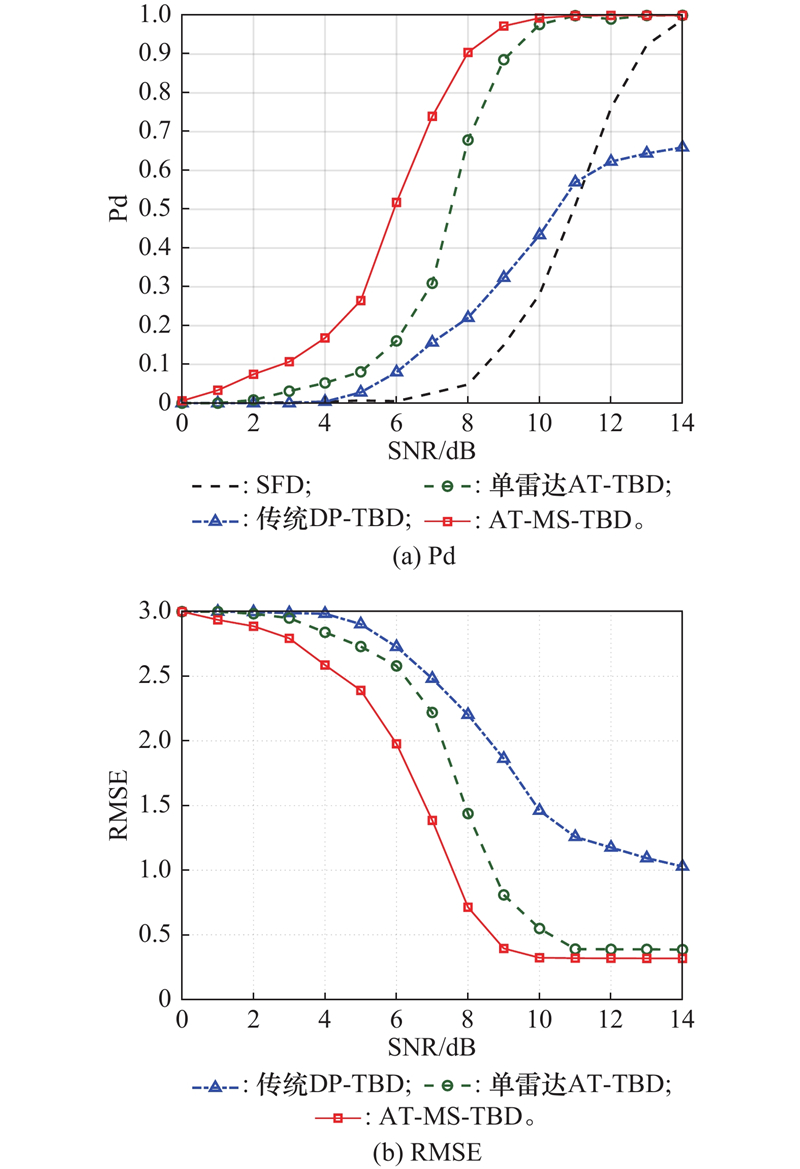
表2
算法的平均运行时间对比"
| 算法 | 量测区域大小 | ||
| 30×30 | 45×45 | 60×60 | |
| ADT-MS-TBD | 0.481 | 0.564 | 0.687 |
| DP-TBD | 0.191 | 0.275 | 0.387 |
| SFD | 0.017 | 0.031 | 0.043 |
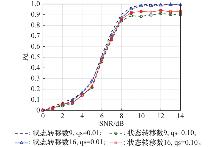
图7
不同状态转移数和过程噪声下ADT-MS-TBD算法"
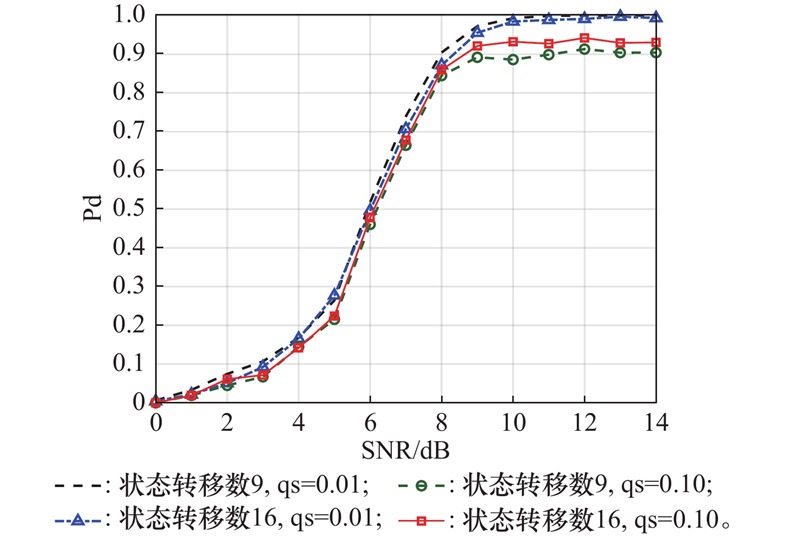
图8
ADT-MS-TBD算法对视域边界目标的跟踪结果"
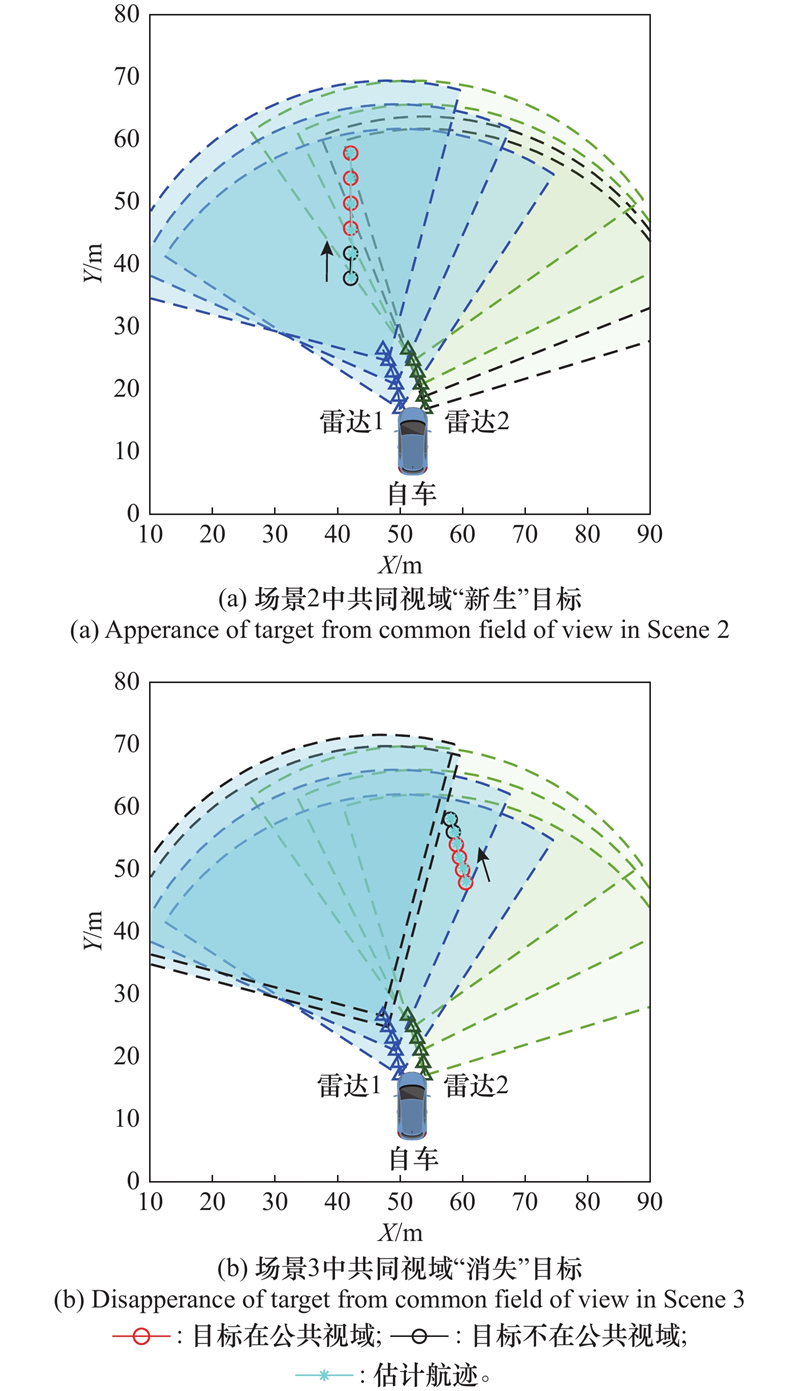
图9
场景2中ADT-MS-TBD与单雷达AT-TBD算法性能对比"
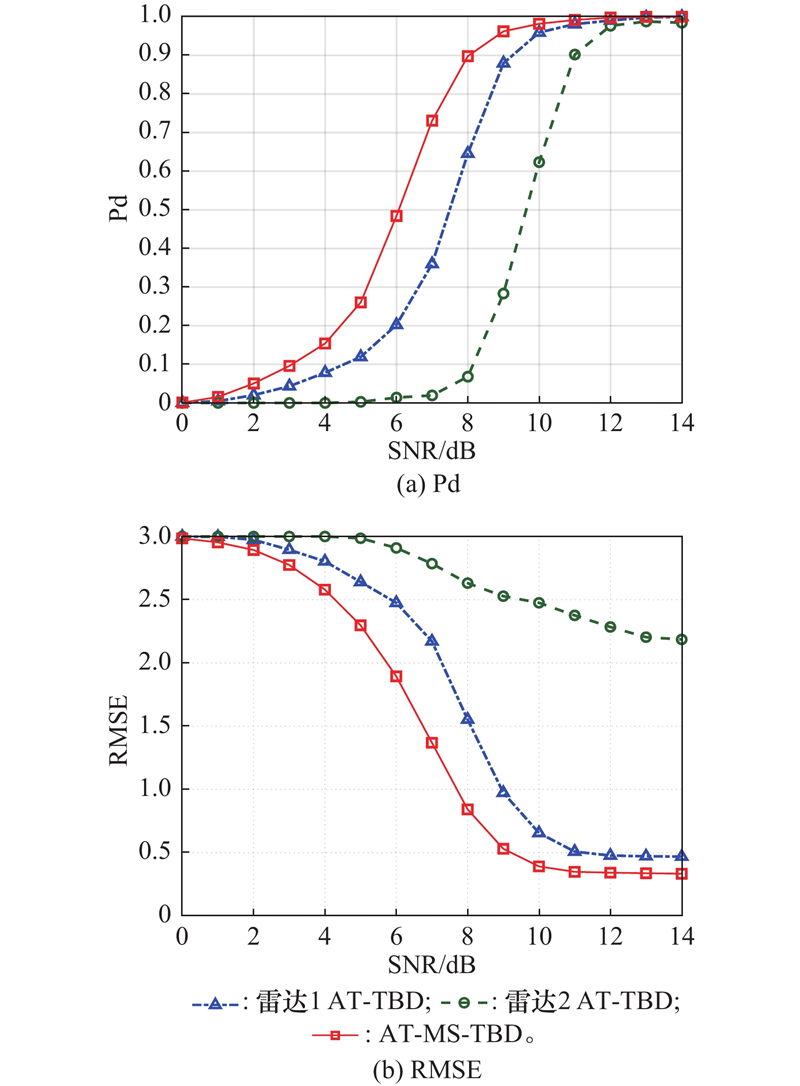
图10
场景3中ADT-MS-TBD与单雷达AT-TBD算法性能对比"
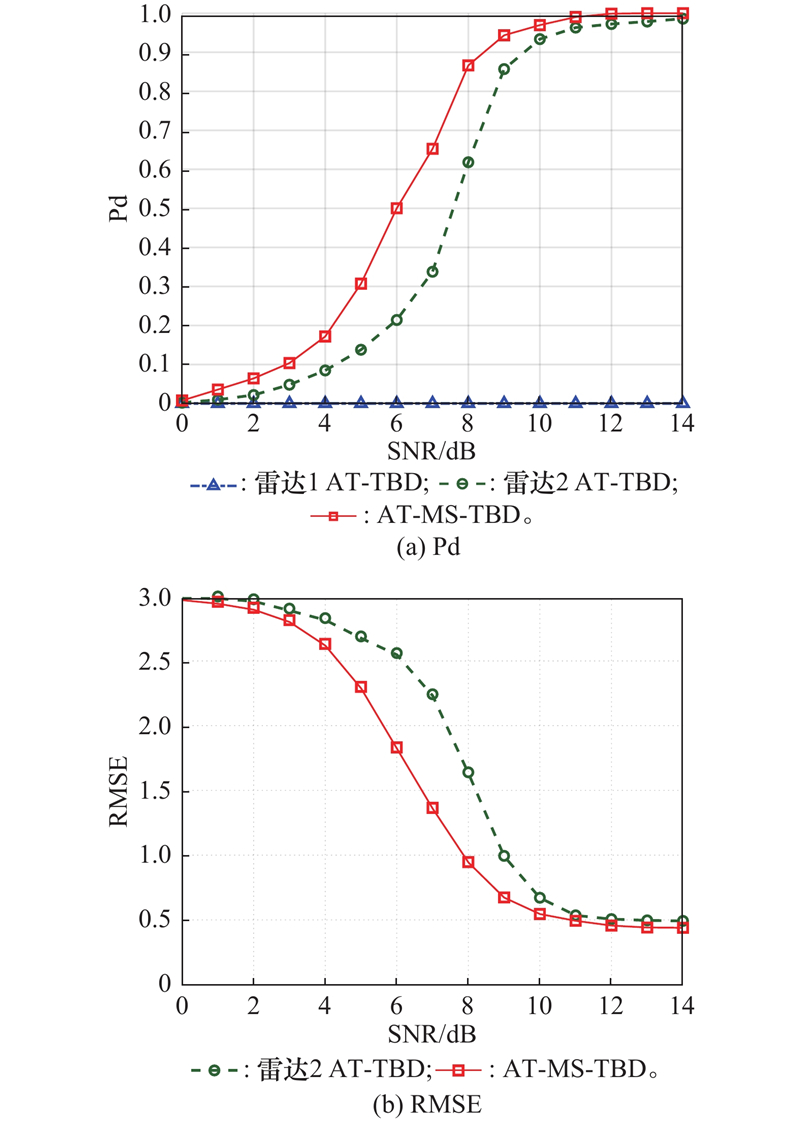
图11
场景4中共同视域内复杂多目标运动情形"
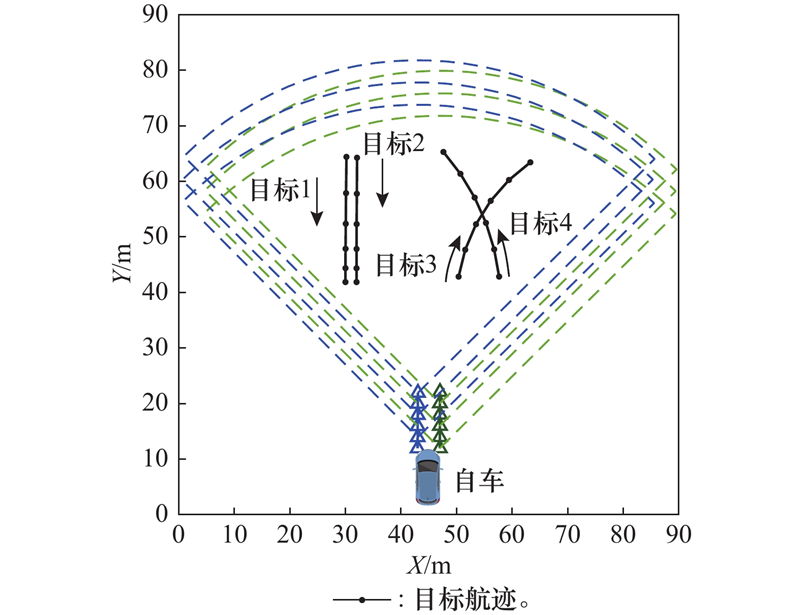
图12
ADT-MS-TBD复杂多目标场景跟踪曲线"
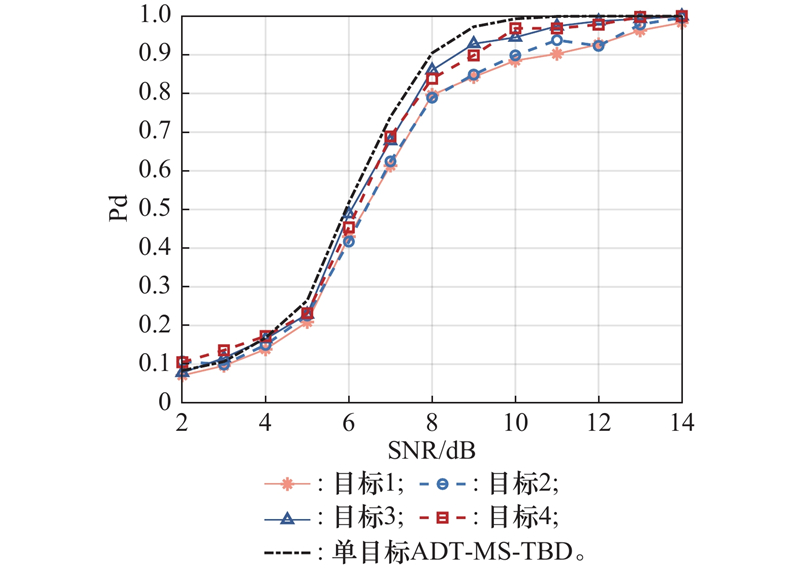
图13
RadarScenes数据集中车载多雷达安装示意图"
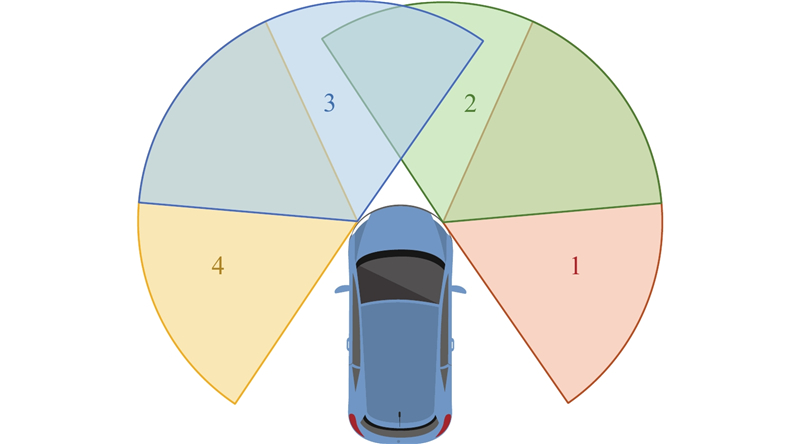
图14
车载多雷达回波量测数据"
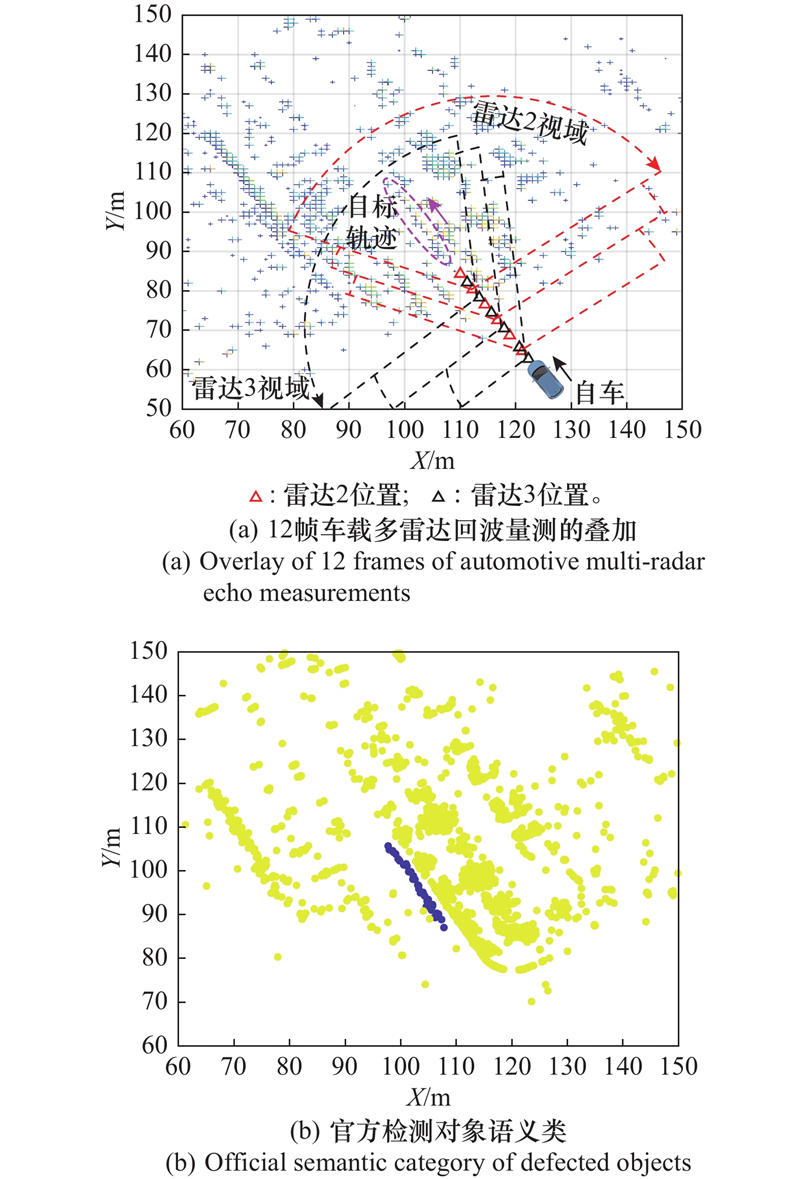
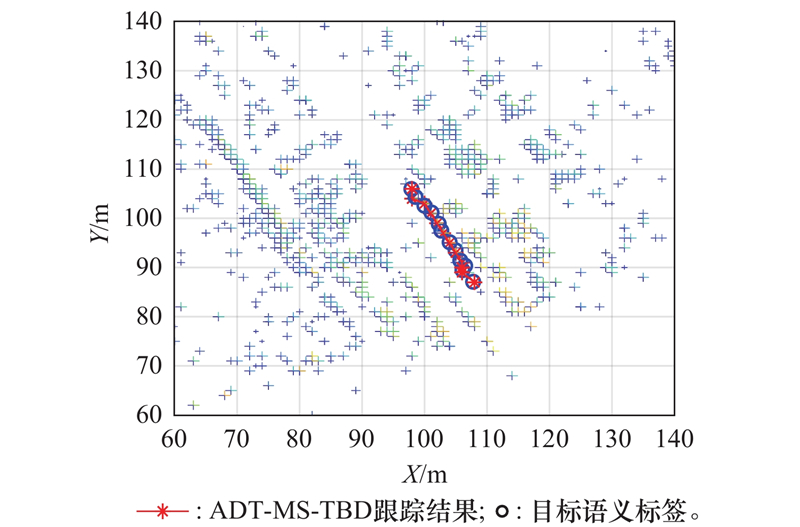
图15
ADT-MS-TBD算法实测数据航迹跟踪结果(设置目标语义标签作为对照)"
| 1 | 党相卫, 秦斐, 卜祥玺, 等. 一种面向智能驾驶的毫米波雷达与激光雷达融合的鲁棒感知算法[J]. 雷达学报, 2021, 10 (4): 622. |
| 2 | 黄岩, 张慧, 兰吕鸿康, 等. 汽车毫米波雷达信号处理技术综述[J]. 雷达学报, 2023, 12 (5): 923. |
| 3 | 郑晶月, 吴佩仑, 陈家辉, 等. 车载毫米波雷达多径假目标分析与消除方法[J]. 系统工程与电子技术, 2024, 46 (1): 88. |
| 4 | Tan B, Zheng J Y, Wu P L, et al. 3-D object detection for multiframe 4-D automotive millimeter-wave radar point cloud[J]. IEEE Sensors Journal, 2023, 23 (15): 16928. |
| 5 |
Held P, Steinhauser D, Koch A, et al. A novel approach for model-based pedestrian tracking using automotive radar[J]. IEEE Trans. on Intelligent Transportation Systems, 2022, 23 (7): 7082.
doi: 10.1109/TITS.2021.3066680 |
| 6 |
Mukherjee S, Wallace A M, Wang S. Predicting vehicle behavior using automotive radar and recurrent neural networks[J]. IEEE Open Journal of Intelligent Transportation Systems, 2021, 2, 254.
doi: 10.1109/OJITS.2021.3105920 |
| 7 | 王海, 徐岩松, 蔡英凤, 等. 基于多传感器融合的智能汽车多目标检测技术综述[J]. 汽车安全与节能学报, 2021, 12 (4): 440. |
| 8 | Chadwick S, Maddern W, Newman P. Distant vehicle detection using radar and vision[C]//International Conference on Robotics and Automation, 2019: 8311. |
| 9 | 李红月. 车载多雷达数据融合技术研究[D]. 成都: 电子科技大学, 2019. |
| 10 |
Ermolaev V T, Semenov V Y, Artukhin I V. Two methods of target detection in an automotive radar against the background of its own noise[J]. Radiophysics and Quantum Electronics, 2023, 65 (12): 934.
doi: 10.1007/s11141-023-10269-5 |
| 11 |
Tian M, Chen Z, Wang H, et al. An intelligent particle filter for infrared dim small target detection and tracking[J]. IEEE Trans. on Aerospace and Electronic Systems, 2022, 58 (6): 5318.
doi: 10.1109/TAES.2022.3169447 |
| 12 |
Davey S J. Comments on “Joint detection and estimation of multiple objects from image observations”[J]. IEEE Trans. on Signal Processing, 2012, 60 (3): 1539.
doi: 10.1109/TSP.2011.2173679 |
| 13 |
Cao C H, Zhao Y B. A multi-frame GLMB smoothing based on the image-observation sensor for tracking multiple weak targets using belief propagation[J]. Remote Sensing, 2022, 14 (22): 5666.
doi: 10.3390/rs14225666 |
| 14 | Wang J H, Yi W, Kong L J. Improved DP-TBD methods based on multiple hypothesis testing for target early detection[C]//IEEE International Conference on Information Fusion, 2016: 1406. |
| 15 | 张袁鹏, 郑岱堃, 李昕哲, 等. 基于隐马尔可夫模型的动态规划检测前跟踪算法[J]. 系统工程与电子技术, 2019, 41 (11): 2479. |
| 16 |
Cai J, Wang R, Li M Y, et al. An efficient threshold determination algorithm for DP-TBD based on structural analogy and saddle-point approximation[J]. IEEE Trans. on Aerospace and Electronic Systems, 2023, 59 (6): 8263.
doi: 10.1109/TAES.2023.3301458 |
| 17 |
Li W J, Yi W, Kong L J, et al. An efficient track-before-detect for multi-PRF radars with range and Doppler ambiguities[J]. IEEE Trans. on Aerospace and Electronic Systems, 2022, 58 (5): 4083.
doi: 10.1109/TAES.2022.3158633 |
| 18 | Zhang L, Piao S C, Guo J Y, et al. Multi-frame coherent track-before-detect method for weak tones in passive sonar[J]. Signal Processing, 2024, 220, 1. |
| 19 | Li X, Wang Y, Qi B, et al. Underwater acoustic localization of the long baseline based on track-before-detect[J]. IEEE Geoscience and Remote Sensing Letters, 2023, 20 |
| 20 |
Li W J, Yi W, Teh K C. Greedy integration based multi-frame detection algorithm in radar systems[J]. IEEE Trans. on Vehicular Technology, 2023, 72 (5): 5877.
doi: 10.1109/TVT.2022.3232785 |
| 21 | Li W J, Yi W, Teh K C, et al. Adaptive multi-frame detection algorithm with range-Doppler-azimuth measurements[J]. IEEE Trans. on Geoscience and Remote Sensing, 2022, 60 |
| 22 | Peng Q Y, Yi W, Zeng K, et al. An aircraft-centered multi-frame TBD method for airborne radar systems[C]//IEEE Radar Conference, 2020. |
| 23 |
Chen Y H, Wang Y, Qu F, et al. A graph-based track-before-detect algorithm for automotive radar target detection[J]. IEEE Sensors Journal, 2021, 21 (5): 6587.
doi: 10.1109/JSEN.2020.3042079 |
| 24 | Miao Q, Li W J, Yi W. Track-before-detect for automotive radar using multiple frames with time-varying fields of view[C]//IEEE Radar Conference, 2024. |
| 25 | MIAO Q, ZOU Z Y, LI W J, et al. Track-before-detect for automotive multi-radar systems with time-varying fields of view[C]//Proc. of the International Conference on Information Fusion, 2024. |
| 26 | 王经鹤, 易伟, 孔令讲. 组网雷达多帧检测前跟踪算法研究[J]. 雷达学报, 2019, 8 (4): 490. |
| 27 | Yan B, Paolini E, Xu L, et al. A target detection and tracking method for multiple radar systems[J]. IEEE Trans. on Geoscience and Remote Sensing, 2022, 60, 5114721. |
| 28 |
Li K, Guo Z K, Zhou G J. State estimation in range coordinate using range-only measurements[J]. Journal of Systems Engineering and Electronics, 2022, 33 (3): 497.
doi: 10.23919/JSEE.2022.000050 |
| 29 |
Kim D, Jo K, Lee M, et al. L-shape model switching-based precise motion tracking of moving vehicles using laser scanners[J]. IEEE Trans. on Intelligent Transportation Systems, 2018, 19 (2): 598.
doi: 10.1109/TITS.2017.2771820 |
| 30 | 高畅, 谷丰登, 严俊坤, 等. 多普勒信息辅助的网络化雷达融合检测[J]. 雷达学报, 2023, 12 (3): 500. |
| 31 | Bordonaro S, Willett P, Bar-Shalom Y. Decorrelated unbiased converted measurement Kalman filter[J]. IEEE Trans. on Aerospace and Electronic Systems, 2014, 50 (2): 1431. |
| 32 | Li W J, Miao Q, Yuan Y, et al. Automotive radar multi-frame track-before-detect algorithm considering self-positioning errors[J]. IEEE Trans. on Intelligent Transportation Systems, 2025, 26(9): 13506. |
| 33 | Yi W, Fang Z C, Li W J, et al. Multi-frame track-before-detect algorithm for maneuvering target tracking[J]. IEEE Trans. on Vehicular Technology, 2020, 69(4): 4140. |
| 34 |
Cunto F, Saccomanno F. Calibration and validation of simulated vehicle safety performance at signalized intersections[J]. Accident Analysis and Prevention, 2008, 40 (3): 1171.
doi: 10.1016/j.aap.2008.01.003 |
| 35 |
Orlando D, Venturino L, Lops M, et al. Track-before-detect strategies for STAP radars[J]. IEEE Trans. on Signal Processing, 2010, 58 (2): 933.
doi: 10.1109/TSP.2009.2032991 |
| 36 | Li W, Yi W, Teh K C, et al. Radar multiframe detection in a complicated multitarget environment[J]. IEEE Trans. on Geoscience and Remote Sensing, 2023, 61 |
| 37 | 易伟. 基于检测前跟踪技术的多目标跟踪算法研究[D]. 成都: 电子科技大学, 2012. |
| 38 |
Grossi E, Lops M, Venturino L. A novel dynamic programming algorithm for track-before-detect in radar systems[J]. IEEE Trans. on Signal Processing, 2013, 61 (10): 2608.
doi: 10.1109/TSP.2013.2251338 |
| 39 |
Wang J H, Yi W, Kirubarajan T, et al. An efficient recursive multiframe track-before-detect algorithm[J]. IEEE Trans. on Aerospace and Electronic Systems, 2018, 54 (1): 190.
doi: 10.1109/TAES.2017.2741898 |
| 40 | 张鹏辉. 阵列信号多帧检测前跟踪算法研究与GPU快速实现[D]. 成都: 电子科技大学, 2021. |
| [1] | 梁雨凡, 陈映, 李鑫, 窦凇耀. 基于ACT和Bi-LSTM的多模型交互跟踪算法[J]. 系统工程与电子技术, 2026, 48(6): 1869-1879. |
| [2] | 谢欣辰, 高林, 魏平, 李万春. 基于到达时间差与频率差量测无偏转换的辐射源跟踪算法[J]. 系统工程与电子技术, 2026, 48(3): 751-757. |
| [3] | 刘文岚, 王德伍, 戴金辉, 安强, 窦凇耀. 面向保精度跟踪的主被动雷达网络联合功率分配与节点优选算法[J]. 系统工程与电子技术, 2025, 47(12): 4110-4116. |
| [4] | 李翠芸, 赵泽宇, 张双武. 重尾噪声环境下的自适应TPMBM滤波器[J]. 系统工程与电子技术, 2025, 47(9): 2808-2817. |
| [5] | 于昊天, 关欣. 基于证据推理的航迹关联检验判决方法[J]. 系统工程与电子技术, 2025, 47(9): 2818-2827. |
| [6] | 张家琦, 刘芳, 曾操, 陶海红, 赵诗华. 联合雷达与光电设备的破裂航迹关联方法[J]. 系统工程与电子技术, 2025, 47(9): 2862-2869. |
| [7] | 周晓, 牟新刚, 柯文, 苏盈, 王丽. 自适应IMM-UKF机动目标跟踪算法[J]. 系统工程与电子技术, 2025, 47(8): 2686-2695. |
| [8] | 王俊,孙昕. 改进频率鉴别的载波跟踪环路及性能分析[J]. Journal of Systems Engineering and Electronics, 2012, 34(12): 2438-2443. |
| [9] | 李彬彬, 冯新喜, 王朝英, 雷雨. 基于信息增量的多被动传感器资源分配算法[J]. Journal of Systems Engineering and Electronics, 2012, 34(3): 502-507. |
| [10] | 李达, 胡飞, 郑学合. 数据压缩卡尔曼滤波的多传感器精确配准方法[J]. Journal of Systems Engineering and Electronics, 2011, 33(11): 2363-2367. |
| [11] | 田野, 姬红兵, 欧阳成. 基于距离加权最小二乘的量测数据关联[J]. Journal of Systems Engineering and Electronics, 2011, 33(11): 2353-2358. |
| [12] | 宋君, 赵正予, 周晨, 陈罡. 多基高频天波超视距定位模型[J]. Journal of Systems Engineering and Electronics, 2011, 33(2): 272-275. |
| 阅读次数 | ||||||
|
全文 |
|
|||||
|
摘要 |
|
|||||
