系统工程与电子技术 ›› 2026, Vol. 48 ›› Issue (11): 3861-3871.doi: 10.12305/j.issn.1001-506X.2026.11.17
周瑜, 黄馨源, 李杰, 王祥科
收稿日期:2025-06-19
修回日期:2025-10-02
出版日期:2026-10-25
发布日期:2026-03-16
通讯作者:
李杰
作者简介:周 瑜(1996—),男,博士研究生,主要研究方向为无人机路径规划与控制Yu Zhou, Xinyuan Huang, Jie Li, Xiangke Wang
Received:2025-06-19
Revised:2025-10-02
Online:2026-10-25
Published:2026-03-16
Contact:
Jie Li
摘要:
覆盖路径规划是无人机完成任务的关键。将多区域覆盖路径规划问题建模为旅行商问题,针对单机多区域覆盖路径规划,提出基于可视图和动态规划方法的路径规划算法,解决考虑避障的多区域覆盖搜索问题,实现从原点出发并返回原点的多区域覆盖搜索最短路径规划。针对多机大规模区域覆盖路径规划,提出一种“两阶段”路径规划方法,该方法综合启发式区域分配和滚动时域精确求解,相比于一步优化算法,具有更高的灵活性和计算效率。最后,通过仿真实验和对比分析验证了所提方法的有效性和实用性。
中图分类号:
周瑜, 黄馨源, 李杰, 王祥科. 无人机分散凸区域覆盖路径规划[J]. 系统工程与电子技术, 2026, 48(11): 3861-3871.
Yu Zhou, Xinyuan Huang, Jie Li, Xiangke Wang. Unmanned aerial vehicle coverage path planning for dispersed convex regions[J]. Systems Engineering and Electronics, 2026, 48(11): 3861-3871.
图1
UAV与相机视场示意图"
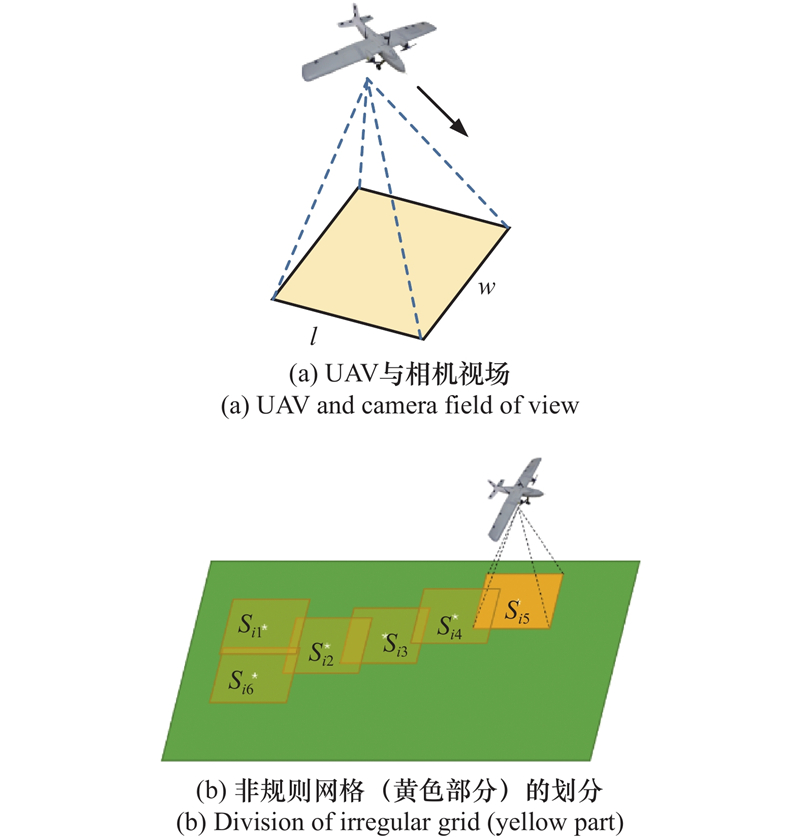
图2
CPP转化成TSP"
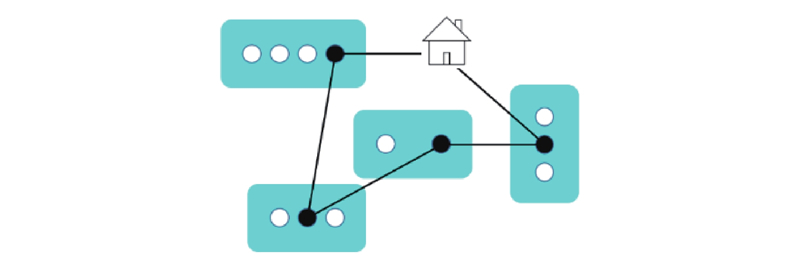
图3
凸多边形的跨度"
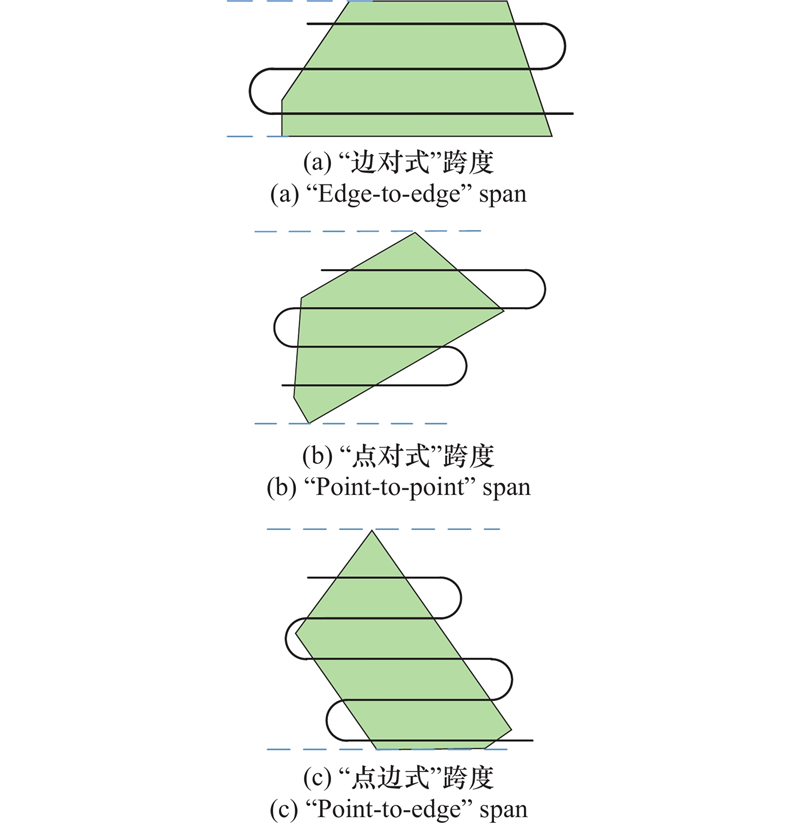
图4
平行于底边的所有候选BFP"
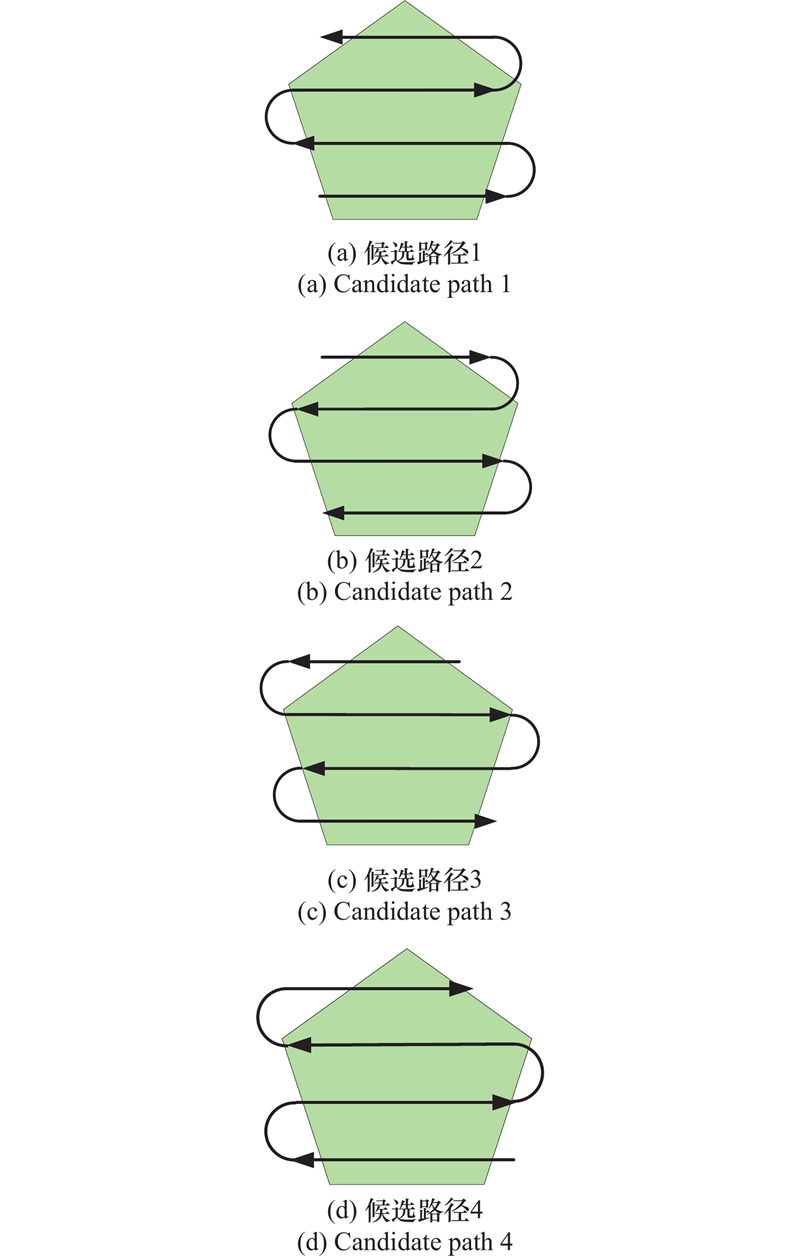
图5
根据相机视场宽度划分跨度示意图"
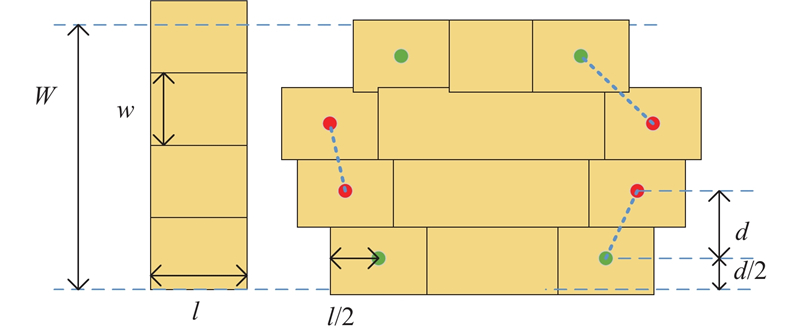
图6
三区域情况DP状态转移过程"
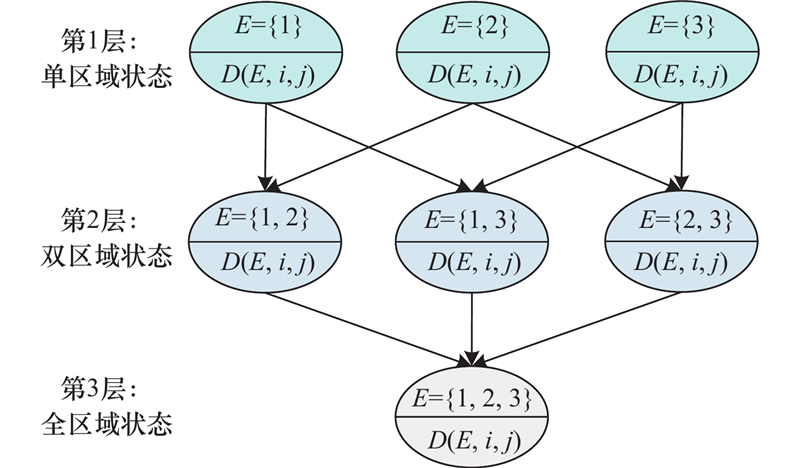
图7
两个区域的部分候选路径计算示意图"
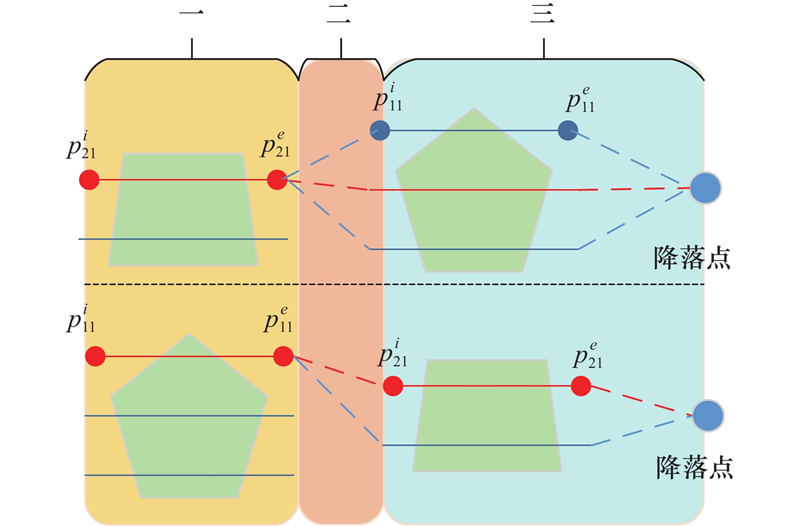
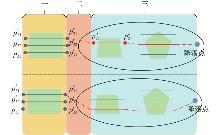
图8
3个区域的部分候选路径计算示意图"
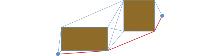
图9
两障碍物之间的可视图"
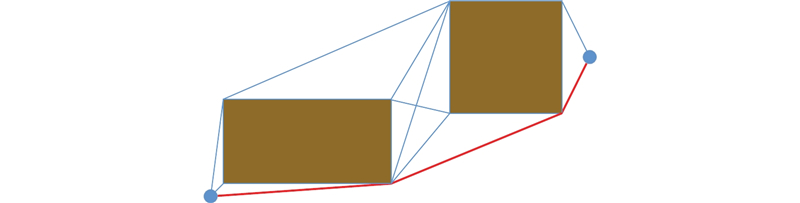
图10
基于数组的个体编码示意图"
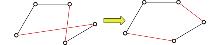
图11
“2-交换”示意图"
图12
确定UAV搜索区域顺序的算法流程图"
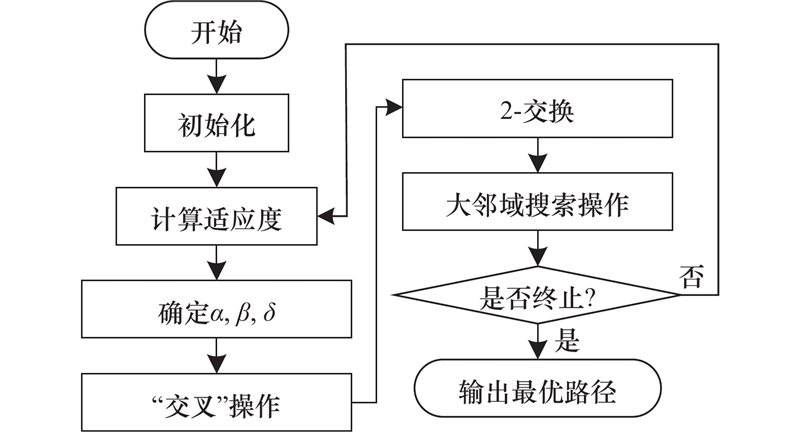
图13
多区域滚动式CPP示意图"
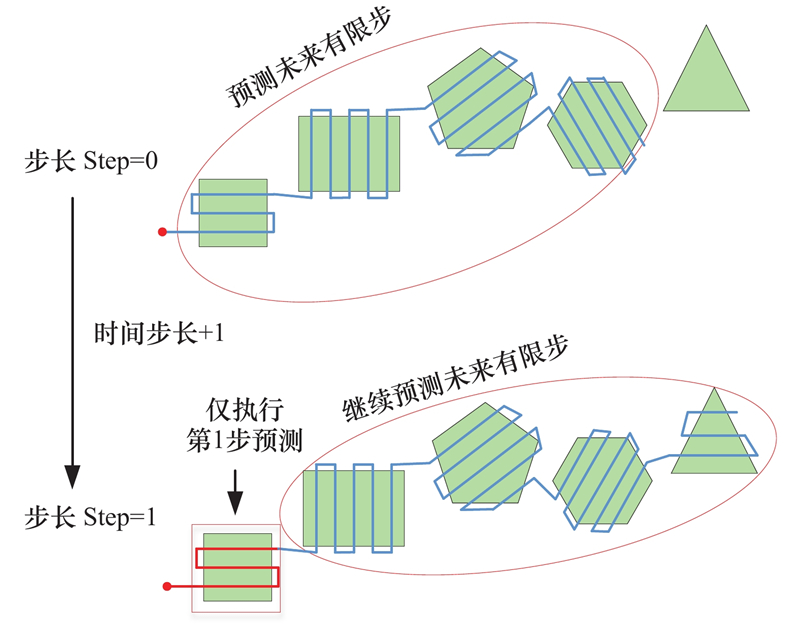
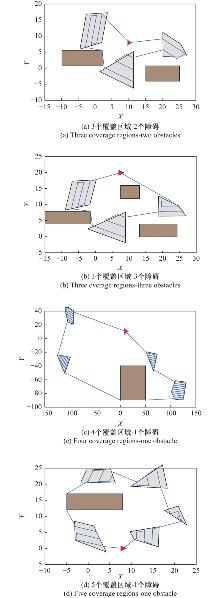
图14
单机多区域CPP图"
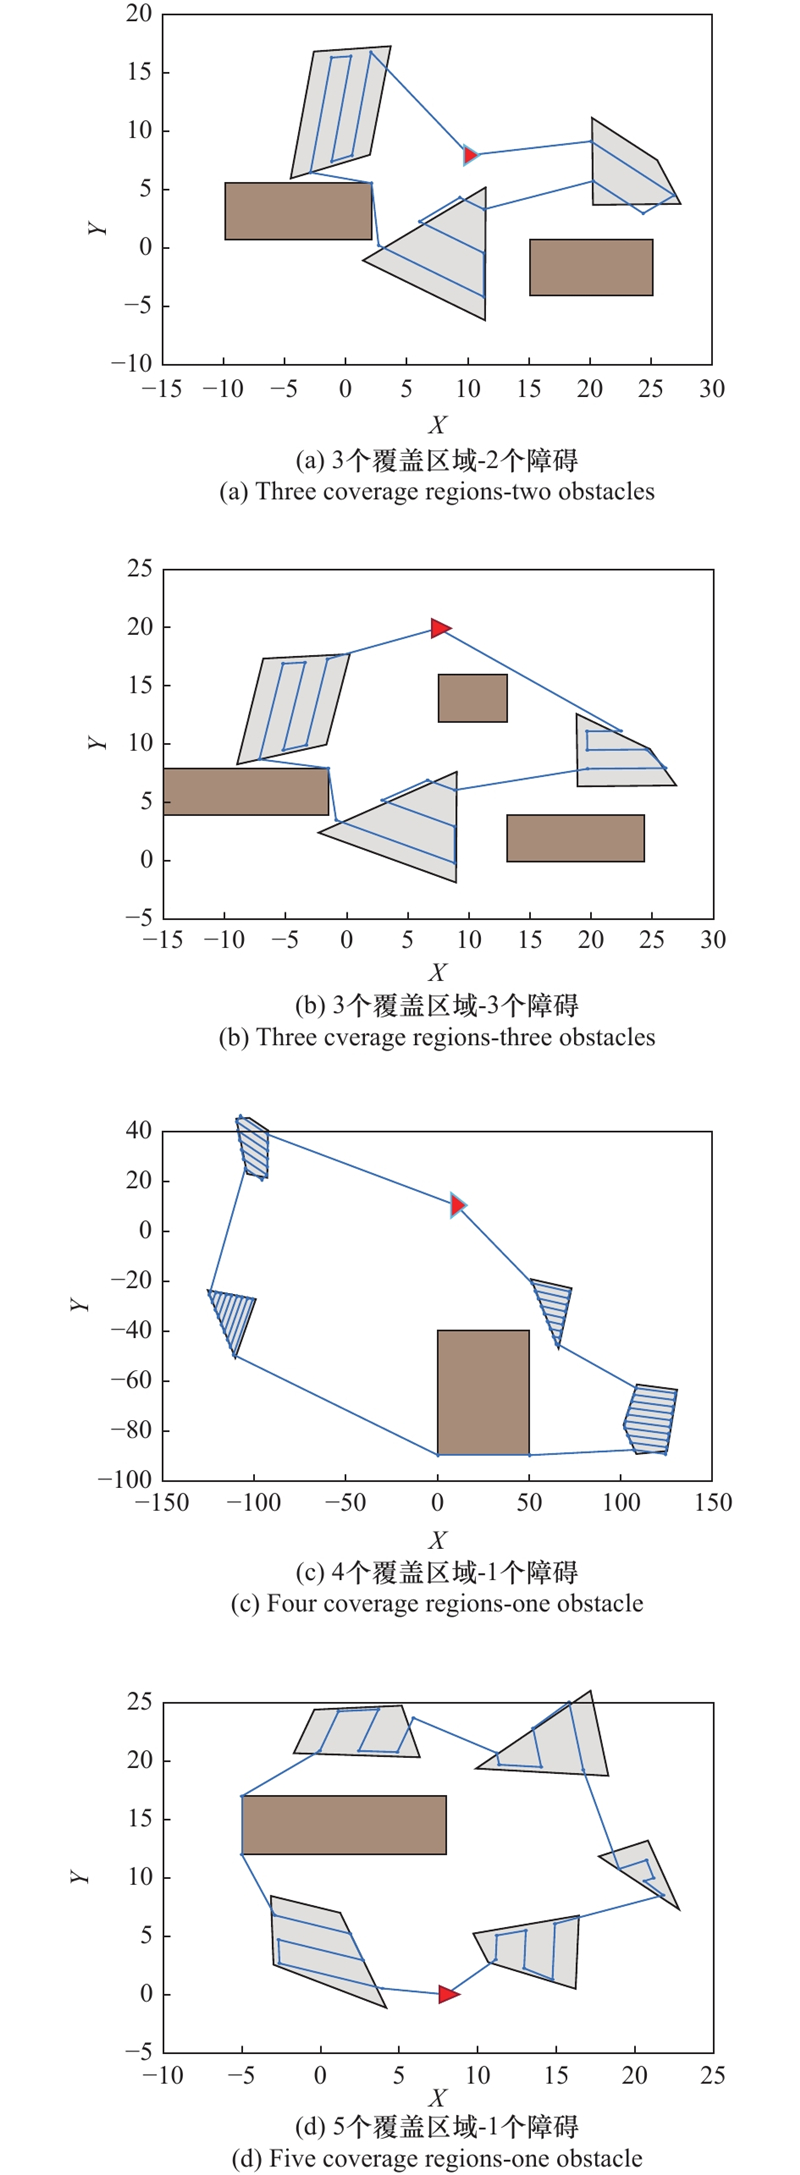
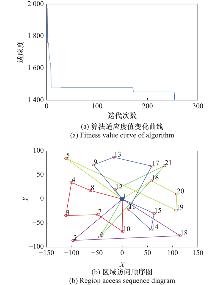
图15
仅“交叉”操作"
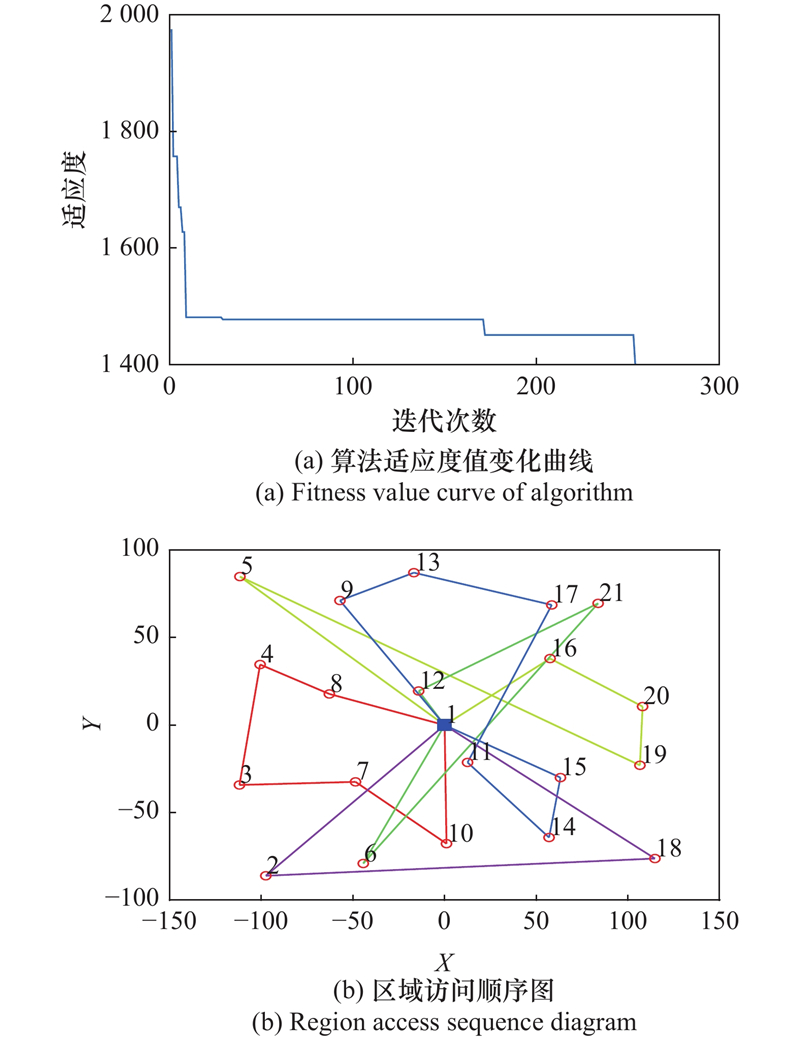
图16
“交叉”操作与“2-交换”操作"
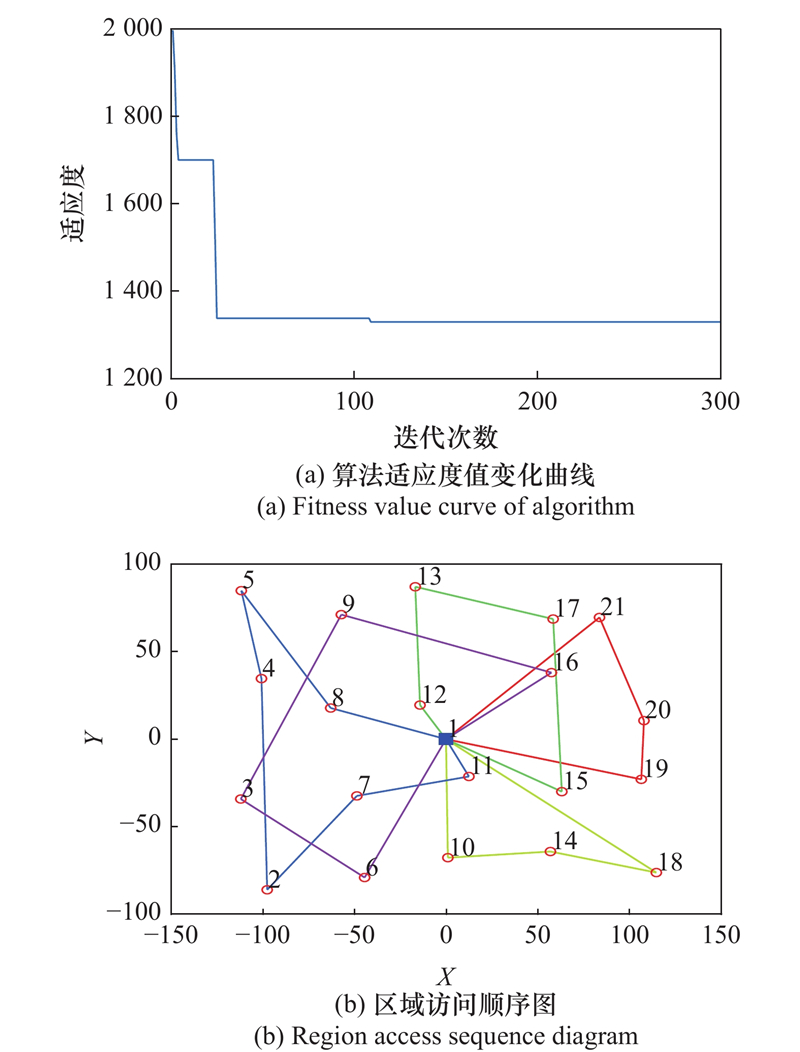
图17
本文算法"
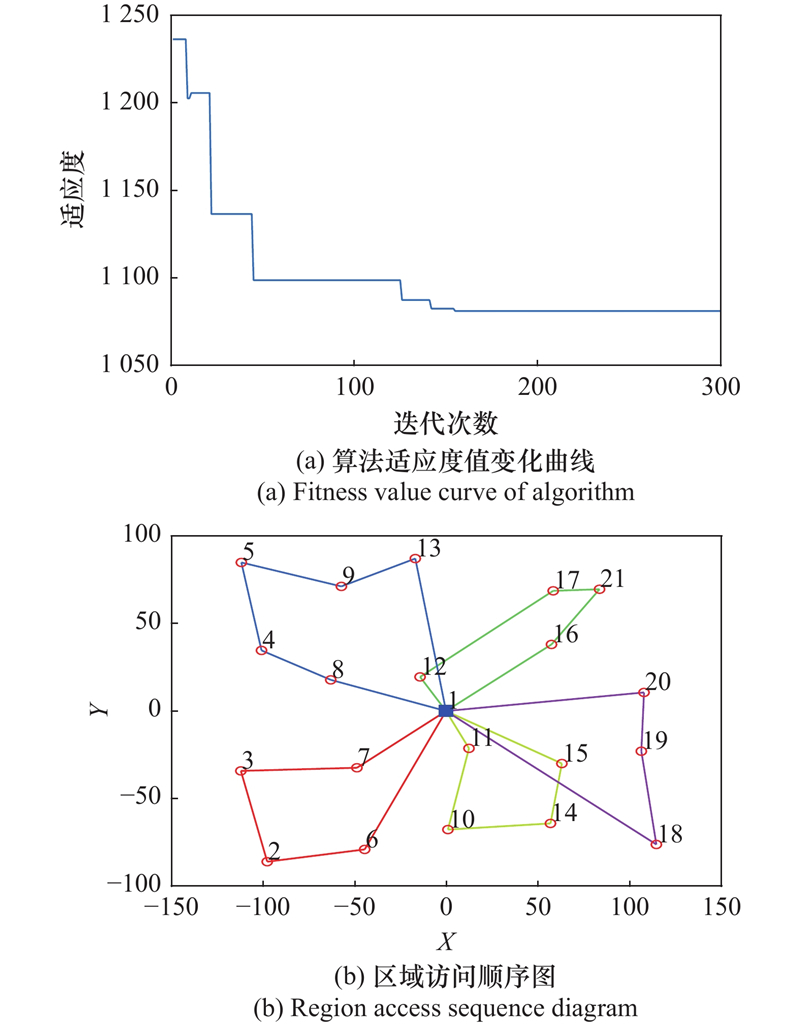
图18
本文算法规划的多机多区域CPP"
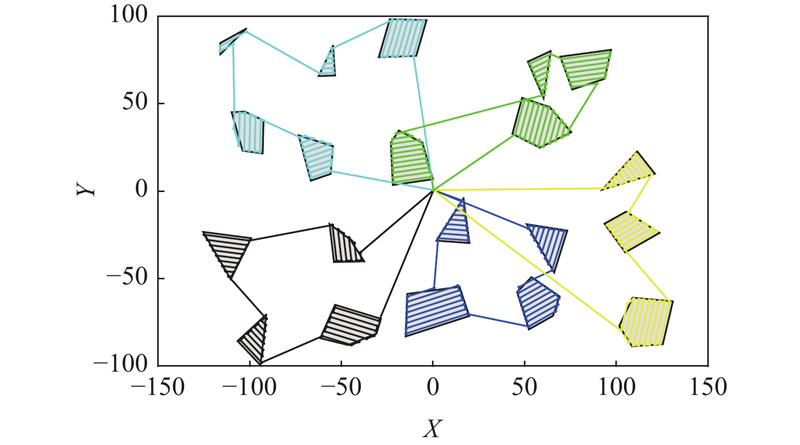
表1
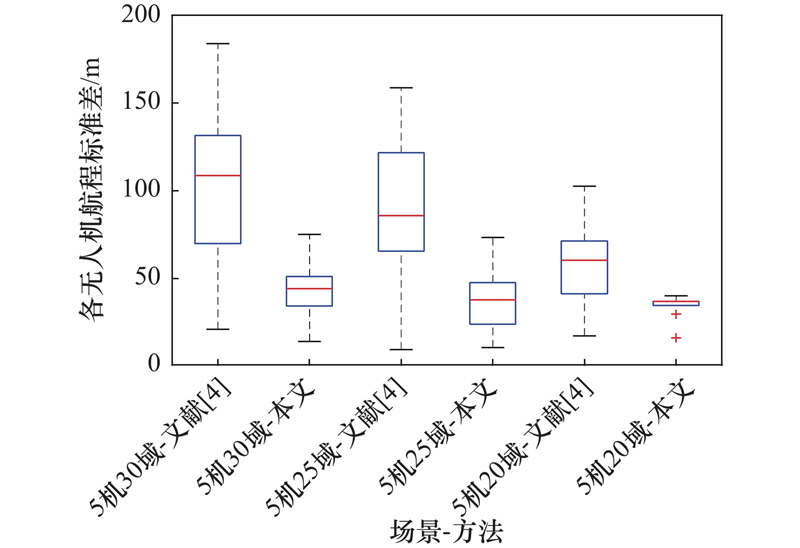
文献[4]方法和本文方法对比评估"
| 区域数 | UAV数 | 所有UAV总飞行距离/m | UAV飞行距离标准差/m | 优化用时/s | |||||
| 文献[ | 本文 | 文献[ | 本文 | 文献[ | 本文 | ||||
| 10 | 2 | 44.9 | 71.3 | 0.35 | 0.70 | ||||
| 10 | 3 | 33.0 | 32.6 | 0.73 | 1.03 | ||||
| 20 | 4 | 45.9 | 34.0 | 2.89 | 2.86 | ||||
| 20 | 5 | 60.0 | 35.7 | 3.28 | 3.15 | ||||
| 20 | 6 | 59.2 | 40.8 | 3.37 | 3.30 | ||||
| 25 | 5 | 88.9 | 37.3 | 4.89 | 4.64 | ||||
| 25 | 6 | 71.0 | 47.0 | 5.06 | 5.00 | ||||
| 30 | 5 | 104.5 | 42.9 | 7.22 | 7.14 | ||||
| 30 | 6 | 108.6 | 46.6 | 9.45 | 7.67 | ||||
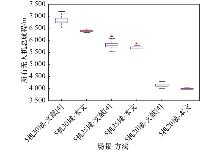
图19
UAV总航程箱线图"
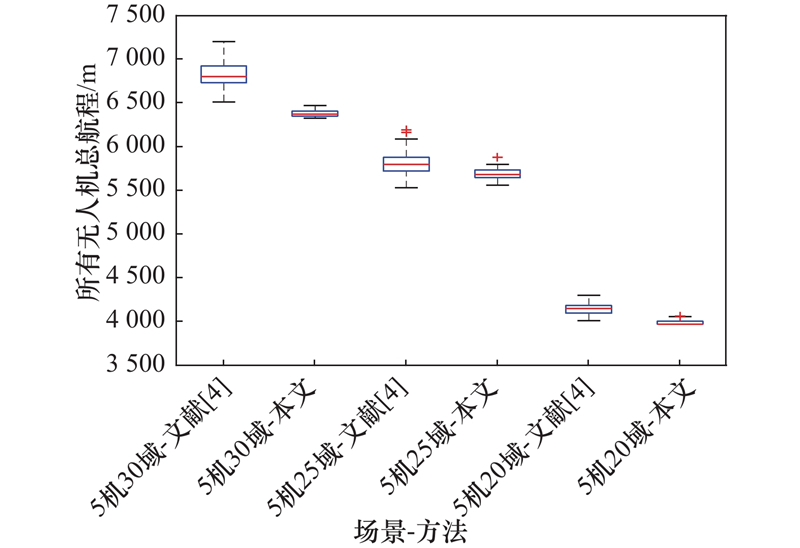
图20
各UAV航程标准差箱线图"
| 1 |
Xue X Y, Tian Y, Yang Z Y, et al. Research on a UAV spray system combined with grid atomized droplets[J]. Frontiers in Plant Science, 2024, 14, 1286332.
doi: 10.3389/fpls.2023.1286332 |
| 2 |
Cruz H, Eckert M, Meneses J, et al. Efficient forest fire detection index for application in unmanned aerial systems (UASs)[J]. Sensors, 2016, 16 (6): 893.
doi: 10.3390/s16060893 |
| 3 |
Pan M X, Chen C C, Yin X J, et al. UAV-aided emergency environmental monitoring in infrastructure-less areas: Lora mesh networking approach[J]. IEEE Internet of Things Journal, 2022, 9 (4): 2918.
doi: 10.1109/JIOT.2021.3095494 |
| 4 |
Xie J F, Chen J. Multiregional coverage path planning for multiple energy constrained UAVs[J]. IEEE Trans. on Intelligent Transportation Systems, 2022, 23 (10): 17366.
doi: 10.1109/TITS.2022.3160402 |
| 5 | Yang H T, Lu X Q, Zhou X A, et al. Expected length of the shortest path of the traveling salesman problem in 3D space[J]. Journal of Advanced Transportation, 2022, 2022 (1): 124950. |
| 6 | Dijkstra E W. A note on two problems in connexion with graphs[M]//Krzysztof R, Hoare T, ed. Edsger Wybe Dijkstra: His Life,Work, and Legacy. New York: Association for Computing Machinery, 2022: 287. |
| 7 |
Zhang J, Bai J P. Dijkstra algorithm based cooperative caching strategy for UAV-assisted edge computing system[J]. Wireless Networks, 2024, 30 (3): 1201.
doi: 10.1007/s11276-023-03551-x |
| 8 |
Sadaf J, Ali H, Rizwan A, et al. State-of-the-art and future research challenges in UAV swarms[J]. IEEE Internet of Things Journal, 2024, 11 (11): 19023.
doi: 10.1109/JIOT.2024.3364230 |
| 9 |
Xiao H, Sun C M, Wang W S. UAV route planning and light searching method based on optical sensing[J]. IEEE Internet of Things Journal, 2025, 12 (12): 21931.
doi: 10.1109/JIOT.2025.3550126 |
| 10 |
Zhang H H, Gan X S, Li S F, et al. UAV safe route planning based on PSO-BAS algorithm[J]. Journal of Systems Engineering and Electronics, 2022, 33 (5): 1151.
doi: 10.23919/JSEE.2022.000111 |
| 11 |
Liu Z Y, Li L H, Zhang X, et al. Considering both energy effectiveness and flight safety in UAV trajectory planning for intelligent logistics[J]. Vehicular Communications, 2025, 52, 100885.
doi: 10.1016/j.vehcom.2025.100885 |
| 12 | Abid M, El K S, Amzil A, et al. Optimization of UAV flight paths in multi-UAV networks for efficient data collection[J]. Arabian Journal for Science and Engineering, 2024, 50 (10): 7207. |
| 13 |
Gustavo S C A, Guilherme P, Pimenta A S, et al. Multi-UAV routing for area coverage and remote sensing with minimum time[J]. Sensors, 2015, 15(11), 27783.
doi: 10.3390/s151127783 |
| 14 |
Luciano B, Egidio D A, Massimiliano M, et al. Path planning and real-time collision avoidance based on the essential visibility graph[J]. Applied Sciences, 2020, 10 (16): 5613.
doi: 10.3390/app10165613 |
| 15 |
Ilyas H, Issmail E H, Francois S. A multiphase dynamic programming algorithm for the shortest path problem with resource constraints[J]. European Journal of Operational Research, 2024, 315 (2): 470.
doi: 10.1016/j.ejor.2023.11.047 |
| 16 |
Hart P, Nilsson N, Raphael B. A formal basis for the heuristic determination of minimum cost paths[J]. IEEE Trans. on Systems Science and Cybernetics, 1968, 4 (2): 100.
doi: 10.1109/TSSC.1968.300136 |
| 17 | Khatib O. Real time obstacle avoidance for manipulators and mobile robots[C]//IEEE International Conference on Robotics and Automation, 1985: 500. |
| 18 |
Lin H I, Muhammad A F S, Ming F H. Robot path planning based on three-dimensional artificial potential field[J]. Engineering Applications of Artificial Intelligence, 2025, 144, 110127.
doi: 10.1016/j.engappai.2025.110127 |
| 19 | Wang Y Q, Zhu J, Huang H P, et al. Bi-objective ant colony optimization for trajectory planning and task offloading in UAV-assisted MEC systems [J]. IEEE Trans. on Mobile Computing, 2024, 23(12): 12360. |
| 20 |
Zhi L W, Zuo Y. Collaborative path planning of multiple AUVs based on adaptive multi-population PSO[J]. Journal of Marine Science and Engineering, 2024, 12 (2): 223.
doi: 10.3390/jmse12020223 |
| 21 |
Debnath D, Vanegas F, Boiteau S, et al. An integrated geometric obstacle avoidance and genetic algorithm TSP model for UAV path planning[J]. Drones, 2024, 8, 302.
doi: 10.3390/drones8070302 |
| 22 |
Zang Y C, Huang X Q, Lu M, et al. E2VRP-CPP: an energy-efficient approach for multi-UAV multi-region coverage path planning optimization in the enhanced vehicle routing problem[J]. Drones, 2025, 9 (3): 200.
doi: 10.3390/drones9030200 |
| 23 |
Xie J F, Carrillo L R G, Jin L. Path planning for UAV to cover multiple separated convex polygonal regions[J]. IEEE Access, 2020, 8, 51770.
doi: 10.1109/ACCESS.2020.2980203 |
| 24 |
Little J D C, Murty K G, Sweeney D W, et al. An algorithm for the traveling salesman problem[J]. Operations Research, 1963, 11 (6): 972.
doi: 10.1287/opre.11.6.972 |
| 25 | Luna M A, Isaac M S A, Cortizas M F, et al. Spiral coverage path planning for multi-UAV photovoltaic panel inspection applications[C]//International Conference on Unmanned Aircraft Systems, 2023. |
| 26 |
Luna M A, Molina M, Gomez R D S, et al. A multi-UAV system for coverage path planning applications with in-flight re-planning capabilities[J]. Journal of Field Robotics, 2024, 41 (5): 1480.
doi: 10.1002/rob.22342 |
| 27 |
Wang L, Zhuang X D, Zhang W T, et al. Coverage path planning for UAVs: an energy-efficient method in convex and non-convex mixed regions[J]. Drones, 2024, 8 (12): 776.
doi: 10.3390/drones8120776 |
| 28 |
Datsko D, Nekovar F, Penicka R, et al. Energy-aware multi-UAV coverage mission planning with optimal speed of flight[J]. IEEE Robotics and Automation Letters, 2024, 9 (3): 2893.
doi: 10.1109/LRA.2024.3358581 |
| 29 | 闫川, 甄子洋, 张继豪, 等. 突防飞行与多区域搜索一体化侦察航迹规划[J]. 飞行力学, 2023, 41 (1): 20. |
| 30 | 田双喜, 陈洪辉, 徐彬杰, 等. 车辆支持的多无人机多区域覆盖路径规划算法[J]. 国防科技大学学报, 2024, 46 (6): 227. |
| 31 | 夏阳升, 石建迈, 陈超, 等. 车机协同多区域覆盖侦察路径规划方法[J]. 指挥与控制学报, 2020, 6 (4): 372. |
| 32 | 刘瑶, 夏阳升, 石建迈, 等. 车载多无人机协同多区域覆盖路径规划方法[J]. 系统工程与电子技术, 2023, 45 (5): 1380. |
| 33 | 杨鹏程, 杨清清, 高盈盈, 等. 基于强化学习的海上移动目标搜索路径规划 [EB/OL]. [2025-06-01]. https: //link. cnki. net/urlid/11.2422. tn. 20240614.1103. 005. |
| 34 | Zhao C Y, Liu J, Yoon S, et al. Energy constrained multi-agent reinforcement learning for coverage path planning[C]//IEEE/RSJ International Conference on Intelligent Robots and Systems, 2023. |
| 35 |
Lasse D N, Inkyung S, Peter N. Convex decomposition for a coverage path planning for autonomous vehicles: interior extension of edges[J]. Sensors, 2019, 19 (19): 4165.
doi: 10.3390/s19194165 |
| 36 | Vink K, Solomon G, Ali K. An area-decomposition based approach for cooperative tasking and coordination of UAVs in a search and coverage mission[C]//IEEE Aerospace Conference, 2019. |
| 37 | 陈海, 王新民, 焦裕松, 等. 一种凸多边形区域的无人机覆盖航迹规划算法[J]. 航空学报, 2010, 31 (9): 1802. |
| 38 |
Lozano P, Wesley M A. An algorithm for planning collision-free paths among polyhedral obstacles[J]. Communications of the ACM, 1979, 22 (10): 560.
doi: 10.1145/359156.359164 |
| 39 |
Hu X B, Yang C S, Zhou J, et al. Research on 3D layered visibility graph route network model and multi-objective path planning for UAVs in complex urban environments[J]. Aerospace Science and Technology, 2025, 159, 109947.
doi: 10.1016/j.ast.2025.109947 |
| 40 |
Singh A, Baghel A S. A new grouping genetic algorithm approach to the multiple traveling salespers on problem[J]. Soft Computing, 2009, 13 (1): 95.
doi: 10.1007/s00500-008-0312-1 |
| 41 | Johnson D S, Mcgeoch L A. The traveling salesman problem: a case study in local optimization[J]. Local Search in Combinatorial Optimization, 1997, 1(1): 215. |
| 42 | 夏小云, 庄鹤林, 杨火根, 等. 自适应大邻域搜索的人工蜂群算法求解带容量约束车辆路径问题[J]. 计算机集成制造系统, 2022, 28 (11): 3545. |
| [1] | 汤罗浩, 雷洪涛, 石建迈, 刁博阳, 朱承. 多平台协同鲁棒团队形成问题与算法[J]. 系统工程与电子技术, 2026, 48(8): 2659-2668. |
| [2] | 周晨宇, 张超, 李聪. 基于空闲资源碎片整合的测控数传一体化资源调度算法[J]. 系统工程与电子技术, 2026, 48(6): 1946-1964. |
| [3] | 羊钊, 胡锦标, 王艳, 齐洪彪. 考虑异巢起降的无人机山地巡检覆盖路径规划[J]. 系统工程与电子技术, 2025, 47(8): 2622-2631. |
| [4] | 陈威, 王从庆, 曾强, 李战. 面向飞机表面视觉检查的无人机覆盖路径规划[J]. 系统工程与电子技术, 2025, 47(4): 1206-1213. |
| [5] | 于海宝, 许卫东, 谢雨谋, 魏洪, 叶雨佳, 郑龙华. 基于动态规划的阵地伪装方案优化方法[J]. 系统工程与电子技术, 2025, 47(11): 3721-3728. |
| [6] | 师明, 高宇辉, 张弓. 基于HTN的巡视器动态规划方法[J]. 系统工程与电子技术, 2024, 46(2): 631-639. |
| [7] | 刘瑶, 夏阳升, 石建迈, 陈超, 黄金才. 车载多无人机协同多区域覆盖路径规划方法[J]. 系统工程与电子技术, 2023, 45(5): 1380-1390. |
| [8] | 吴靖宇, 朱世强, 宋伟, 施浩磊, 吴泽南. 基于改进单元分解法的全覆盖路径规划[J]. 系统工程与电子技术, 2023, 45(12): 3949-3957. |
| [9] | 张佳唯, 钱凤臣, 杨俊强, 赵骞, 张峥嵘. 弹性光网络中路由与频谱分配算法综述[J]. 系统工程与电子技术, 2022, 44(6): 2001-2010. |
| [10] | 赵长啸, 李二帅, 何锋, 王鹏. TSN时间敏感流量带宽分配与优化[J]. 系统工程与电子技术, 2022, 44(6): 2027-2034. |
| [11] | 辛立强, 张超, 赵灵芝, 刘建平. 面向复杂关联测控需求的冲突规避调度算法[J]. 系统工程与电子技术, 2022, 44(5): 1581-1588. |
| [12] | 杨清清, 高盈盈, 郭玙, 夏博远, 杨克巍. 基于深度强化学习的海战场目标搜寻路径规划[J]. 系统工程与电子技术, 2022, 44(11): 3486-3495. |
| [13] | 郭建国, 苏亚鲁. 高超飞行器自适应动态规划的控制系统设计[J]. 系统工程与电子技术, 2021, 43(6): 1628-1635. |
| [14] | 周鑫, 王维平, 朱一凡, 王涛, 井田. 基于顺次分配机制的无人装备体系架构方案空间搜索方法[J]. 系统工程与电子技术, 2021, 43(11): 3211-3219. |
| [15] | 吴文海, 郭晓峰, 周思羽. 基于NURBS和GOBL-ACDE的航迹规划算法[J]. 系统工程与电子技术, 2020, 42(5): 1073-1082. |
| 阅读次数 | ||||||
|
全文 |
|
|||||
|
摘要 |
|
|||||
