系统工程与电子技术 ›› 2026, Vol. 48 ›› Issue (10): 3596-3610.doi: 10.12305/j.issn.1001-506X.2026.10.30
• 制导、导航与控制 • 上一篇
孙世昌( ), 于国川, 南英, 张绍良
收稿日期:2025-08-12
出版日期:2026-10-25
发布日期:2026-09-30
通讯作者:
南英
E-mail:Lionssc@nuaa.edu.cn
作者简介:孙世昌(1999—),男,硕士研究生,主要研究方向为飞行器轨迹规划与制导控制
Shichang Sun(), Guochuan Yu, Ying Nan, Shaoliang Zhang
Received:2025-08-12
Online:2026-10-25
Published:2026-09-30
Contact:
Ying Nan
E-mail:Lionssc@nuaa.edu.cn
摘要:
为实现高超声速飞行器滑翔段时间协同再入,提出一种结合双参数插值侧倾角剖面和神经网络预测器的时间协同再入制导方法。首先,将高度-速度平面内的过程约束和终端约束转换为侧倾角走廊,并在其中构建基于双参数插值的侧倾角剖面以进行约束管理。其次,采用双层前馈神经网络实现航程与飞行时长的高精度实时预测,并通过求解双变量求根问题对剖面参数进行校正更新。在此基础上,结合航向角走廊横向制导与协同飞行时间确定方法,构建时间协同再入制导框架,实现制导指令的在线快速生成。最后,数值仿真结果表明,该算法能满足时间协同再入的各项约束,且制导精度高、适应性强;相比数值积分方法,神经网络仅需约10%的计算时间即可达到相近的预测精度;蒙特卡罗仿真表明,算法在初始状态与气动参数存在不确定性时,仍具备良好的鲁棒性。
中图分类号:
孙世昌, 于国川, 南英, 张绍良. 基于神经网络的高超声速飞行器时间协同再入制导[J]. 系统工程与电子技术, 2026, 48(10): 3596-3610.
Shichang Sun, Guochuan Yu, Ying Nan, Shaoliang Zhang. Time-coordination reentry guidance for hypersonic vehicle using neural network[J]. Systems Engineering and Electronics, 2026, 48(10): 3596-3610.
图1
时间协同再入制导框架图"
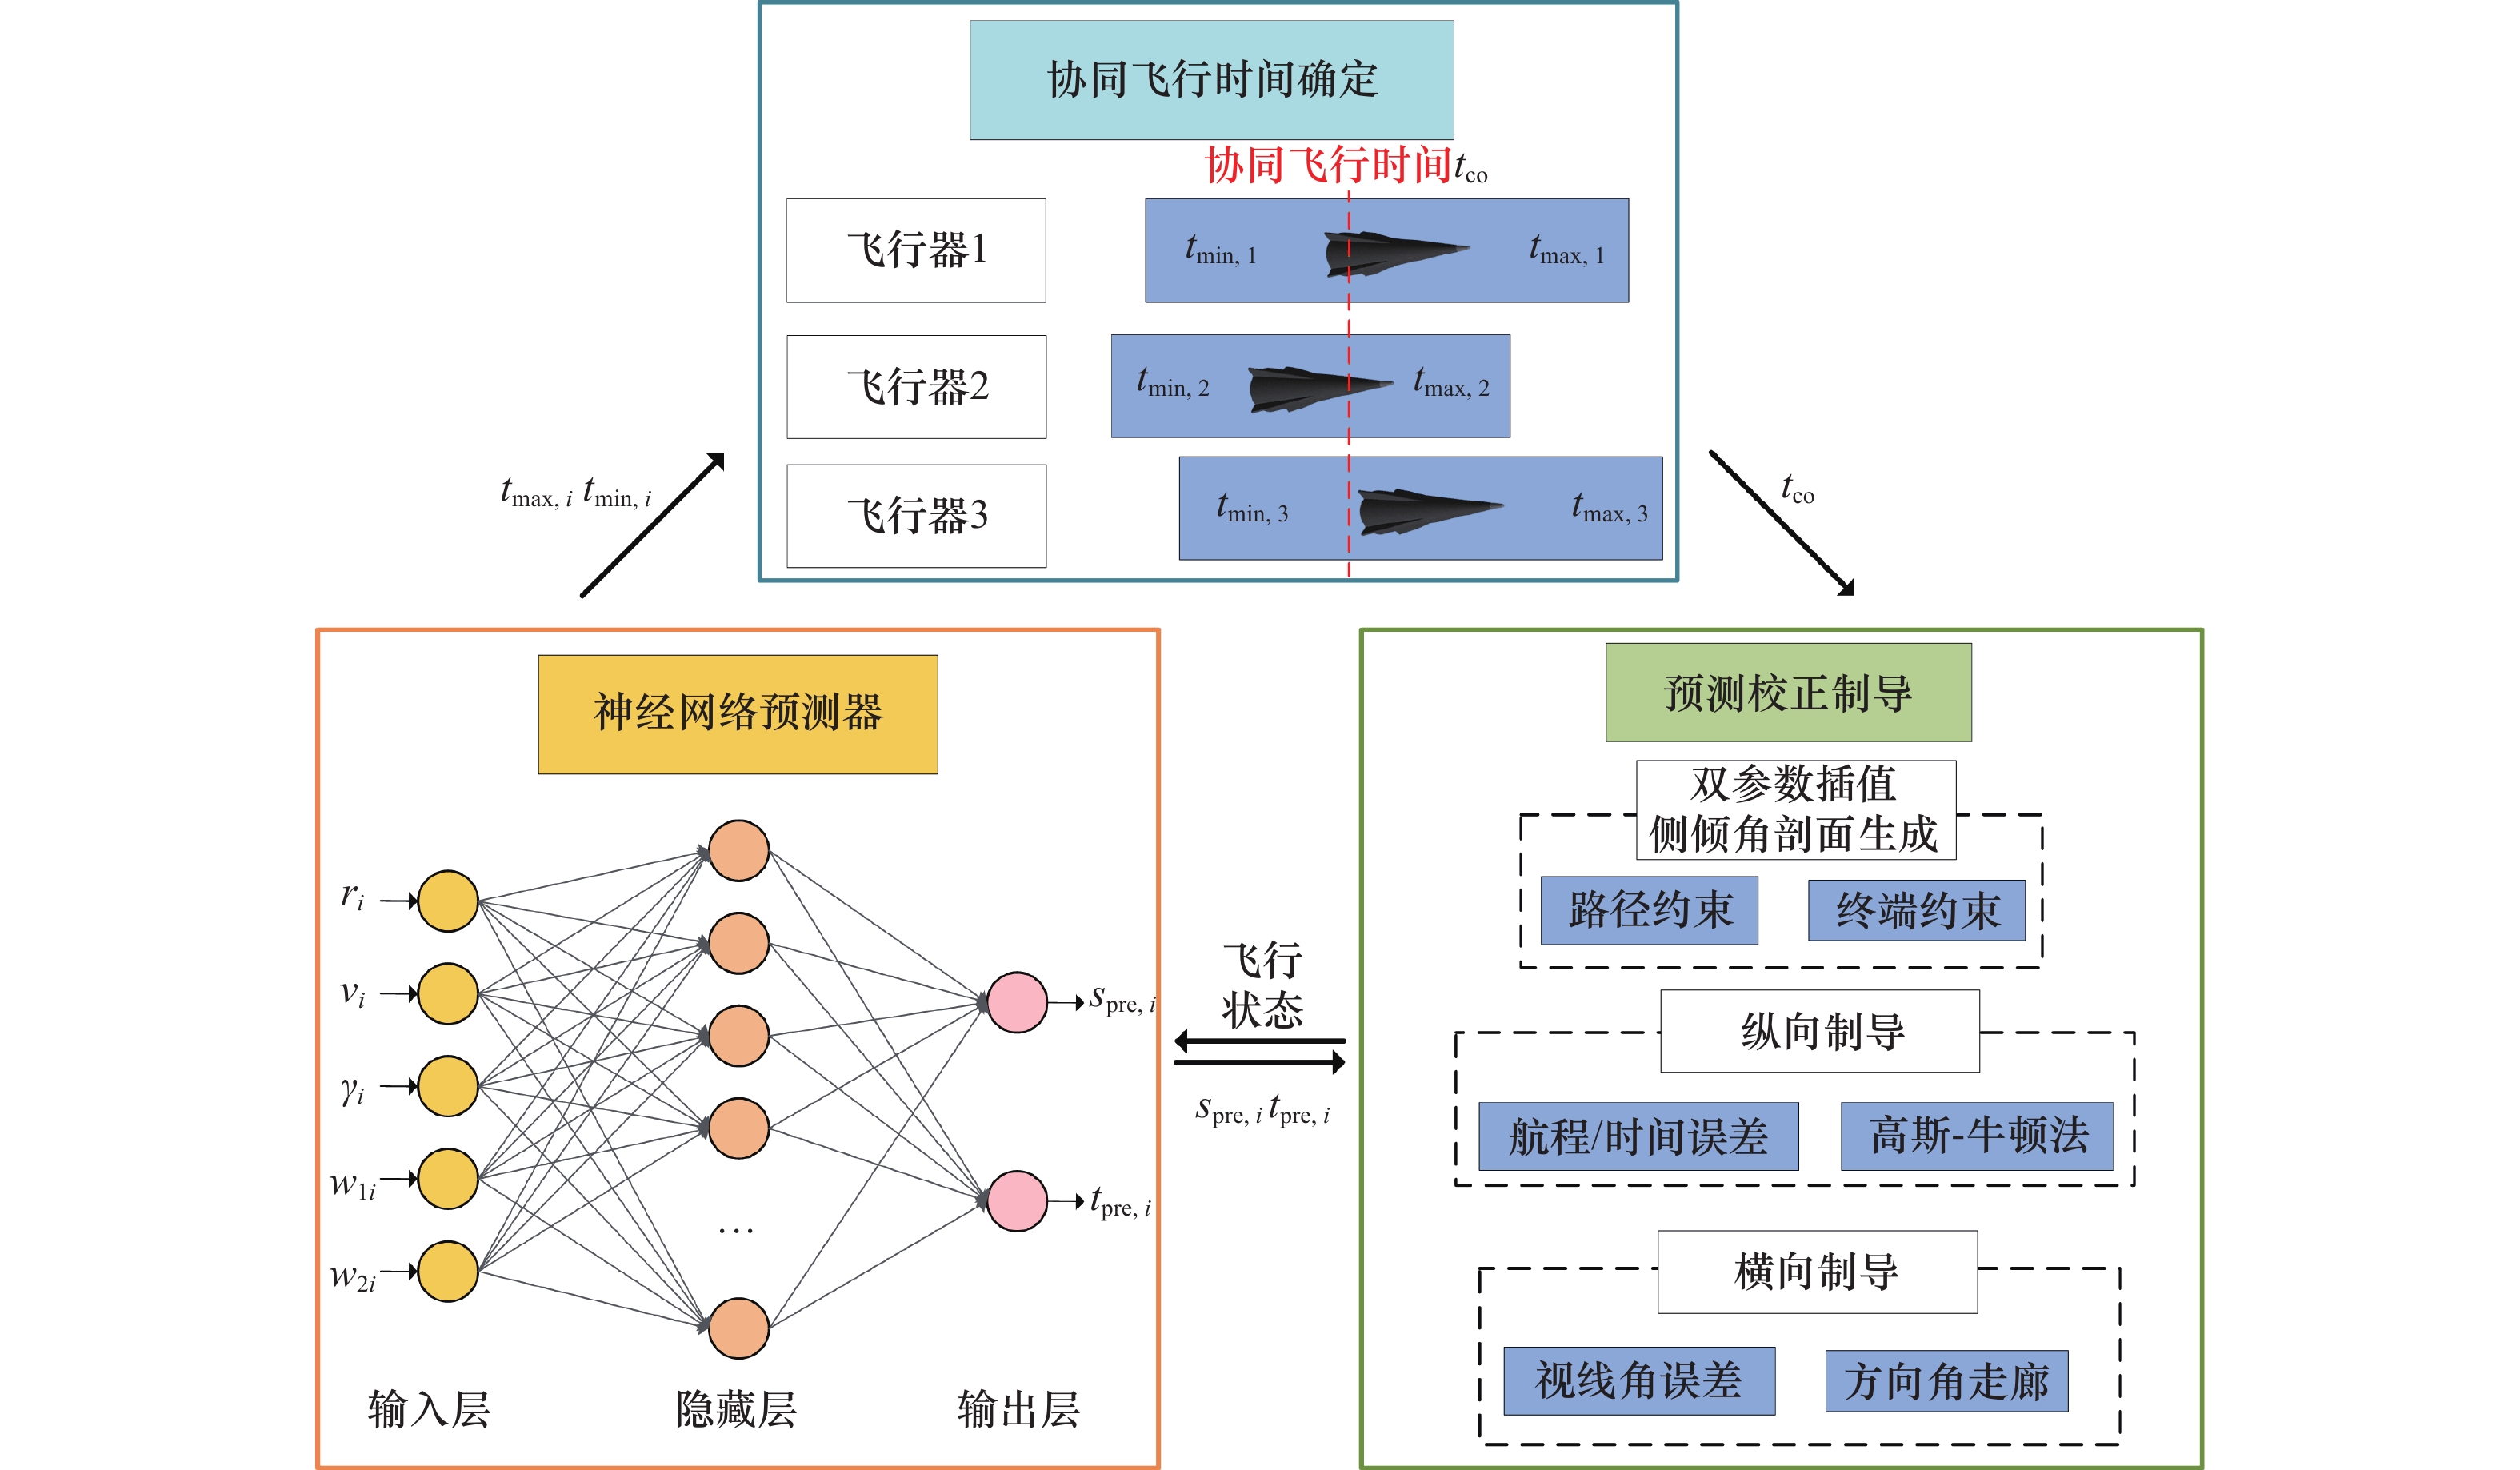
图2
侧倾角剖面示意图"
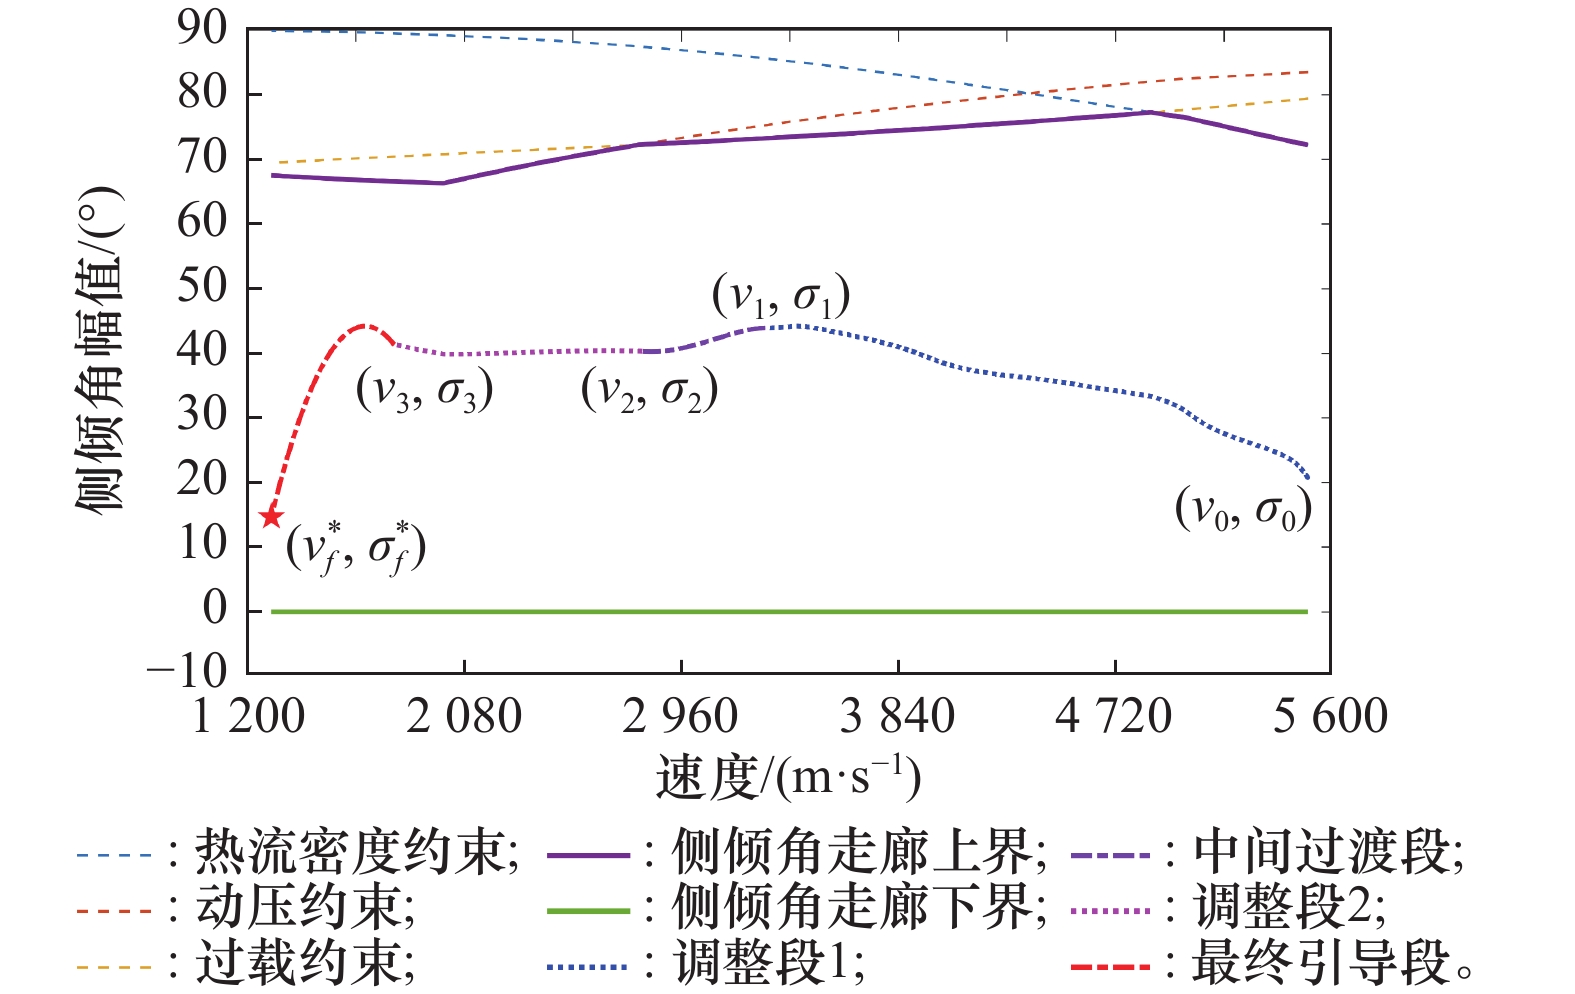
图3
总航程与权重系数的关系"
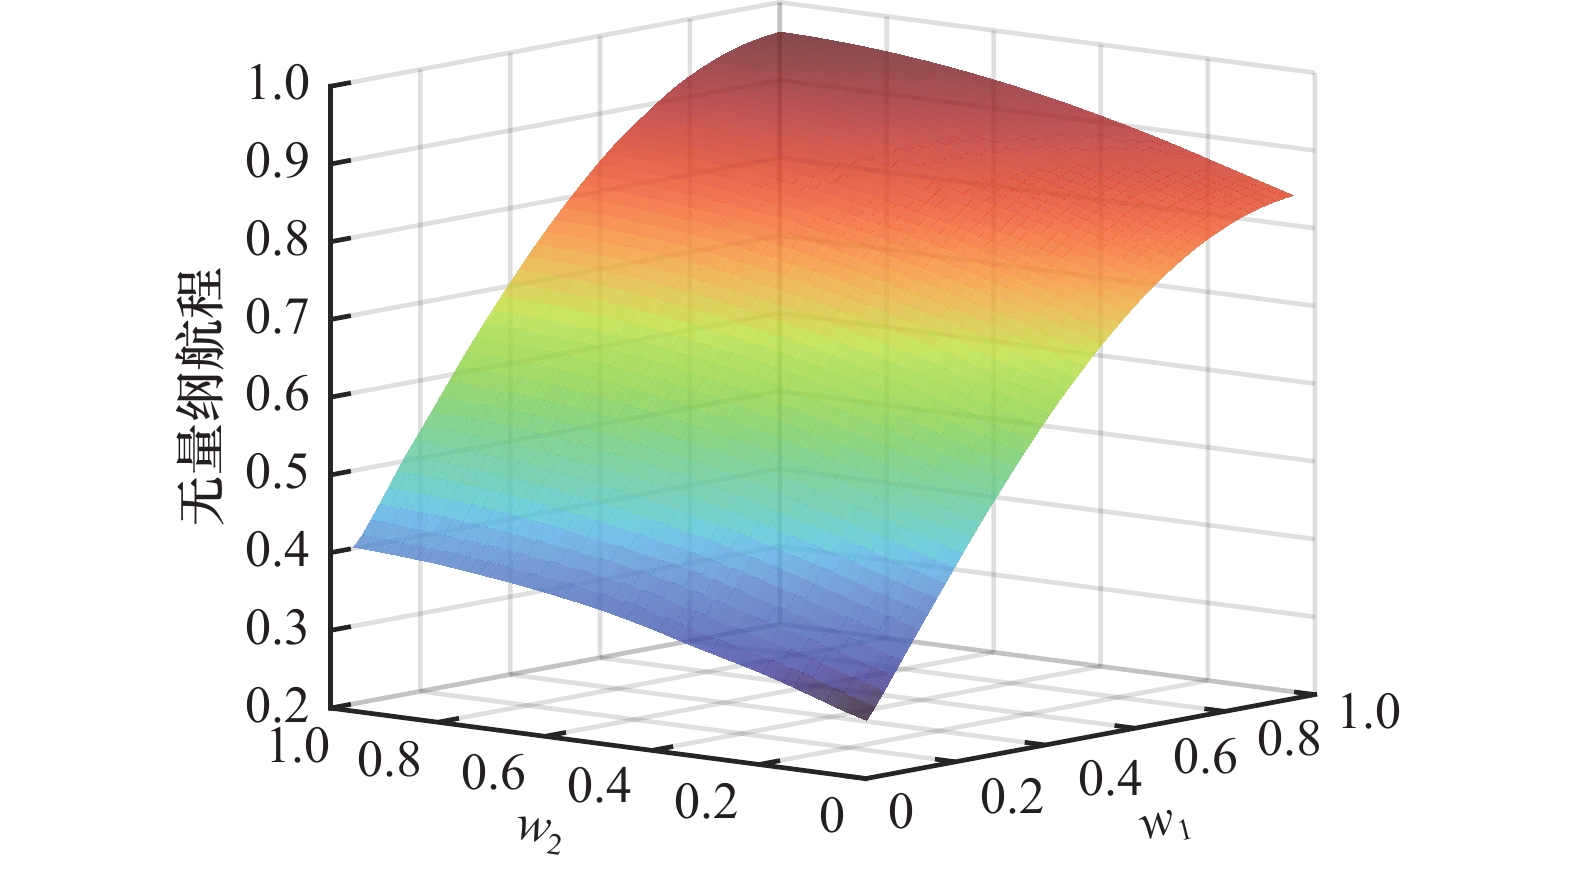
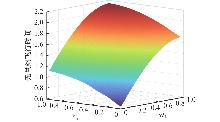
图4
总飞行时间与权重系数的关系"
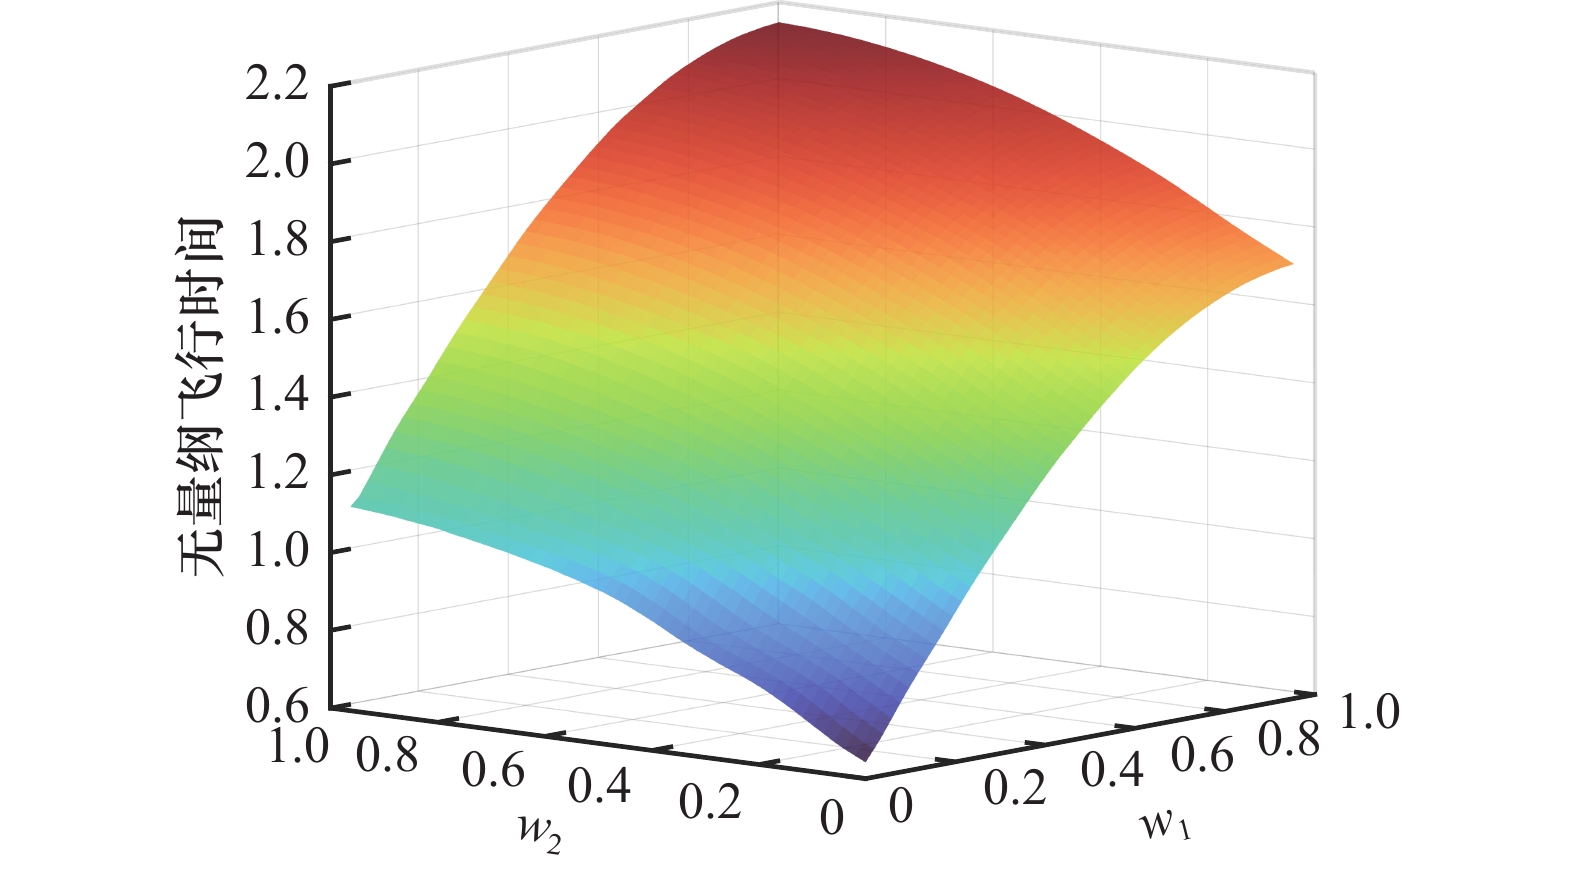
表1
初始状态空间"
| 状态 | 偏差范围 | 分布 |
| 60 | 均匀分布 | |
| 均匀分布 | ||
| 0 | 均匀分布 | |
| 均匀分布 | ||
| 均匀分布 | ||
| 均匀分布 | ||
| 均匀分布 | ||
| 均匀分布 |
表2
网络结构"
| 设置 | 参数 |
| 网络输入 | |
| 网络输出 | |
| 节点数 | 32 |
| 激活函数 | 隐藏层:Sigmoid;输出层:Purelin |
| 训练算法 | Adam |
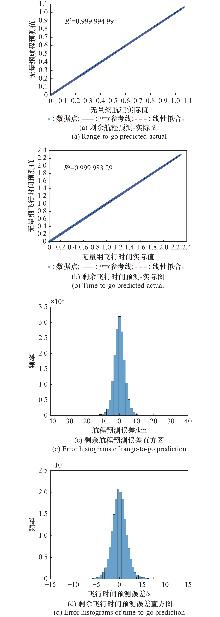
图5
神经网络训练结果"
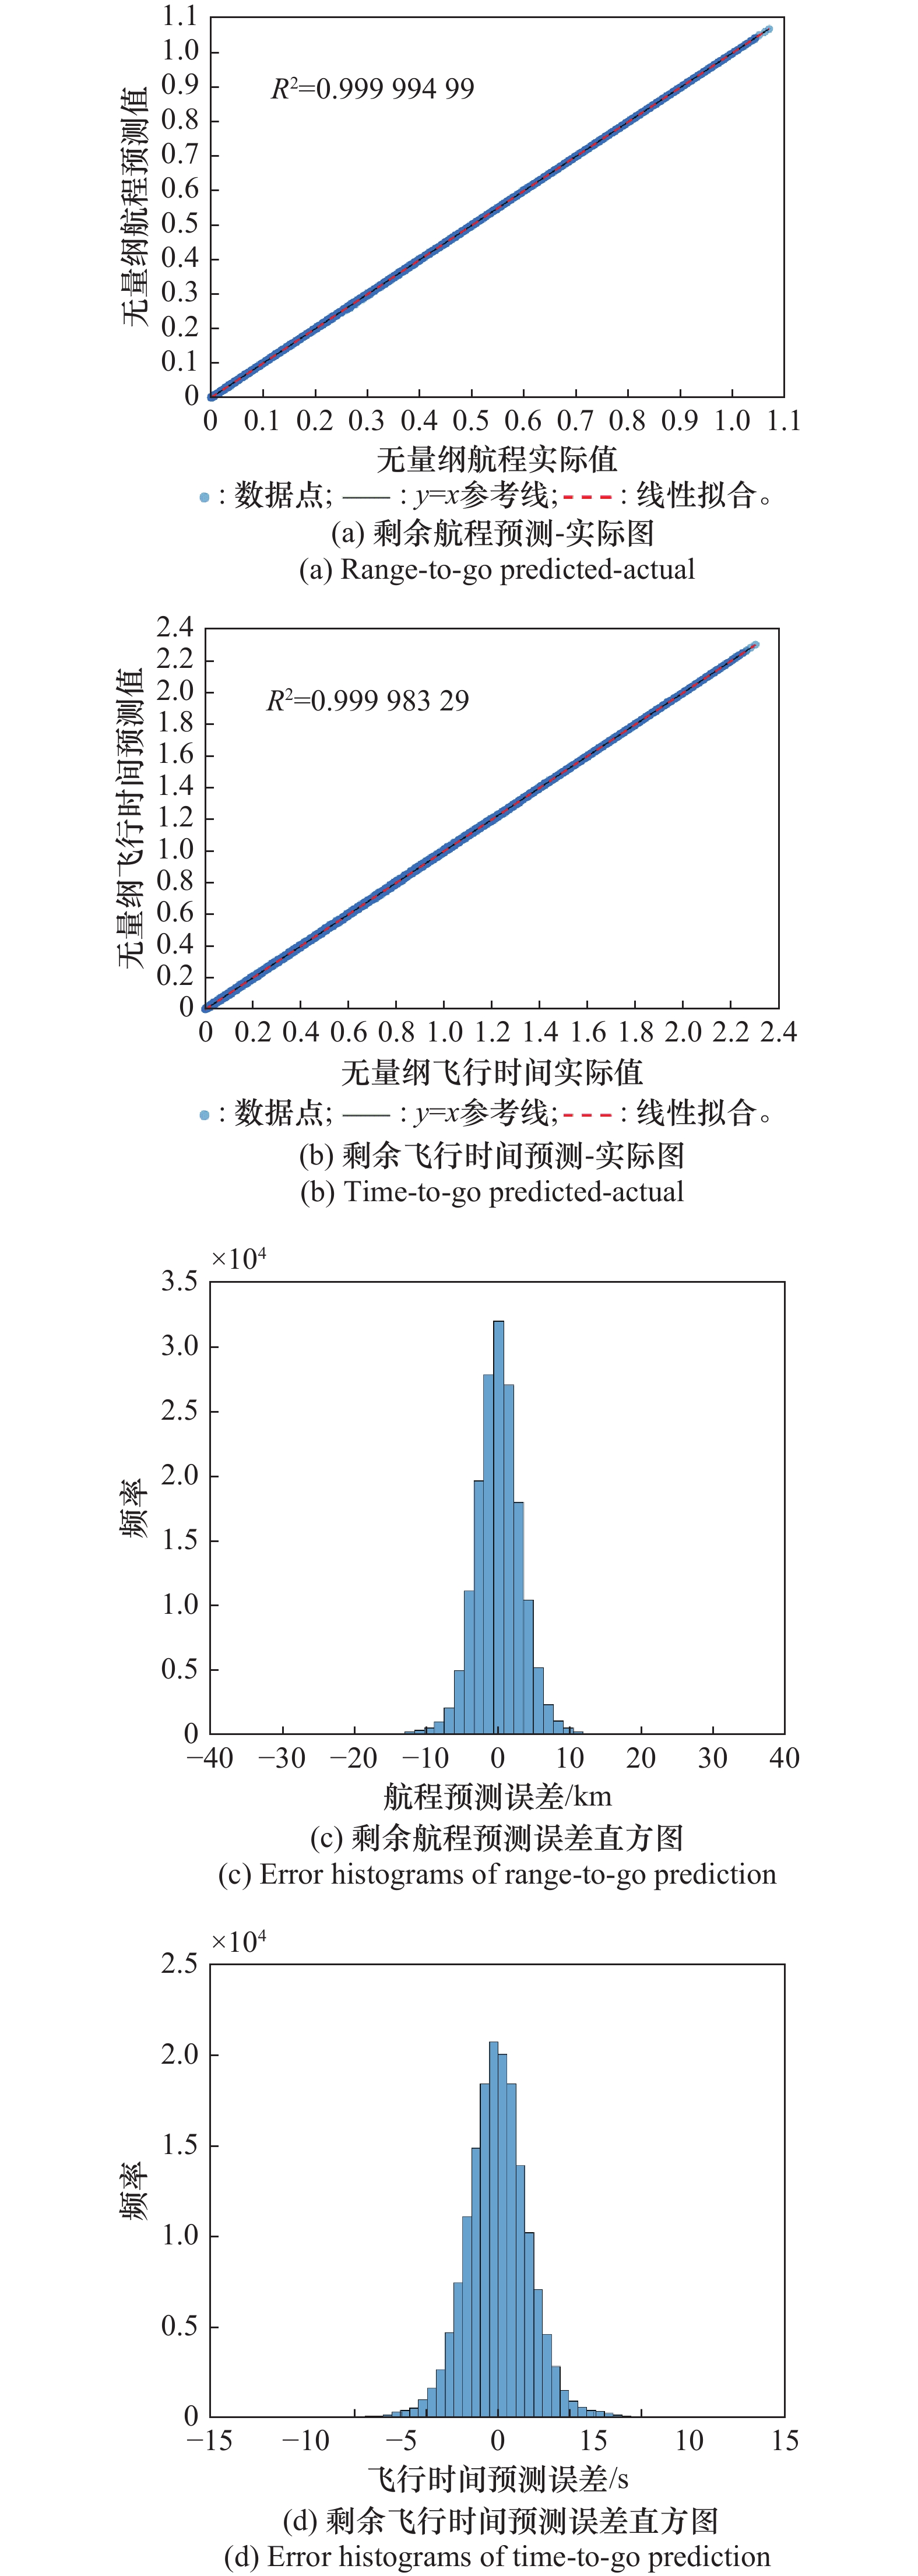
表3
神经网络训练结果"
| 参数 | ||
| MSE | 2.7795E−7 | 4.4565E−6 |
| RMSE | 5.2721E−4 | |
| MAE | 3.9130E−4 | |
| R2 |
图6
不同飞行状态下剩余航程与剩余飞行时间比较"
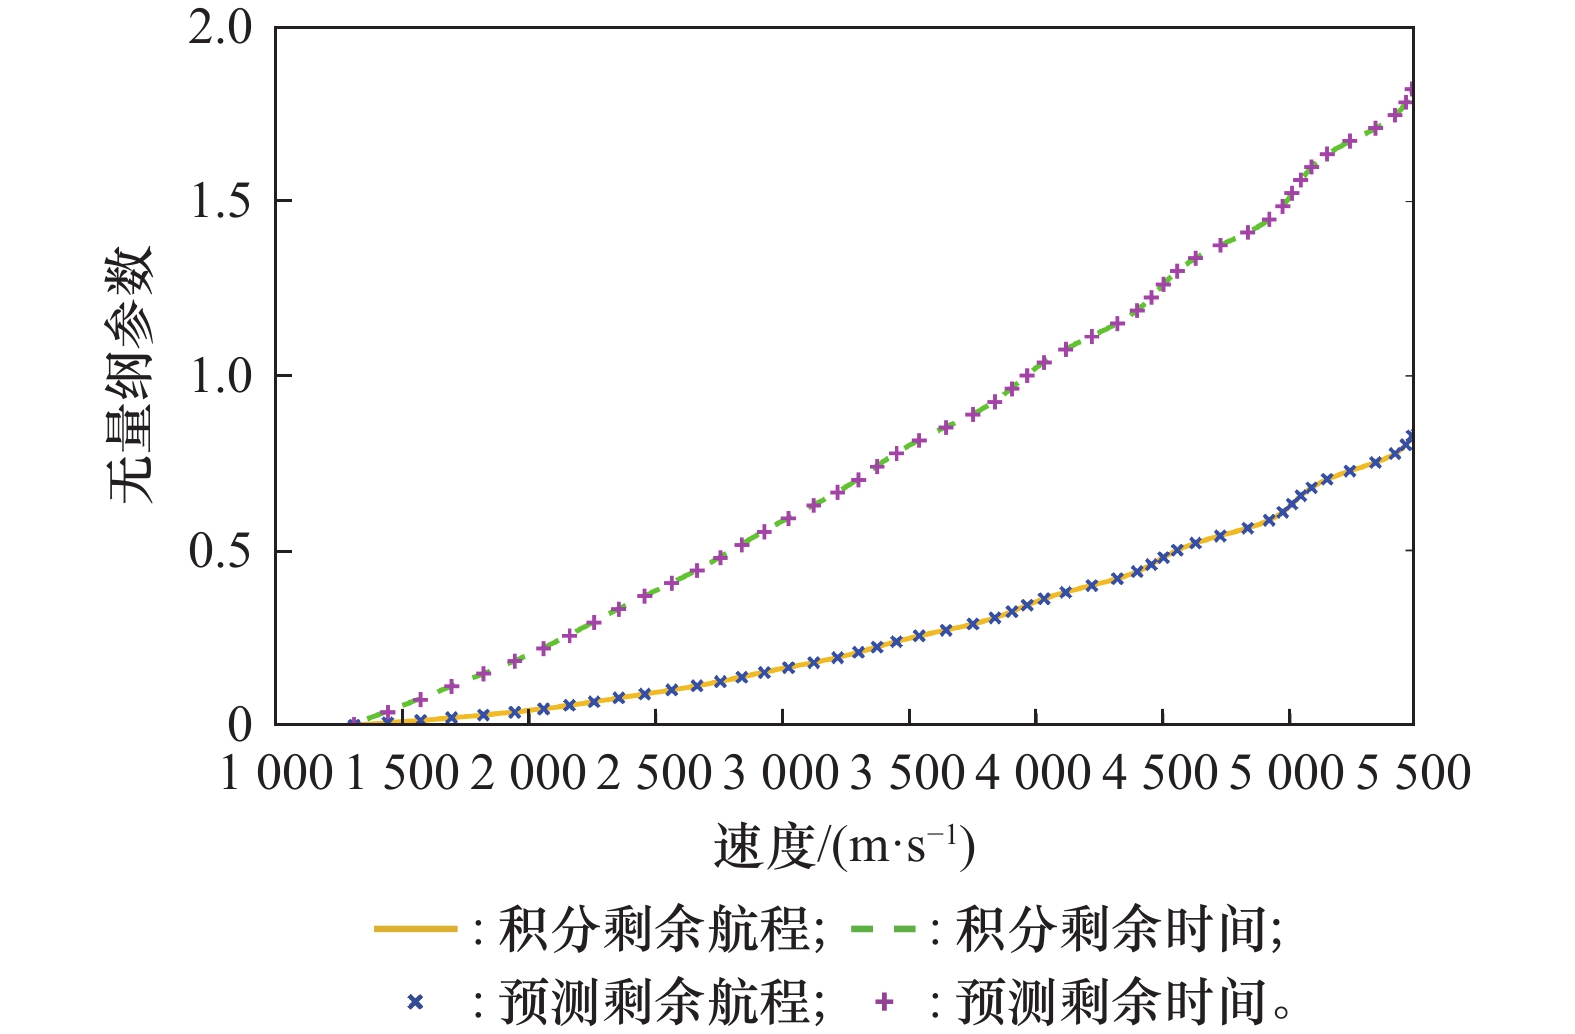
图7
基于神经网络的时间协同再入制导流程图"
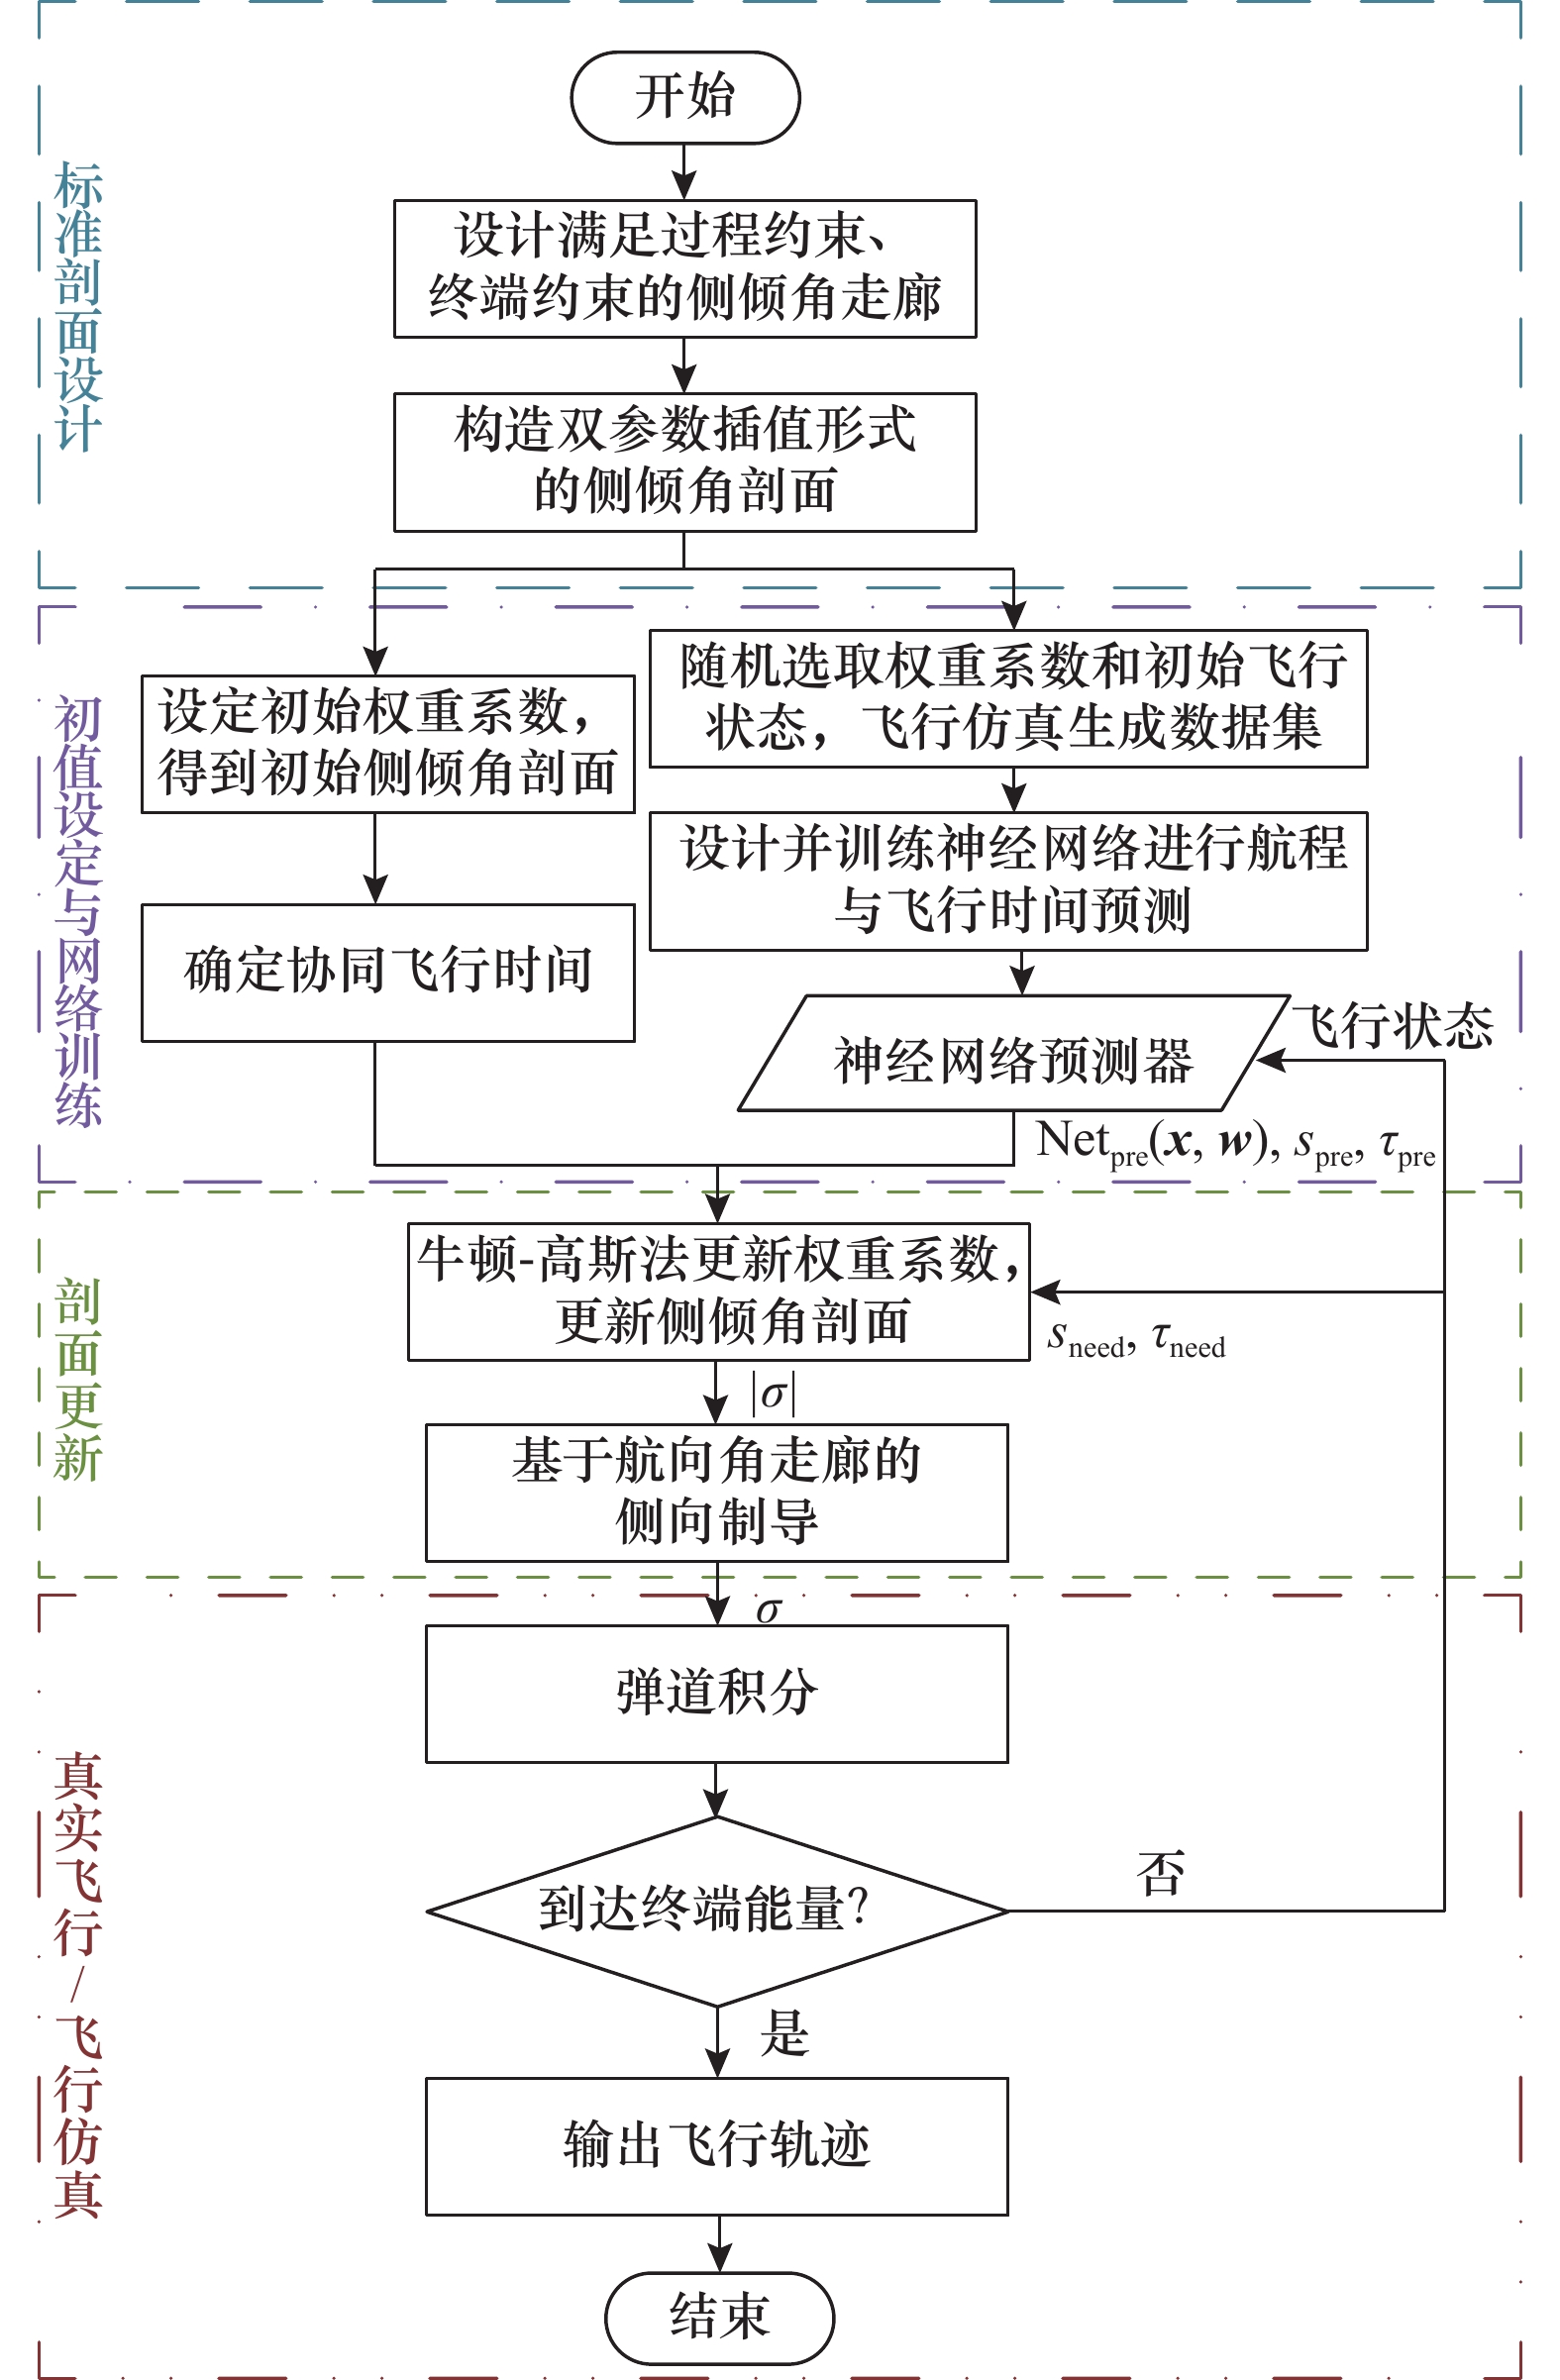
表4
再入任务"
| 再入任务 | 高度/km | 经度/(°) | 纬度/(°) | 速度/(m·s−1) | 航迹角/(°) | 航向角/(°) | 时间约束/s |
| 任务1 | 60 | 0 | 0 | 0 | 90 | ||
| 任务2 | 60 | 0 | 0 | 0 | 90 | ||
| 任务3 | 60 | 10 | 10 | 0 | 90 | ||
| 任务4 | 60 | −2 | −5 | 0 | 90 | ||
| 终端条件 | 23.5 | 49 | 2 | — | — | — |
表5
终端误差(标称条件)"
| 再入任务 | 速度/(m·s−1) | 高度/m | 航程/m | 时间/s |
| 任务1 | − | 0.3 | ||
| 任务2 | − | −1.5 | ||
| 任务3 | − | −0.4 | ||
| 任务4 | − | 1.2 |
图8
标称情况下不同再入任务仿真结果"
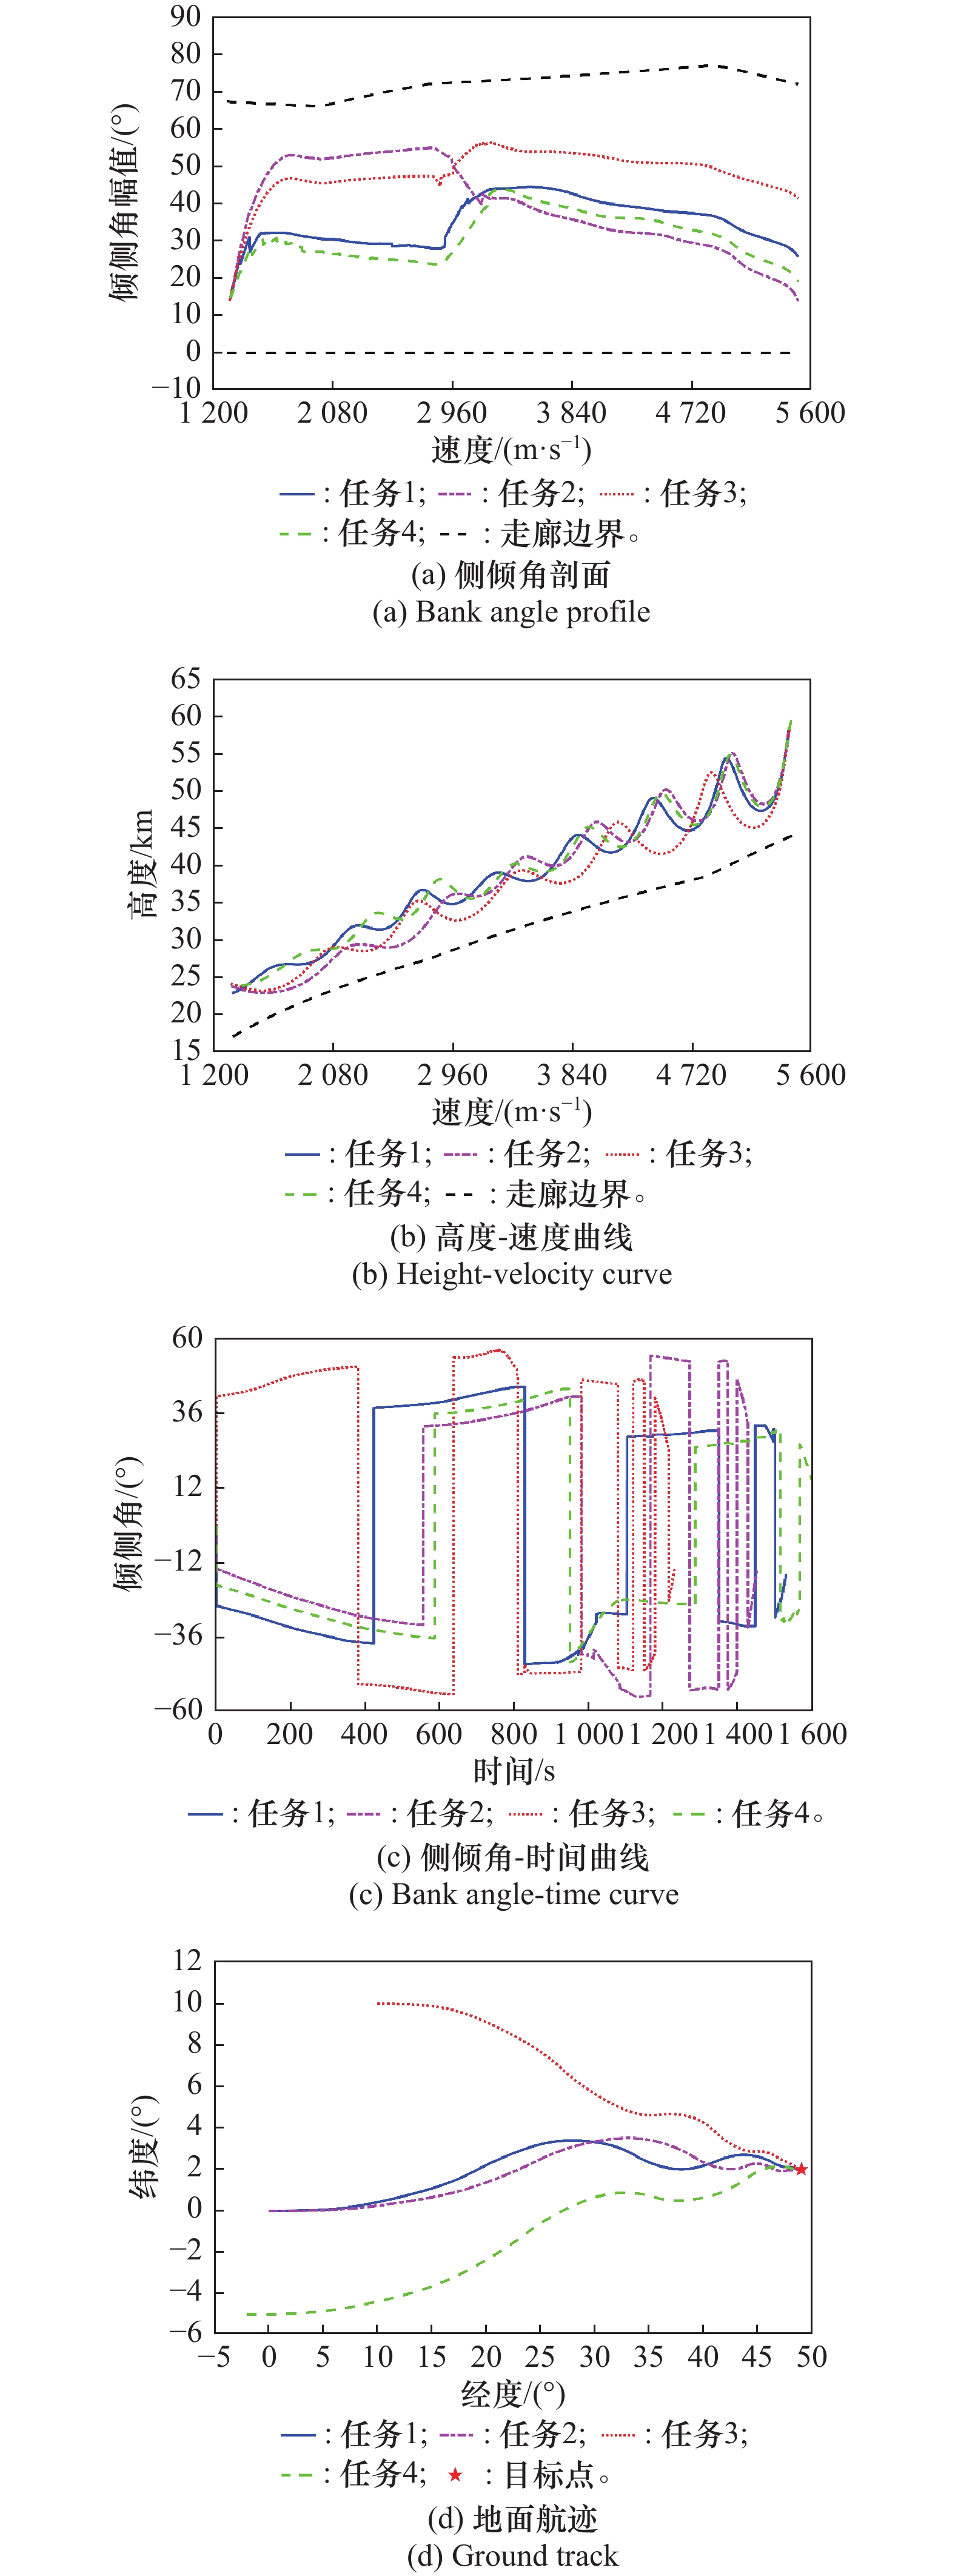
图9
神经网络预测误差箱型图"
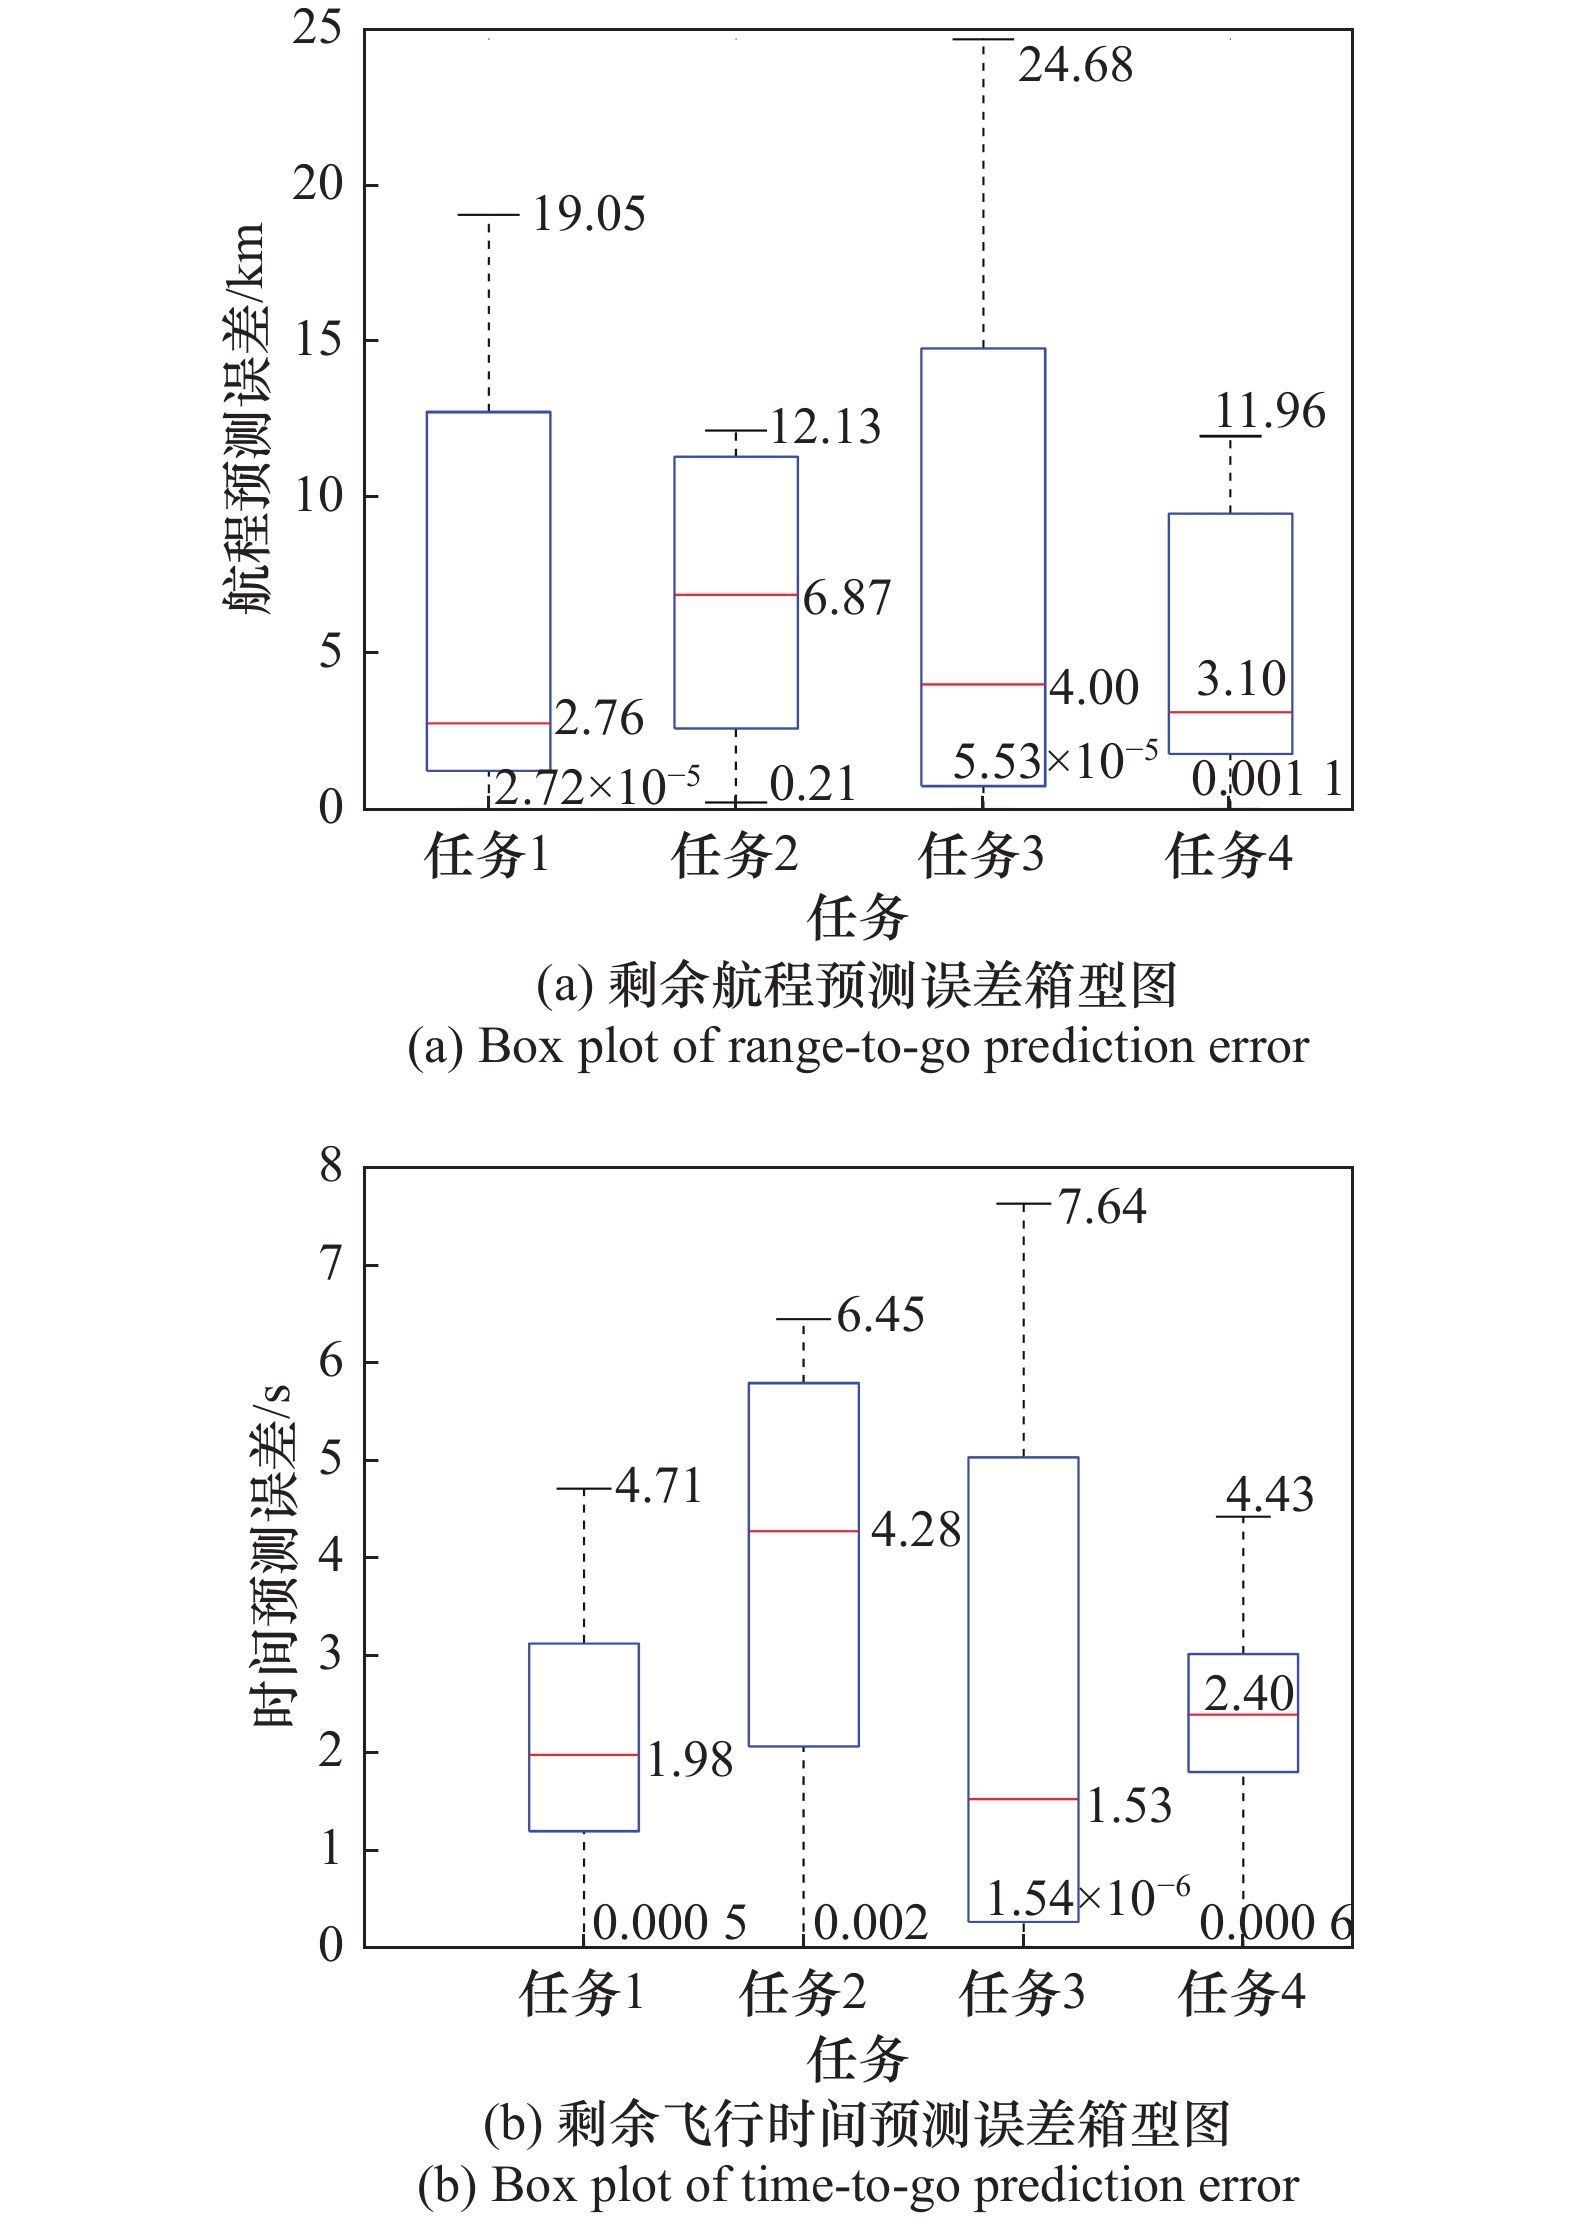
图10
预测参数偏差曲线"
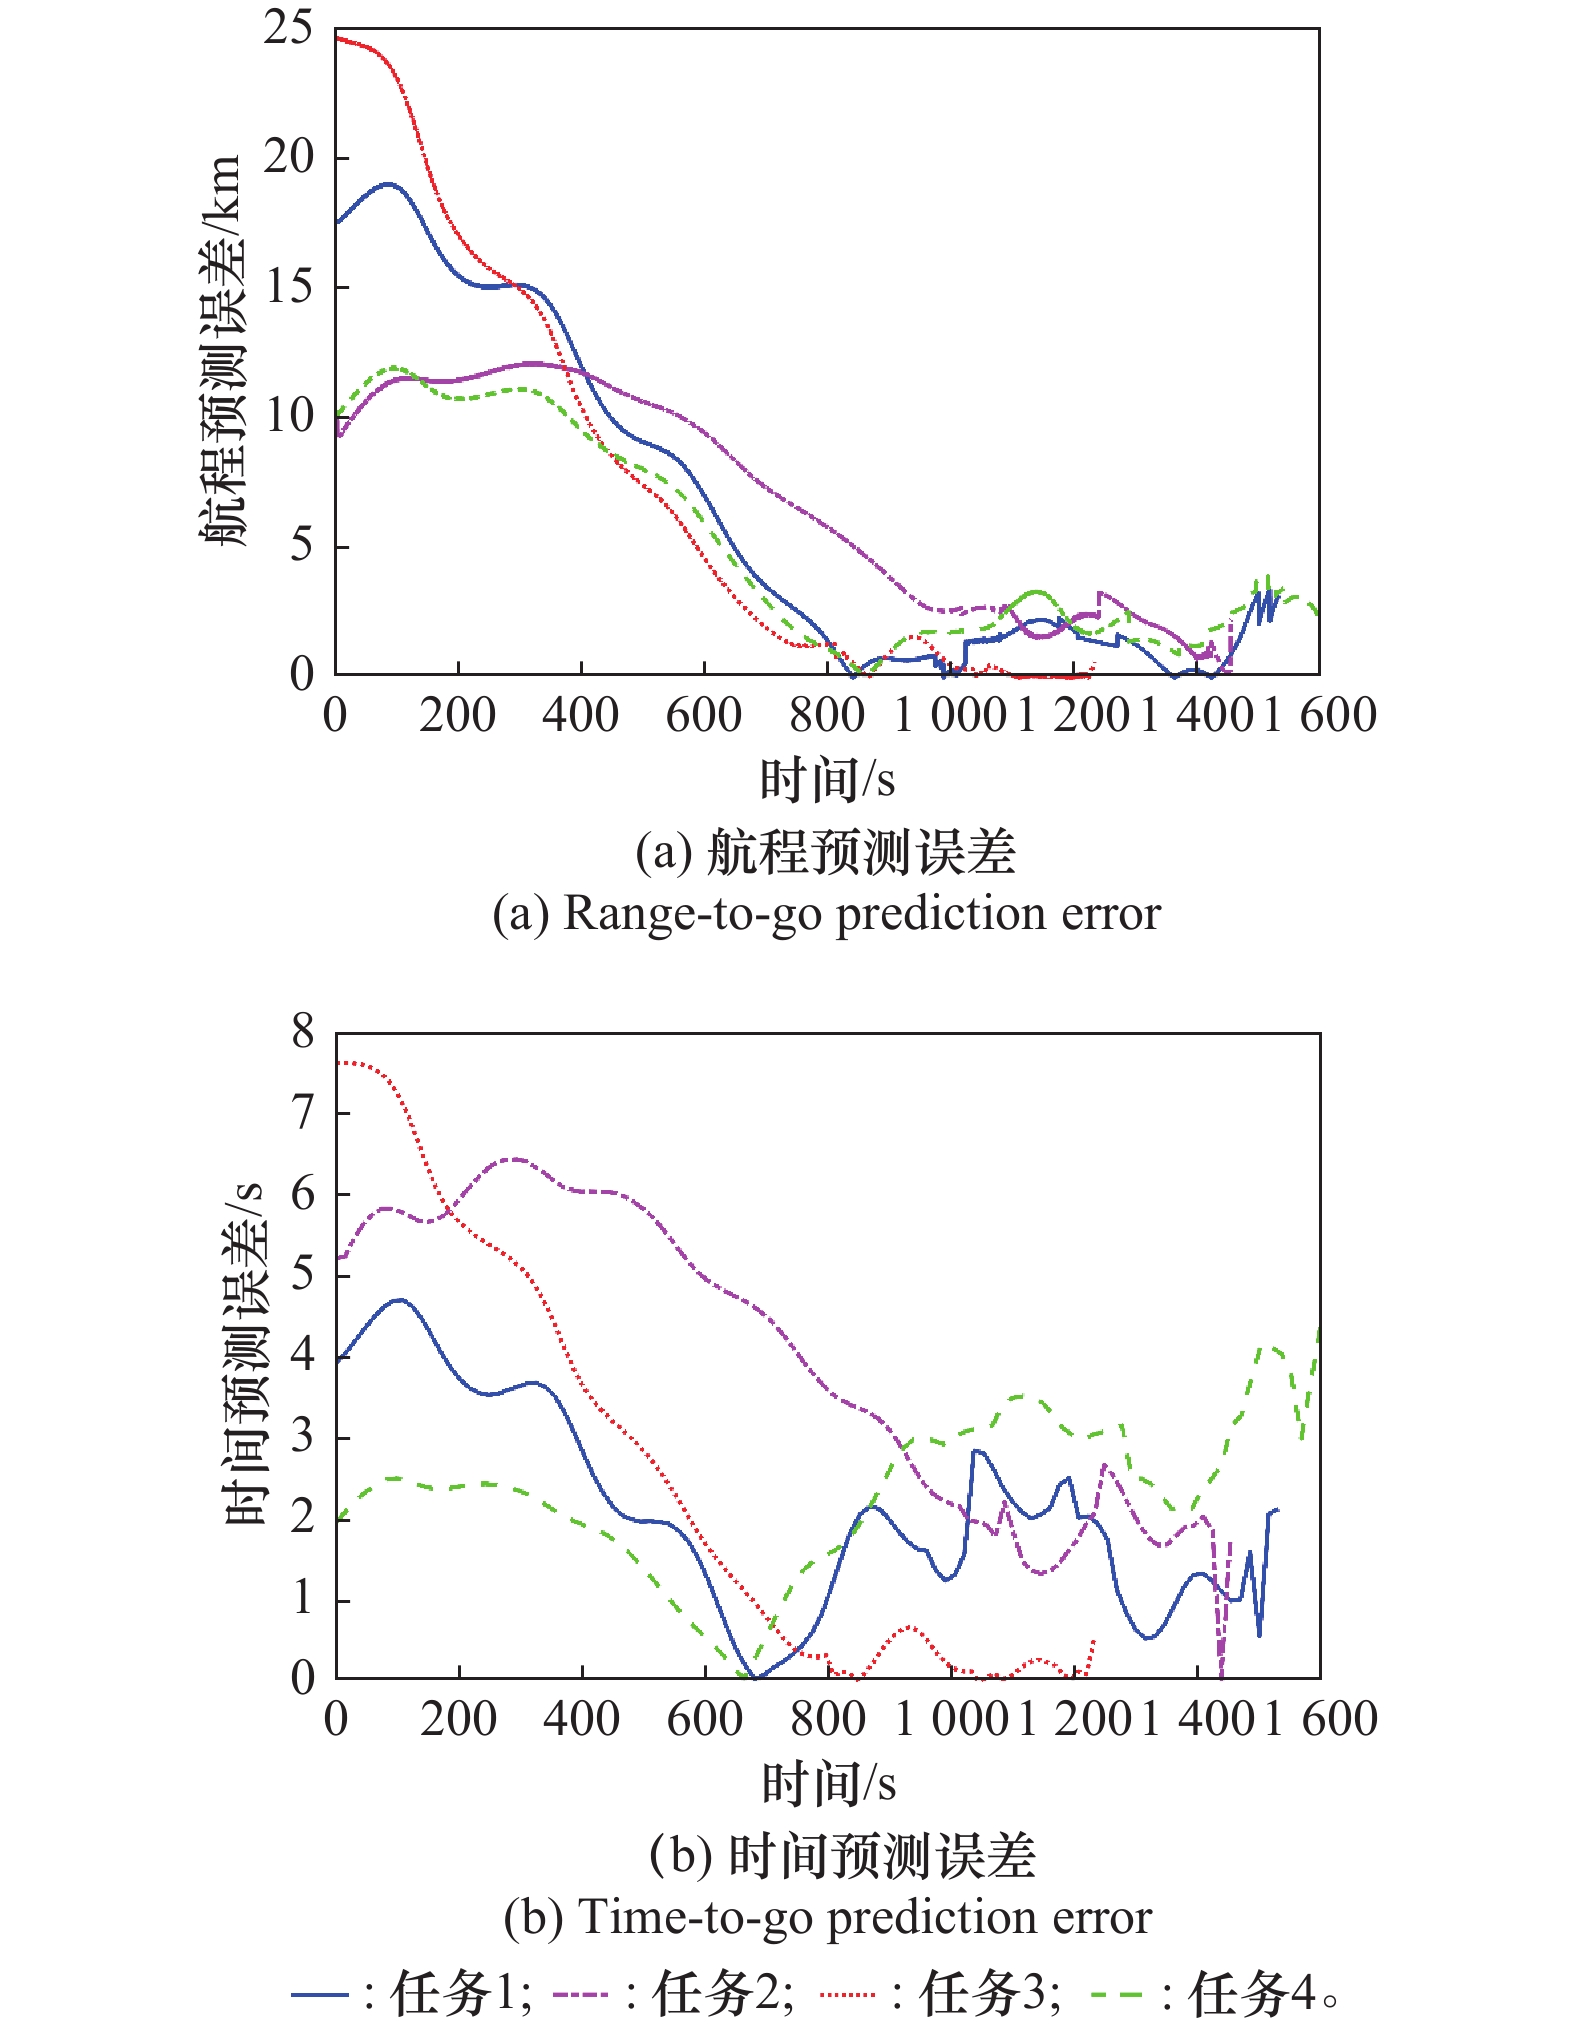
图11
预测计算耗时对比图"
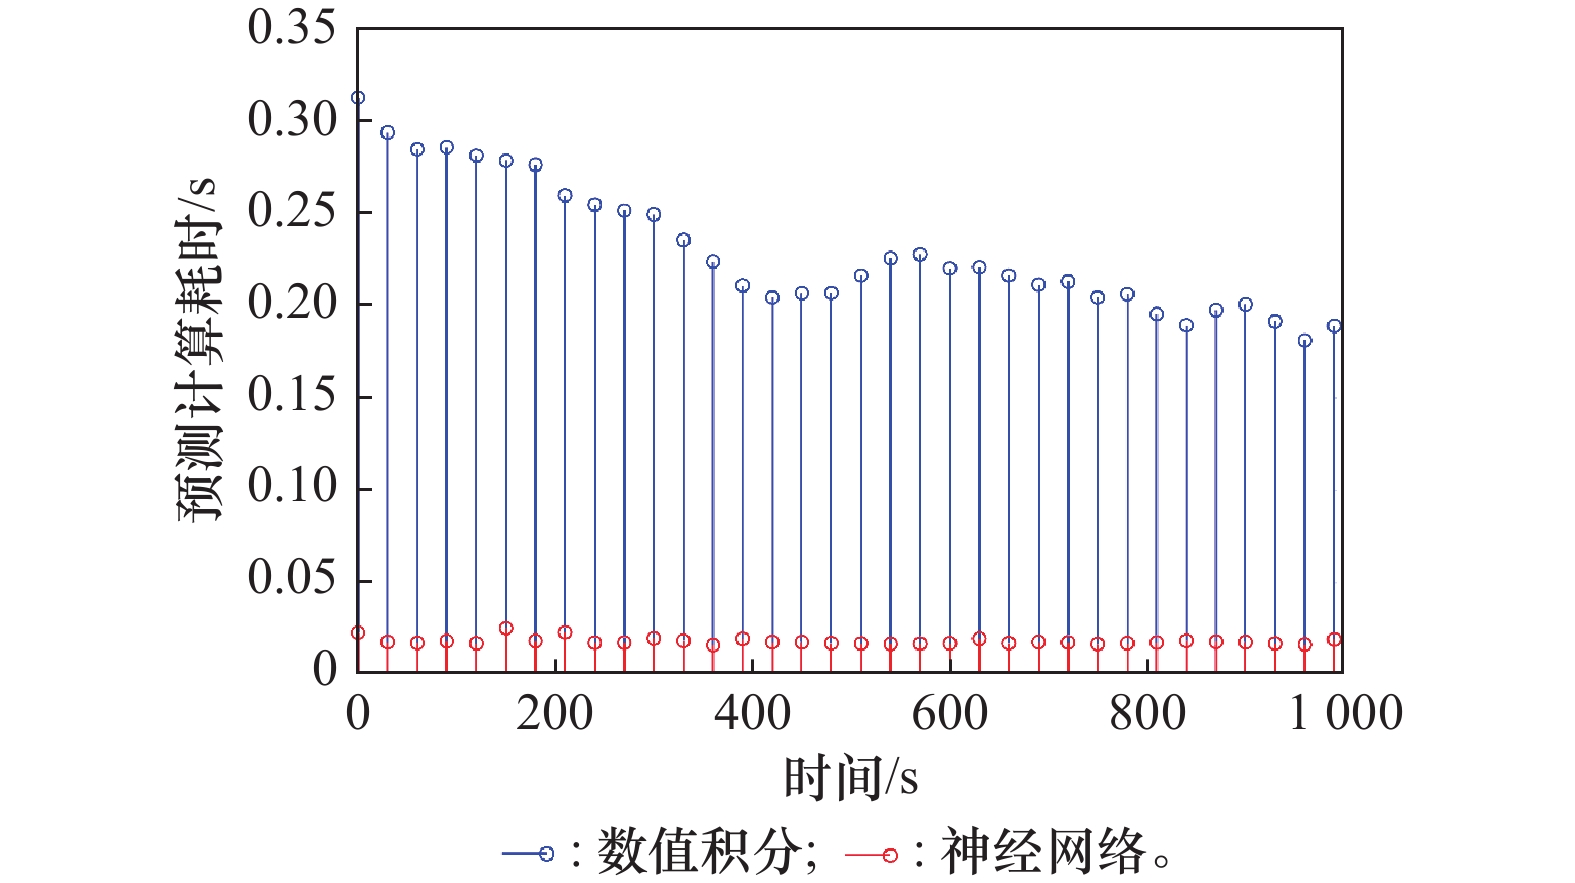
表6
不确定参数设置"
| 参数 | 偏差 | 参数 | 偏差 | |
图12
不确定条件下再入任务仿真结果"
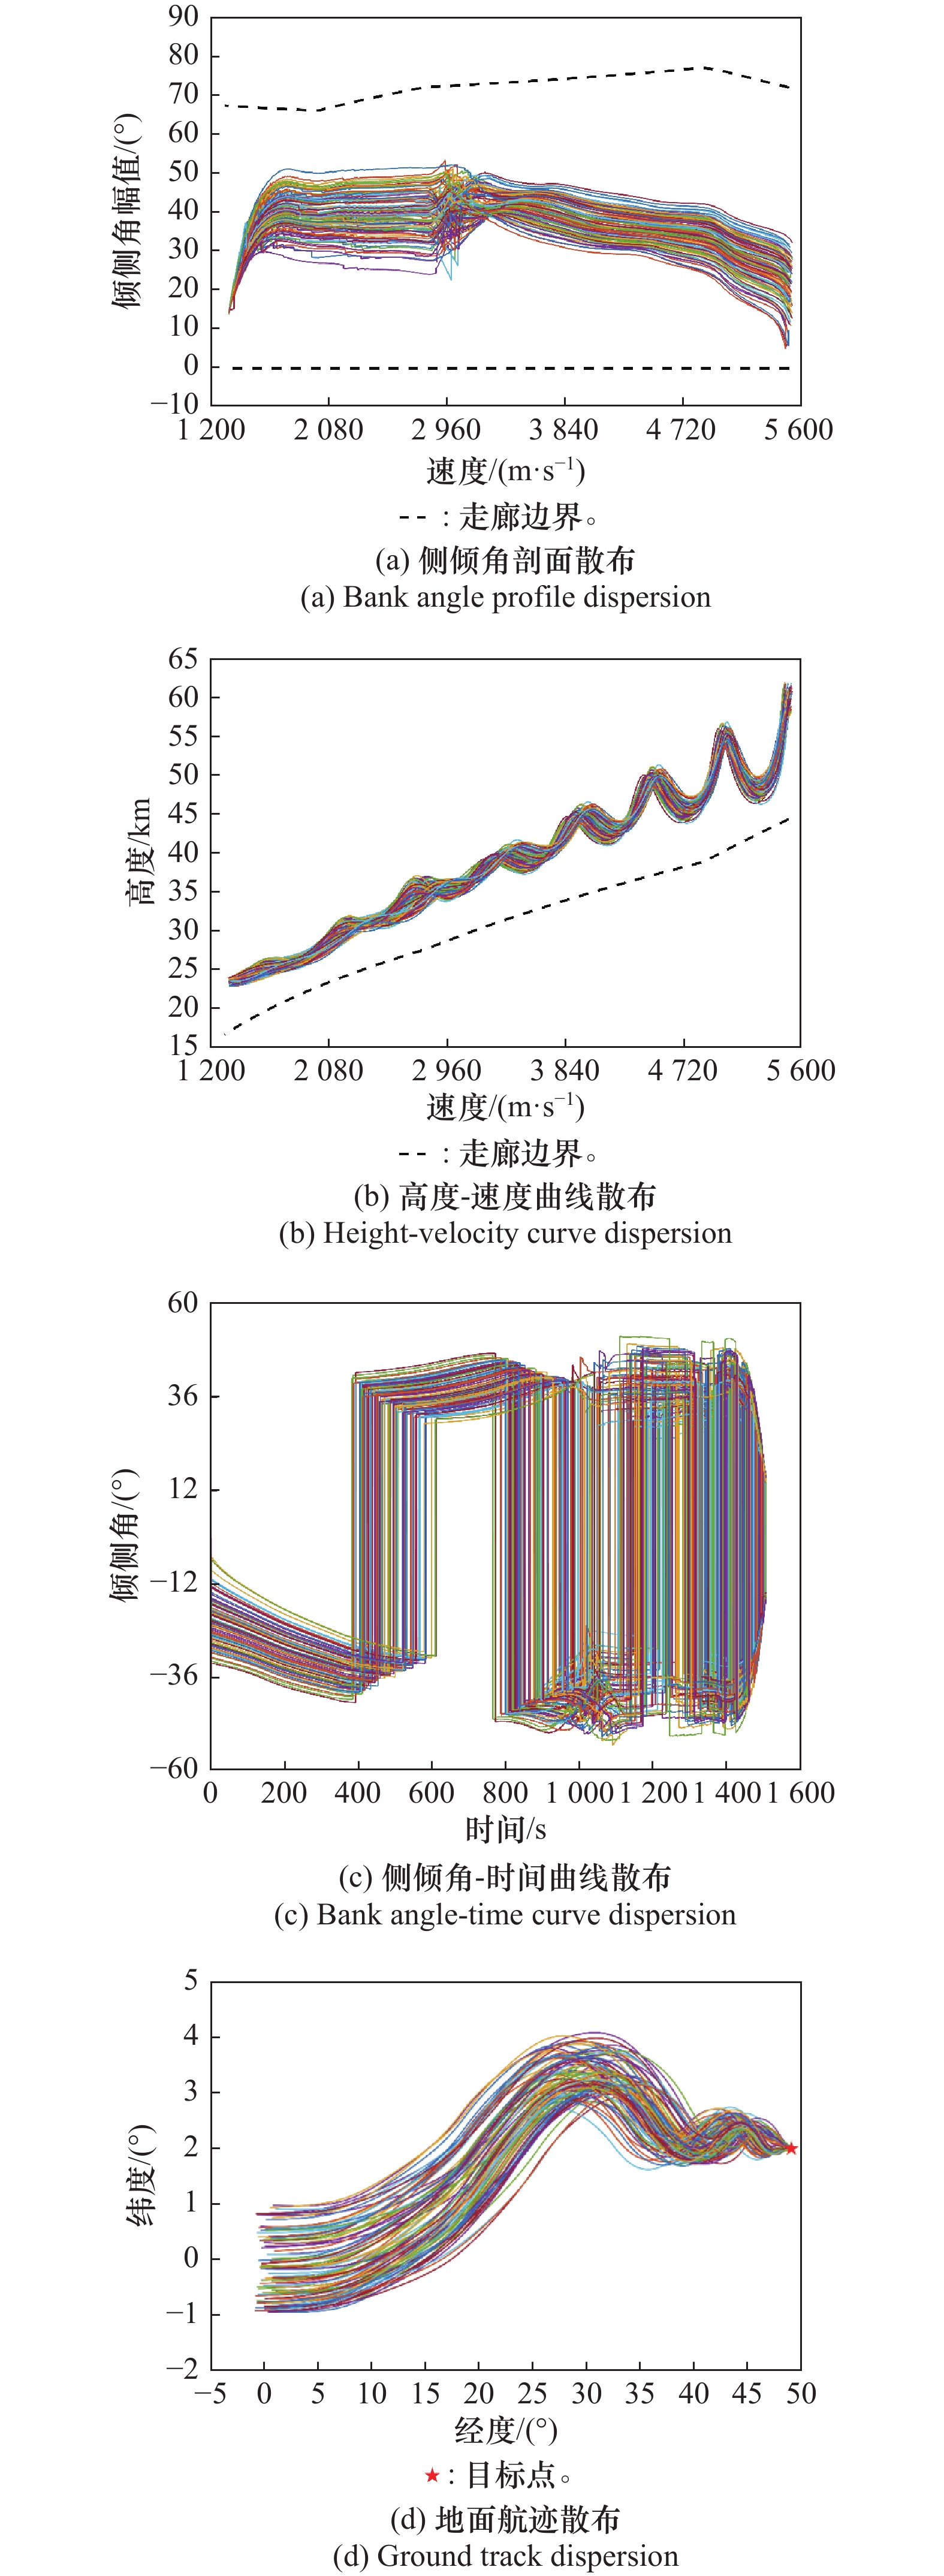
图13
不确定条件下的各状态量偏差"
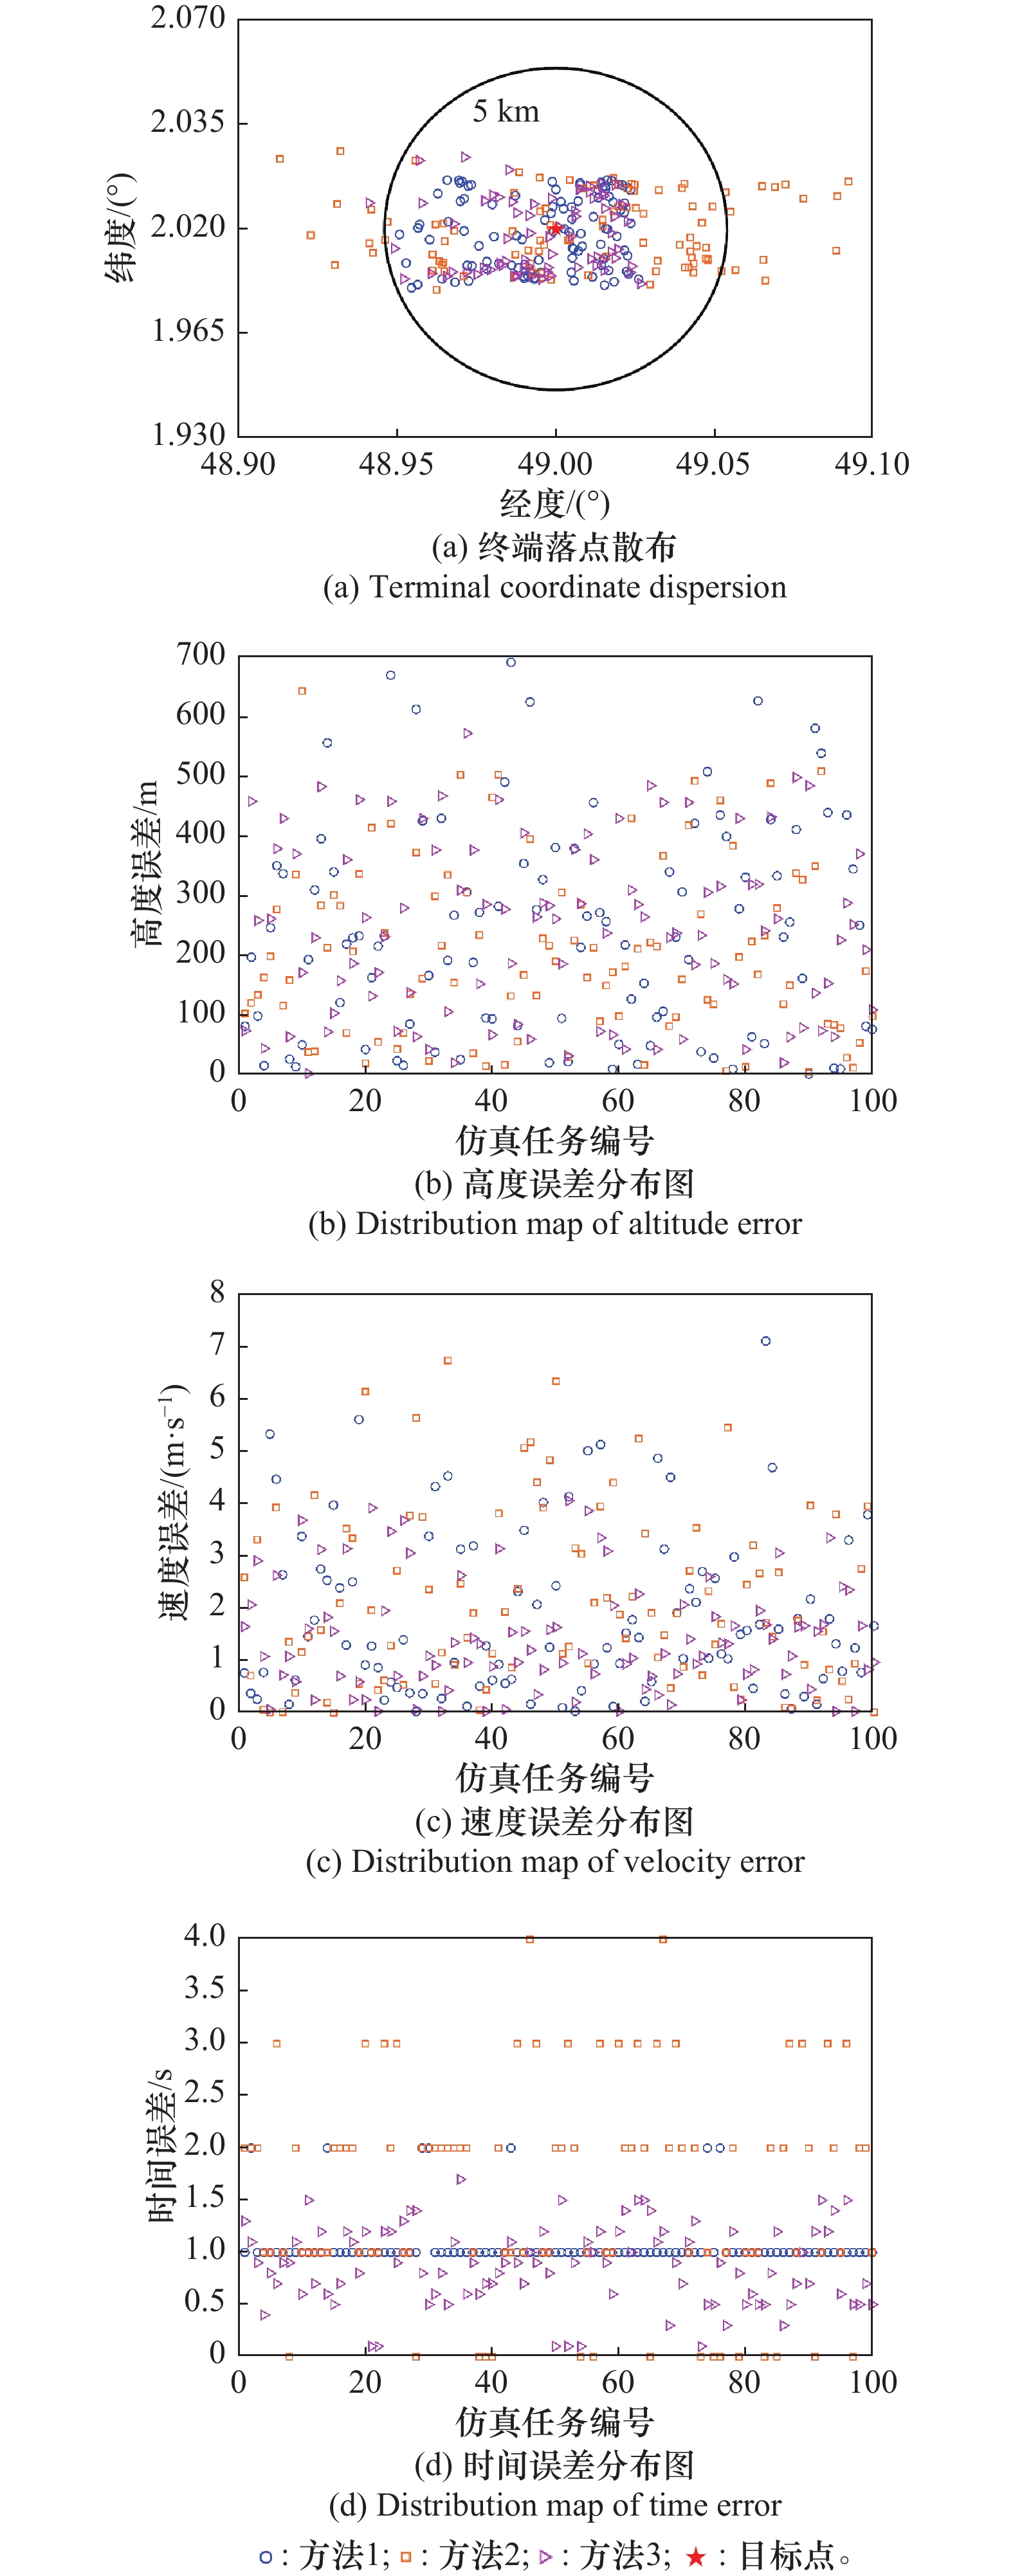
表7
不确定性条件下的终端误差绝对值统计分析"
| 终端误差 | 均值 | 最大值 | 标准差 |
| 速度1/(m·s−1) | 1.74 | 6.01 | 1.45 |
| 速度2/(m·s−1) | 2.16 | 7.09 | 1.76 |
| 速度3/(m·s−1) | 1.80 | 4.06 | 1.09 |
| 高度1/m | 253.31 | 709.53 | 168.36 |
| 高度2/m | 229.65 | 644.47 | 139.83 |
| 高度3/m | 235.43 | 573.55 | 144.92 |
| 航程1/km | 2.35 | 5.53 | 1.08 |
| 航程2/km | 4.38 | 12.12 | 2.50 |
| 航程3/km | 2.40 | 6.61 | 1.24 |
| 时间1/s | 1.07 | 2.00 | 0.26 |
| 时间2/s | 1.55 | 4.00 | 0.97 |
| 时间3/s | 0.79 | 1.70 | 0.39 |
表8
协同再入任务仿真条件设置"
| 再入任务 | 高度/km | 经度/( | 纬度/( | 速度/(m·s−1) | 航迹角/( | 航向角/( | 时间可调范围/s |
| 飞行器1 | 60 | 0 | 0 | 0 | 90 | ||
| 飞行器2 | 60 | 0. 2 | 5 | −1 | 90 | ||
| 飞行器3 | 60 | 0 | −5 | 0 | 88.5 | ||
| 飞行器4 | 60 | −1. 2 | 2 | −1 | 90 | ||
| 飞行器5 | 60 | 1. 5 | −5 | 0 | 91.5 | ||
| 飞行器6 | 60 | 2. 5 | −10 | −0.5 | 90 |
图14
时间协同情况下再入任务仿真结果"
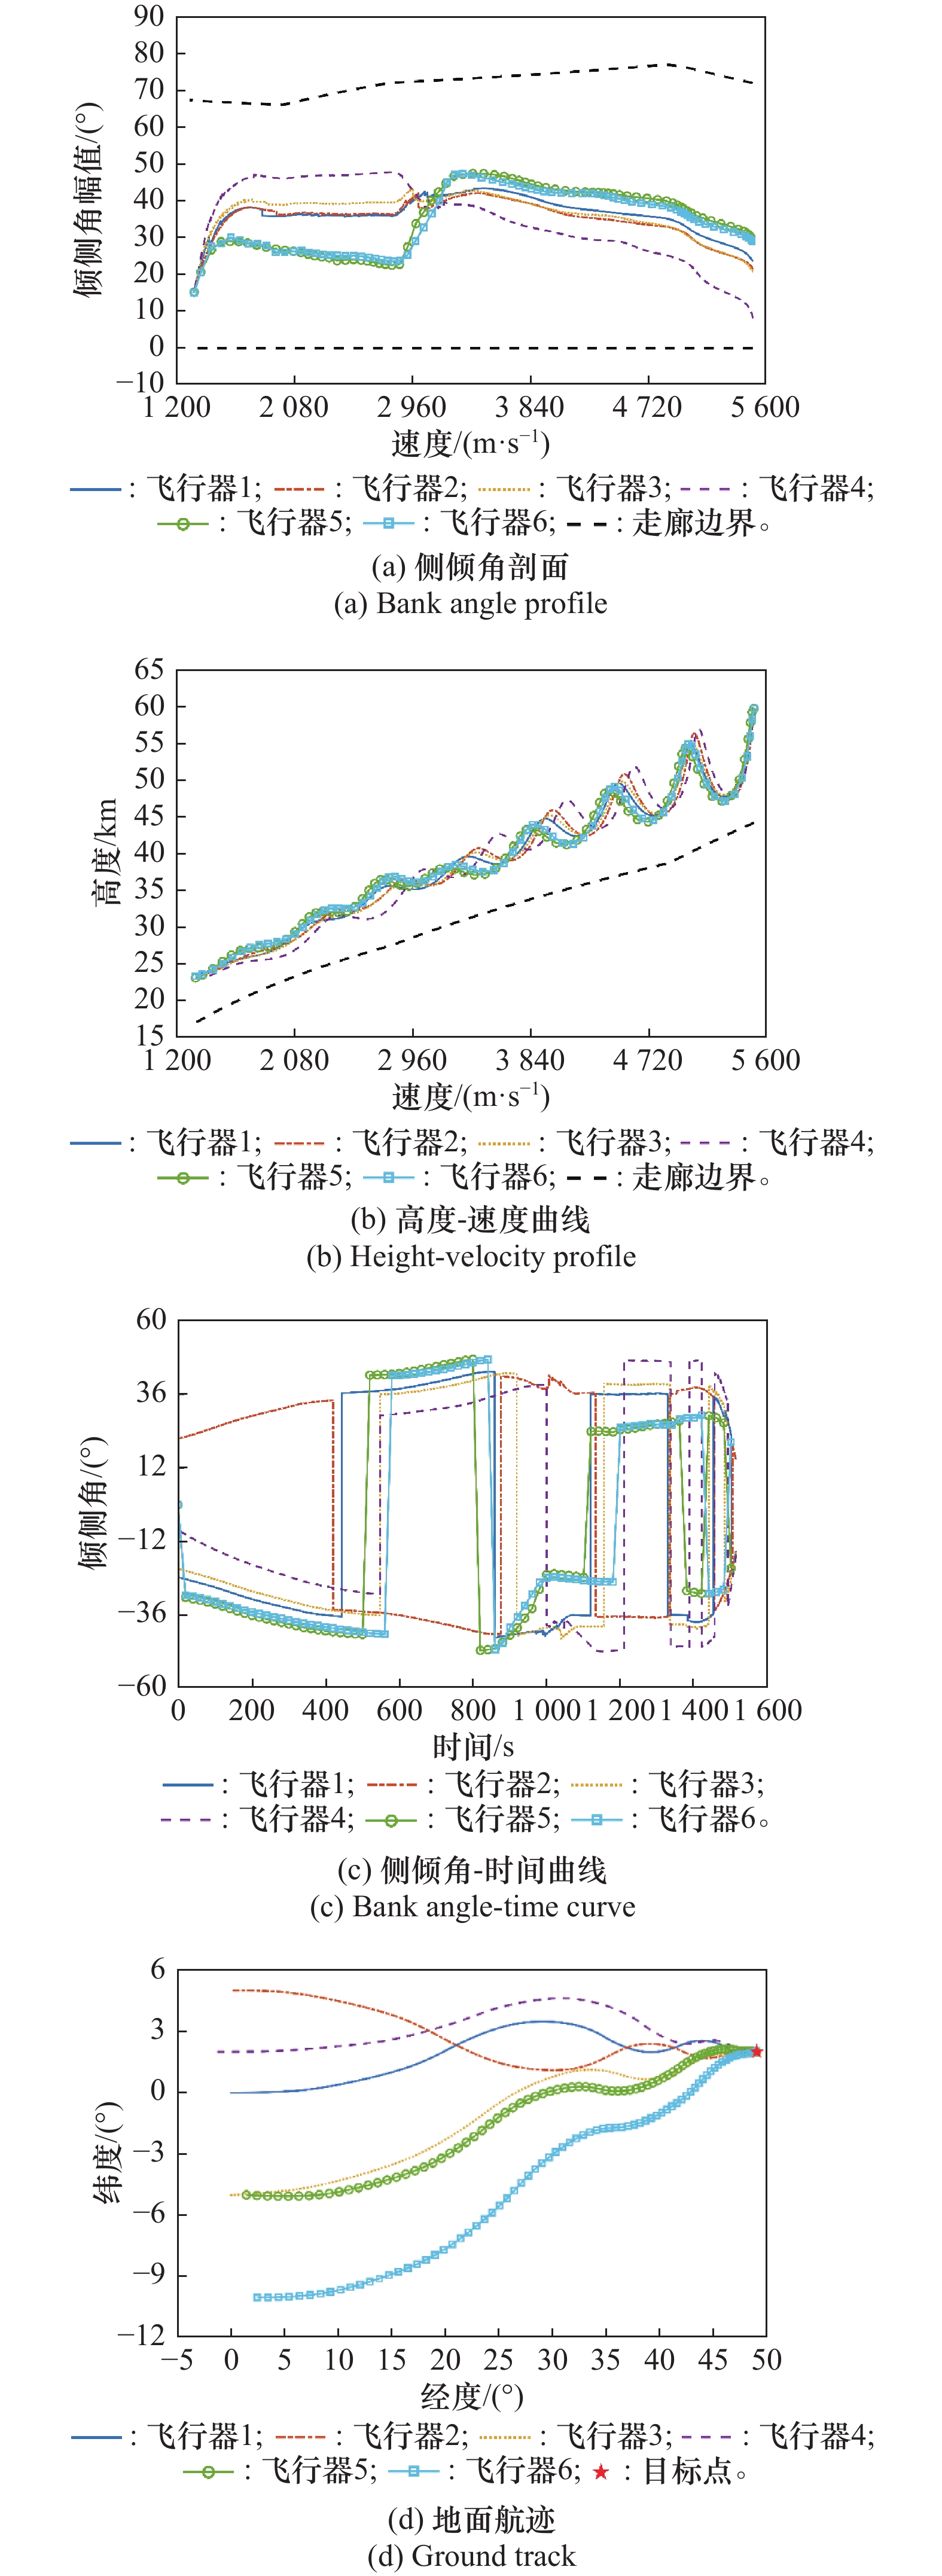
表9
终端误差(协同条件)"
| 飞行器 | 速度/(m·s−1) | 高度/m | 航程/m | 时间/s |
| 1 | − | −0.6 | ||
| 2 | − | 0.2 | ||
| 3 | − | −0.7 | ||
| 4 | − | −1.6 | ||
| 5 | − | 0.4 | ||
| 6 | − | 0.4 |
| 1 |
郭杰, 郑金库, 王浩凝, 等. 高超声速滑翔飞行器再入制导方法及热点问题研究综述[J]. 空天技术, 2022,, (1): 54.
doi: 10.16338/j.issn.2097-0714.20220607 |
| 2 | 闫循良, 王培臣, 郭杨. 再入滑翔机动突防轨迹规划与制导方法研究综述[J]. 航空学报, 2025, 46 (17): 331810. |
| 3 |
吕金虎, 于江龙, 董希旺. 飞行器集群协同制导新进展[J]. 自动化学报, 2025, 51 (4): 727.
doi: 10.16383/j.aas.c240499 |
| 4 | 南英, 龙吉松, 杨毅, 等. 自然控制理论与飞行控制[M]. 北京: 科学出版社, 2025. |
| 5 |
He S M, Luo H W, Lee C H, et al. Review of data-driven computational guidance for unmanned aerospace vehicles[J]. Progress in Aerospace Sciences, 2025, 157, 101129.
doi: 10.1016/j.paerosci.2025.101129 |
| 6 | 黄国强, 陆宇平, 南英. 飞行器轨迹优化数值算法综述[J]. 中国科学: 技术科学, 2012, 42 (9): 1016. |
| 7 | Liu X F, Shen Z J, Lu P. Entry trajectory optimization by second-order cone programming[J]. Journal of Guidance, Control, and Dynamics, 2016, 39 (2): 227. |
| 8 | Lu P. Entry guidance: a unified method[J]. Journal of Guidance, Control, and Dynamics, 2014, 37 (3): 713. |
| 9 |
Wang T, Zhang H B, Zeng L, et al. A robust predictor-corrector entry guidance[J]. Aerospace Science and Technology, 2017, 66, 103.
doi: 10.1016/j.ast.2017.03.010 |
| 10 |
Lee Y, Lee D D, Wie B. Autonomous numerical predictor-corrector guidance for human Mars landing missions[J]. Aerospace Science and Technology, 2025, 156, 109755.
doi: 10.1016/j.ast.2024.109755 |
| 11 |
张旭辉, 汪韧, 马超越. 考虑禁飞区约束的飞行器协同轨迹规划[J]. 宇航学报, 2025, 46 (4): 641.
doi: 10.3873/j.issn.1000-1328.2025.04.001 |
| 12 |
Liu X, Li X, Zhang H J, et al. Entry guidance with terminal time constraint based on reduced-order dynamics[J]. IEEE Trans. on Aerospace and Electronic Systems, 2025, 61 (3): 5949.
doi: 10.1109/TAES.2024.3524200 |
| 13 |
Li Z H, He B, Wang M H, et al. Time-coordination entry guidance for multi-hypersonic vehicles[J]. Aerospace Science and Technology, 2019, 89, 123.
doi: 10.1016/j.ast.2019.03.056 |
| 14 | 韩宛汝, 刘俊辉, 单家元, 等. 终端航向角与时间约束的迭代再入制导方法[J]. 系统工程与电子技术, 2026, 48(2): 638. |
| 15 |
Yang H D, Liang H Z, Liu J Q, et al. Analytical time-coordinated entry guidance for multi-hypersonic vehicles within three-dimensional corridor[J]. Aerospace Science and Technology, 2024, 155, 109639.
doi: 10.1016/j.ast.2024.109639 |
| 16 |
Wang P C, Yan X L, Nan W J, et al. Adaptive entry guidance with time and full state constraints using analytical drag-vs-energy profile[J]. Advances in Space Research, 2025, 75 (12): 8860.
doi: 10.1016/j.asr.2025.04.017 |
| 17 |
Liu Z Z, Zheng G D, Zhang B, et al. Predictor-corrector reentry guidance for hypersonic glide vehicles based on high-precision analytical solutions[J]. Aerospace Science and Technology, 2024, 155, 109545.
doi: 10.1016/j.ast.2024.109545 |
| 18 |
Zhang T F, Zhang L C, Gong C L, et al. Weight-adaptive parameter estimation assisted event-triggered model predictive guidance for reentry[J]. Aerospace Science and Technology, 2025, 158, 109938.
doi: 10.1016/j.ast.2025.109938 |
| 19 |
方科, 张庆振, 倪昆, 等. 高超声速飞行器时间协同再入制导[J]. 航空学报, 2018, 39 (5): 321958.
doi: 10.7527/S1000-6893.2018.21958 |
| 20 |
Li Z, Guo J, Tang S, et al. A deep learning-based approach to time-coordination entry guidance for multiple hypersonic vehicles[J]. The Aeronautical Journal, 2023, 127 (1310): 604.
doi: 10.1017/aer.2022.82 |
| 21 | Cheng L, Jiang F H, Wang Z B, et al. Multiconstrained real-time entry guidance using deep neural networks[J]. IEEE Trans. on Aerospace and Electronic Systems, 2020, 57 (1): 325. |
| 22 | Li Q, Yu J L, Hua Y Z, et al. Cooperative time-guidance strategy for multihypersonic vehicles with irregular no-fly zones: a Transformer-based real-time planning method[J]. IEEE Trans. on Aerospace and Electronic Systems, 2024, 61 (2): 1283. |
| 23 |
闫循良, 王宽, 张子剑, 等. 基于LSTM-DDPG的再入制导方法[J]. 系统工程与电子技术, 2025, 47 (1): 268.
doi: 10.12305/j.issn.1001-506X.2025.01.27 |
| 24 |
Tong X D, Song J, Li W L, et al. Penetration game strategy of high dynamic vehicles with constraints of no-fly zones and interceptors[J]. Engineering Applications of Artificial Intelligence, 2024, 136, 109018.
doi: 10.1016/j.engappai.2024.109018 |
| 25 |
Wu T C, Wang H L, Liu Y H, et al. Learning-based interfered fluid avoidance guidance for hypersonic reentry vehicles with multiple constraints[J]. ISA Transactions, 2023, 139, 291.
doi: 10.1016/j.isatra.2023.04.004 |
| 26 |
南英, 吕学富, 陈士楷. 航天器的再入走廊及其计算方法[J]. 飞行力学, 1993, 11 (2): 34.
doi: 10.13645/j.cnki.f.d.1993.02.005 |
| 27 | 南英, 陈士楷, 王志刚. 航天器最优再入轨迹的选择分析[J]. 宇航学报, 1996, 17 (4): 105. |
| 28 |
Cheng L, Wang Z B, Cheng Y, et al. Multi-constrained predictor-corrector reentry guidance for hypersonic vehicles[J]. Proceedings of the Institution of Mechanical Engineers, Part G: Journal of Aerospace Engineering, 2018, 232 (16): 3049.
doi: 10.1177/0954410017724185 |
| 29 | 王肖, 郭杰, 唐胜景, 等. 基于解析剖面的时间协同再入制导[J]. 航空学报, 2019, 40 (3): 322565. |
| 30 | Phillips T H. A common aero vehicle (CAV) model, description, and employment guide[R]. New York: Schafer Corporation for Air Force Research Laboratory and Air Force Space Command, 2003. |
| [1] | 胡国梁, 潘继飞, 刘方正, 龚阳, 孙兵, 郭林青. 低信噪比条件下雷达调制样式识别的多任务学习算法[J]. 系统工程与电子技术, 2026, 48(9): 2939-2948. |
| [2] | 魏帅, 谢荣, 杨洪飞, 许述文, 刘峥. 基于多尺度加权GCN的有源干扰识别方法[J]. 系统工程与电子技术, 2026, 48(9): 2958-2968. |
| [3] | 王兆辰, 杨华东, 孙海文, 靳子荣. 基于霜冰优化算法的无人机路径优选CNN-LSTM-Attention模型[J]. 系统工程与电子技术, 2026, 48(9): 3104-3118. |
| [4] | 王全全, 昝雨轩, 缪宜恒, 胡海峰, 吴城坤. 基于多维特征和TSOA-CNN的协作频谱感知方法[J]. 系统工程与电子技术, 2026, 48(9): 3260-3265. |
| [5] | 侯煊铭, 许河川, 琚啸哲, 韦常柱. RLV再入段自适应非奇异预定时间姿态收敛控制[J]. 系统工程与电子技术, 2026, 48(8): 2790-2801. |
| [6] | 王和, 雷刚, 李少朋, 茅琦杰, 刘振宇. 具有拦截区与落角约束的高超声速飞行器俯冲段鲁棒制导方法[J]. 系统工程与电子技术, 2026, 48(8): 2841-2849. |
| [7] | 张霄嵩, 王鼎衡, 李昊飞, 王一朋, 张岳, 刘保荣, 贾世诚. 面向战场复杂场景的增强识别方法[J]. 系统工程与电子技术, 2026, 48(7): 2172-2183. |
| [8] | 刘畅, 王凌宇, 夏浪, 李岳峰, 林欣, 刘艳阳, 黄鹏辉. 基于小波散射激励与SimAM的轻量化抗噪卷积神经网络的目标识别[J]. 系统工程与电子技术, 2026, 48(7): 2184-2194. |
| [9] | 李强, 周荻, 李思远, 林玉荣. 基于元学习与预测控制的导弹自适应制导[J]. 系统工程与电子技术, 2026, 48(7): 2424-2433. |
| [10] | 黄琼丹, 刘露露, 韩洁婧, 王佳鹏, 康仕林. 基于差异特征反投影融合的图像超分辨重建[J]. 系统工程与电子技术, 2026, 48(6): 1809-1818. |
| [11] | 袁胜智, 王少蕾, 李静, 肖任楷, 谭浩天, 赖建伟, 许江涛. 基于小波变换和改进残差神经网络的故障诊断方法[J]. 系统工程与电子技术, 2026, 48(6): 2031-2041. |
| [12] | 安帅斌, 刘泓麟, 董哲, 刘君, 刘凯. 吸气式高超声速飞行器高性能姿态控制方法[J]. 系统工程与电子技术, 2026, 48(6): 2042-2051. |
| [13] | 罗雨泉, 何雨强, 李雅鑫, 梁松, 王俊. 基于CNN-BiLSTM-MHA时空融合框架的毫米波雷达人体姿态估计[J]. 系统工程与电子技术, 2026, 48(5): 1502-1514. |
| [14] | 刘璐瑶, 金晓, 蔡金良, 张武才. 结合ANN及改进MOPSO的天线布局多目标优化[J]. 系统工程与电子技术, 2026, 48(5): 1607-1614. |
| [15] | 王婕, 孙笑轩, 李擎, 卢昊. 高超声速飞行器预定时间量化容错协同控制[J]. 系统工程与电子技术, 2026, 48(5): 1728-1737. |
| 阅读次数 | ||||||
|
全文 |
|
|||||
|
摘要 |
|
|||||
