系统工程与电子技术 ›› 2026, Vol. 48 ›› Issue (11): 3989-3998.doi: 10.12305/j.issn.1001-506X.2026.11.28
郭瑶瑶1, 董瀚林2, 马志强1, 黄攀峰1, 刘正雄1
收稿日期:2025-08-11
修回日期:2025-12-26
出版日期:2026-10-25
发布日期:2026-05-14
通讯作者:
刘正雄
作者简介:郭瑶瑶(2002—),女,硕士研究生,主要研究方向为空间态势理解、数字孪生、人机交互基金资助:Yaoyao Guo1, Hanlin Dong2, Zhiqiang Ma1, Panfeng Huang1, Zhengxiong Liu1
Received:2025-08-11
Revised:2025-12-26
Online:2026-10-25
Published:2026-05-14
Contact:
Zhengxiong Liu
摘要:
针对交互设备紧凑构型限制工作空间导致频繁复位,自由度耦合现象降低精细作业效率的问题,提出一种基于串并联复合构型的六自由度手控器。首先,通过运动学链重构与连杆参数优化完成手控器结构设计。然后,提出一种结合移轴处理与虚拟关节辅助的运动学分析方法验证设计的合理性。最后,搭建虚拟模型可视化仿真平台验证运动的协调性和连续性。试验结果表明,本手控器在实现各维度独立控制的基础上,其多自由度联动性能同样优异。相较于Touch、omega.7等市面常见设备而言,本手控器在保持同等紧凑性的同时,实现工作空间利用率(工作空间/设备体积)4倍以上的提升,为复合式串并联手控器的开发提供可参考的设计思路和技术路径。
中图分类号:
郭瑶瑶, 董瀚林, 马志强, 黄攀峰, 刘正雄. 新构型六自由度手控器的设计与分析[J]. 系统工程与电子技术, 2026, 48(11): 3989-3998.
Yaoyao Guo, Hanlin Dong, Zhiqiang Ma, Panfeng Huang, Zhengxiong Liu. Design and analysis of a new 6-DOF hand controller[J]. Systems Engineering and Electronics, 2026, 48(11): 3989-3998.
图1
手控器的结构原理示意图"
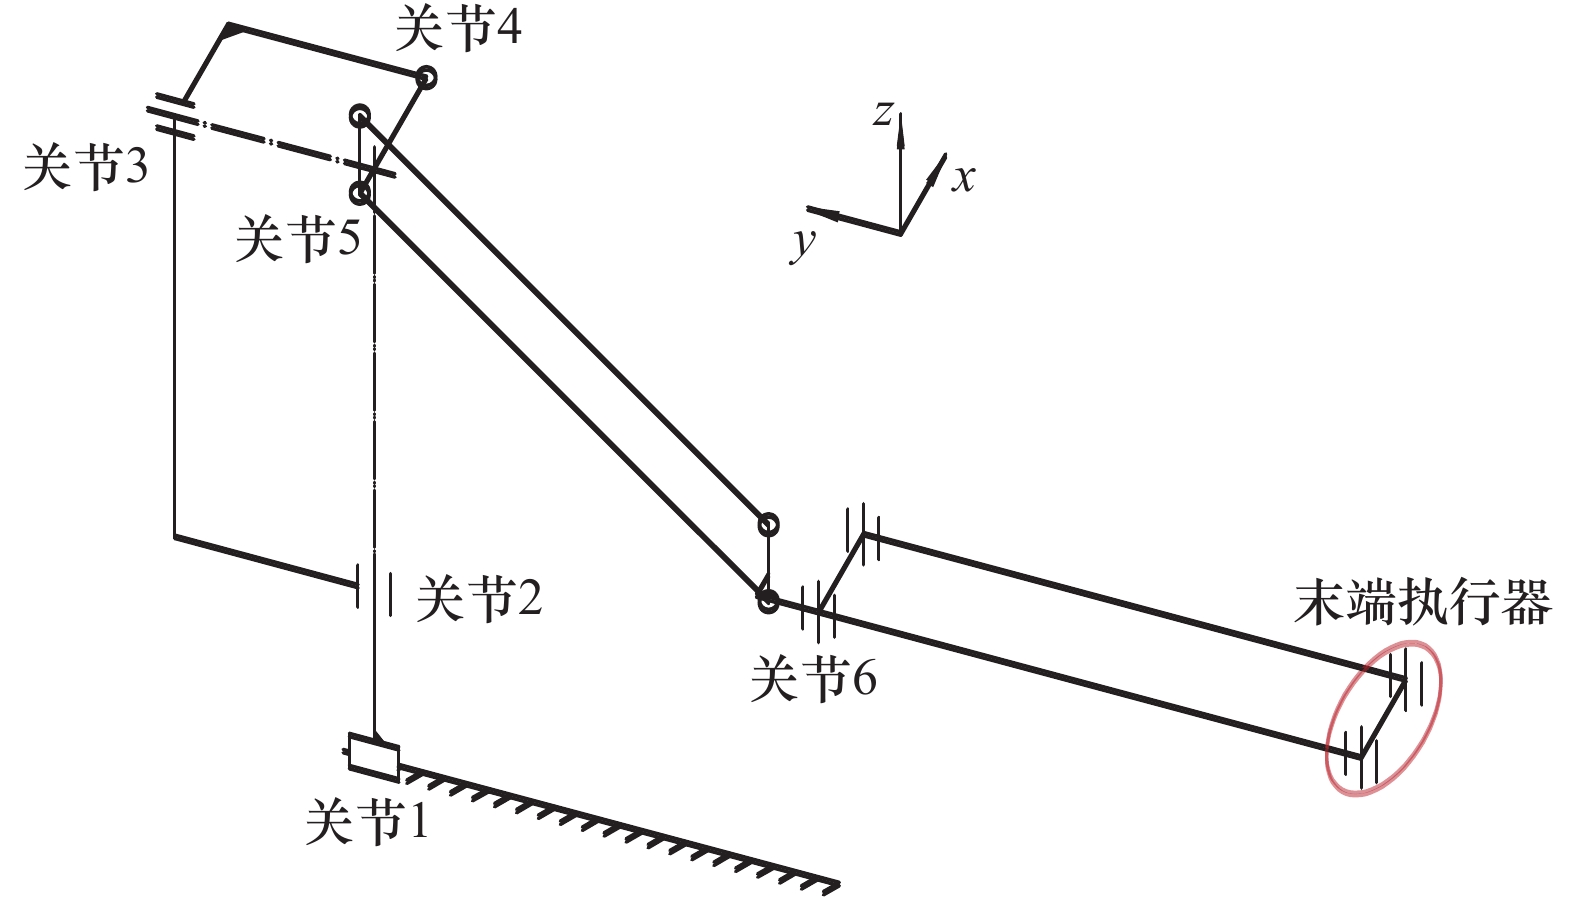
图2
手控器三维模型(上半部分)"
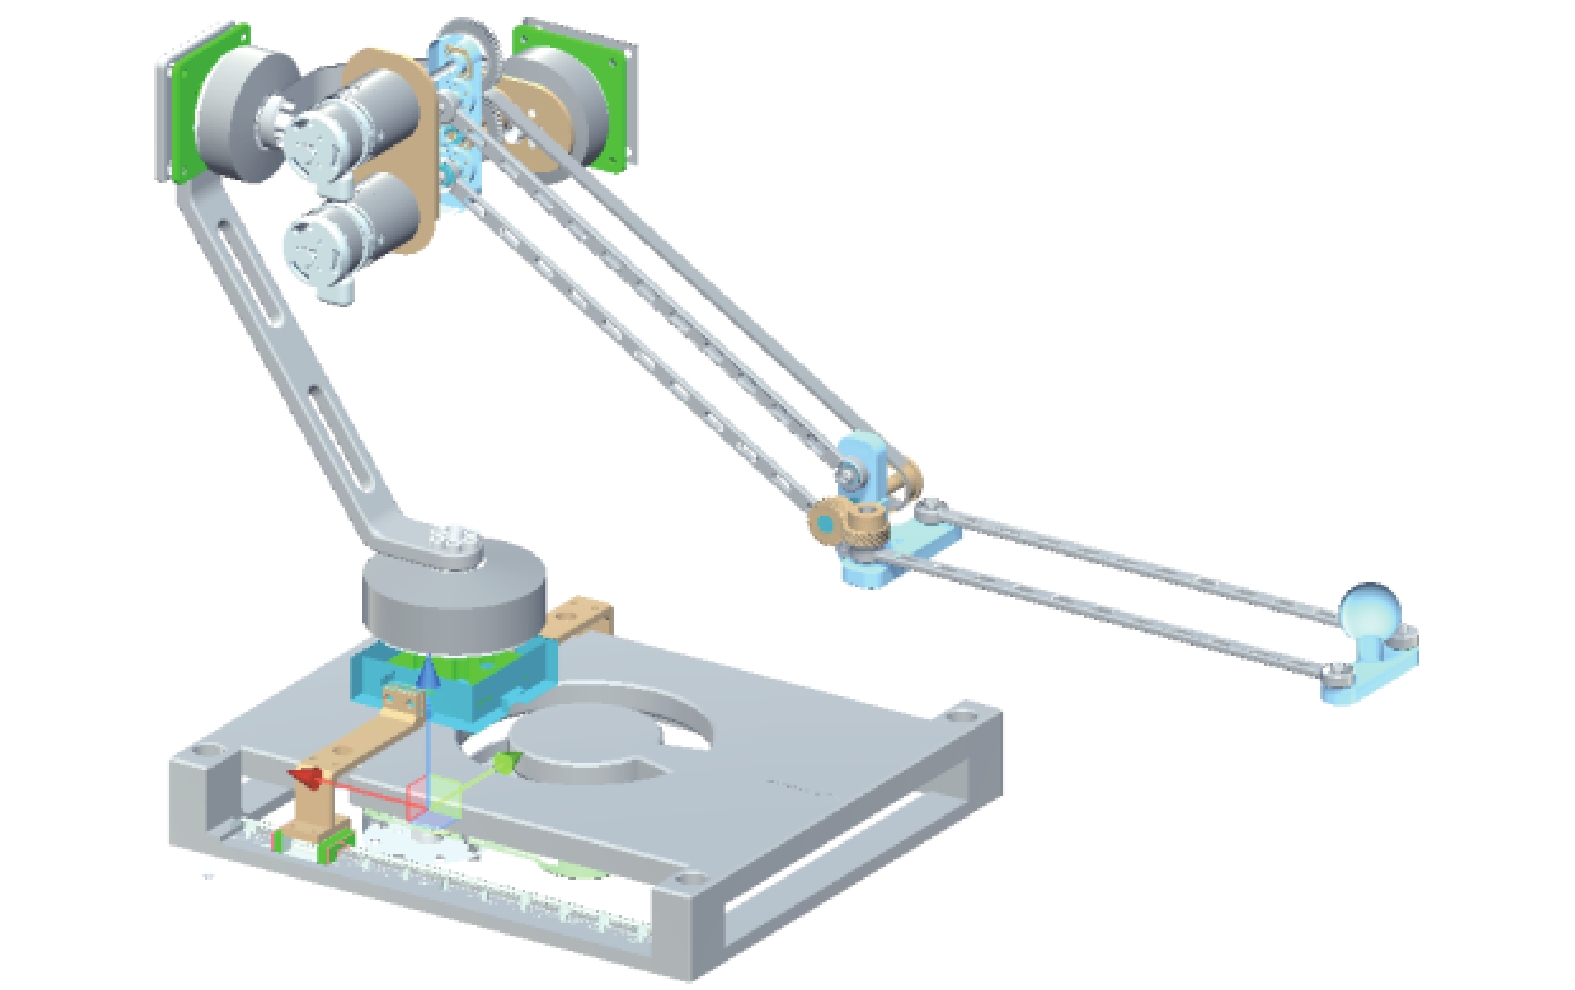
图3
第1关节结构设计示意图"
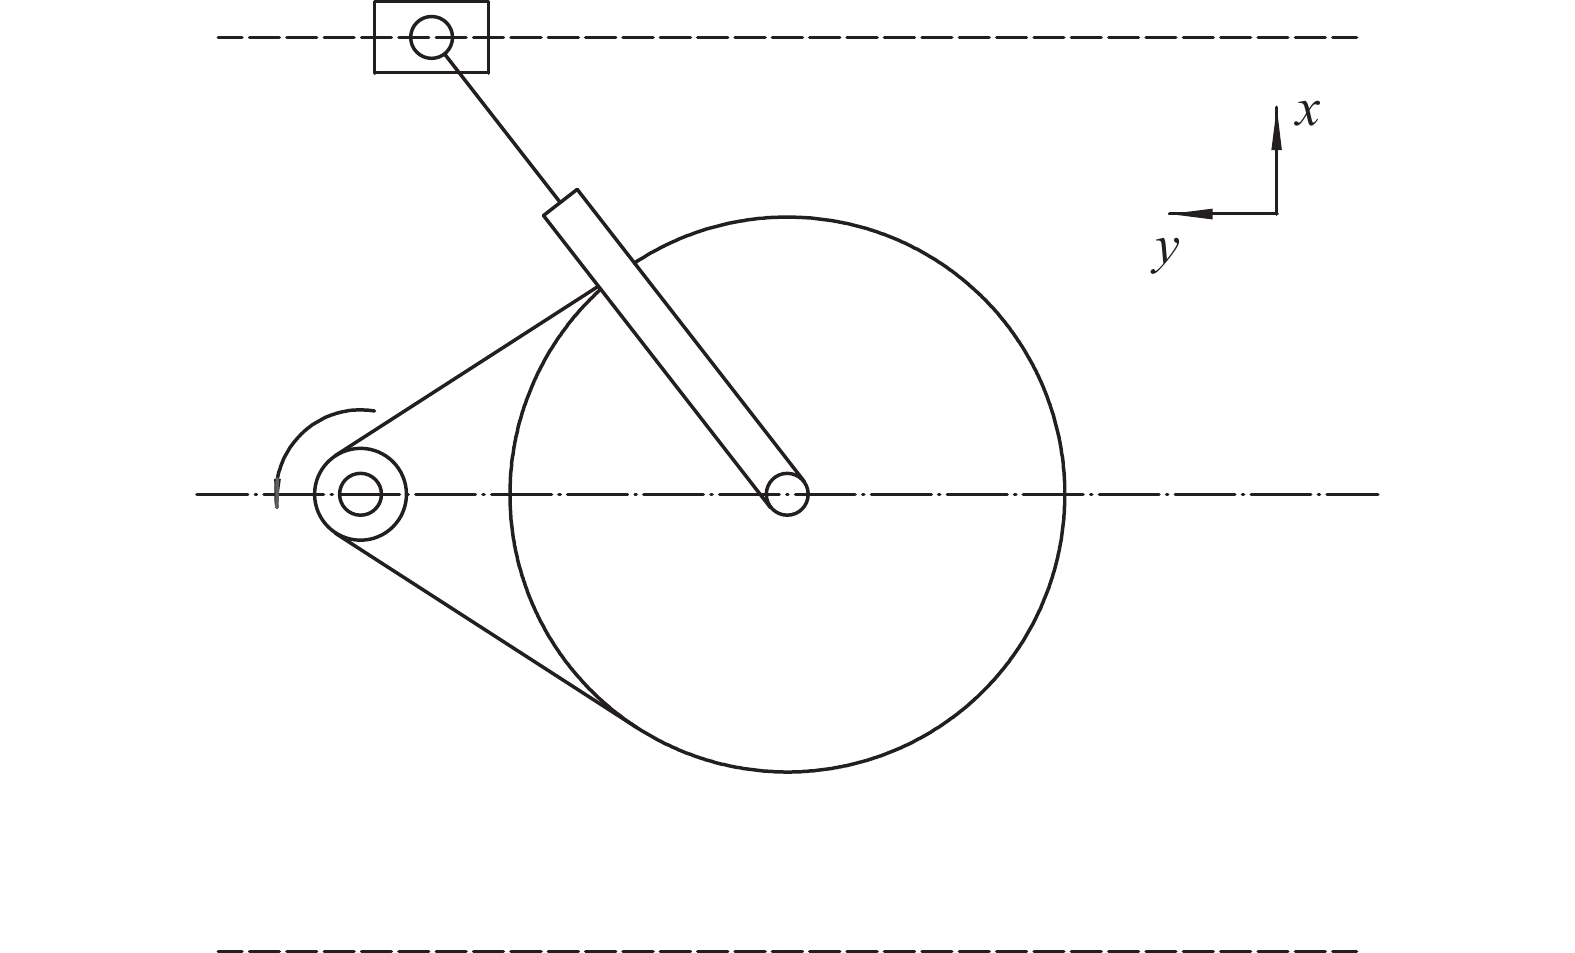
图4
第1关节三维模型"
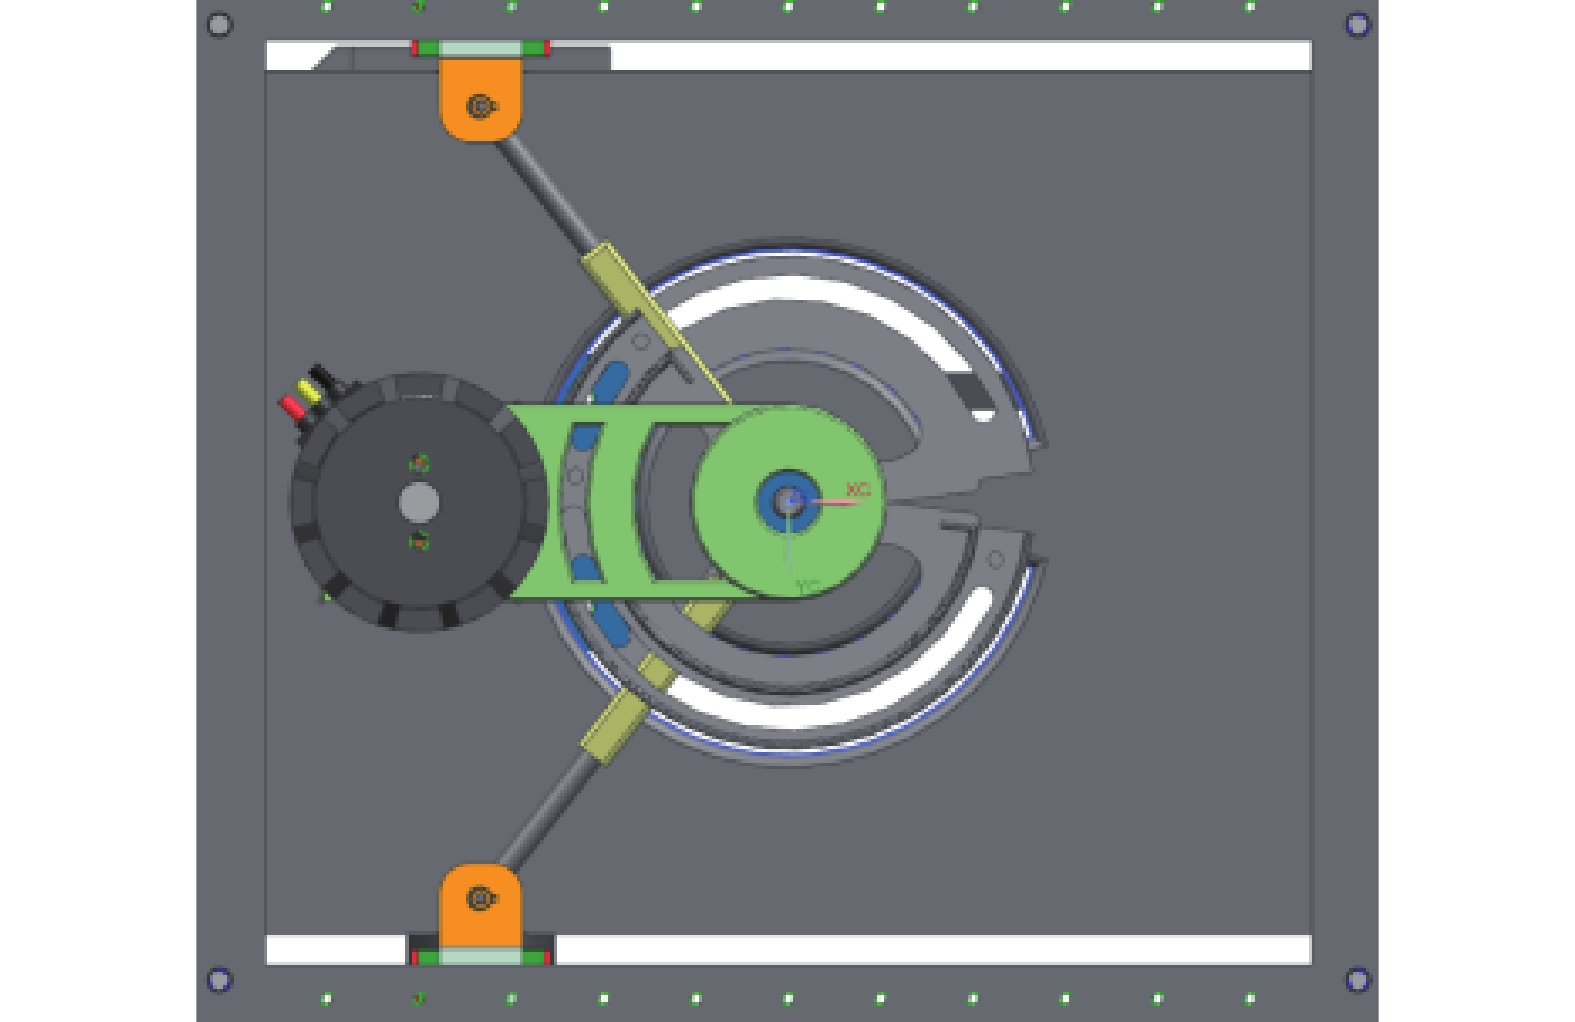
图5
第5关节结构设计示意图"
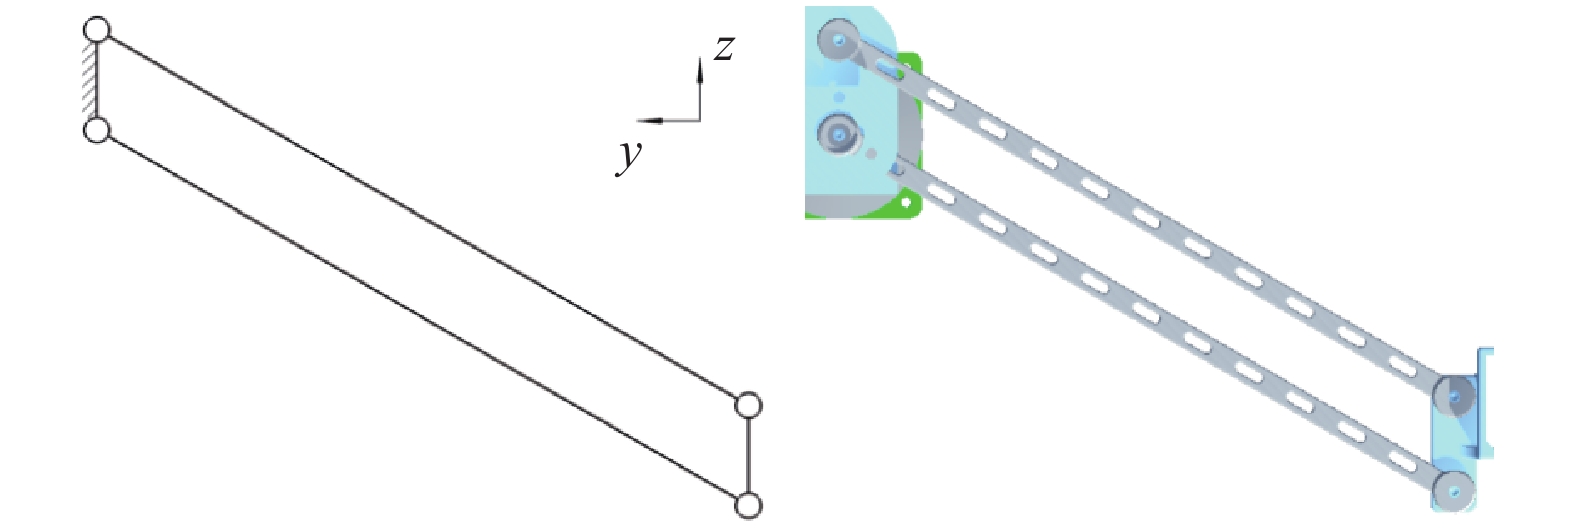
图6
姿态机构设计示意图"
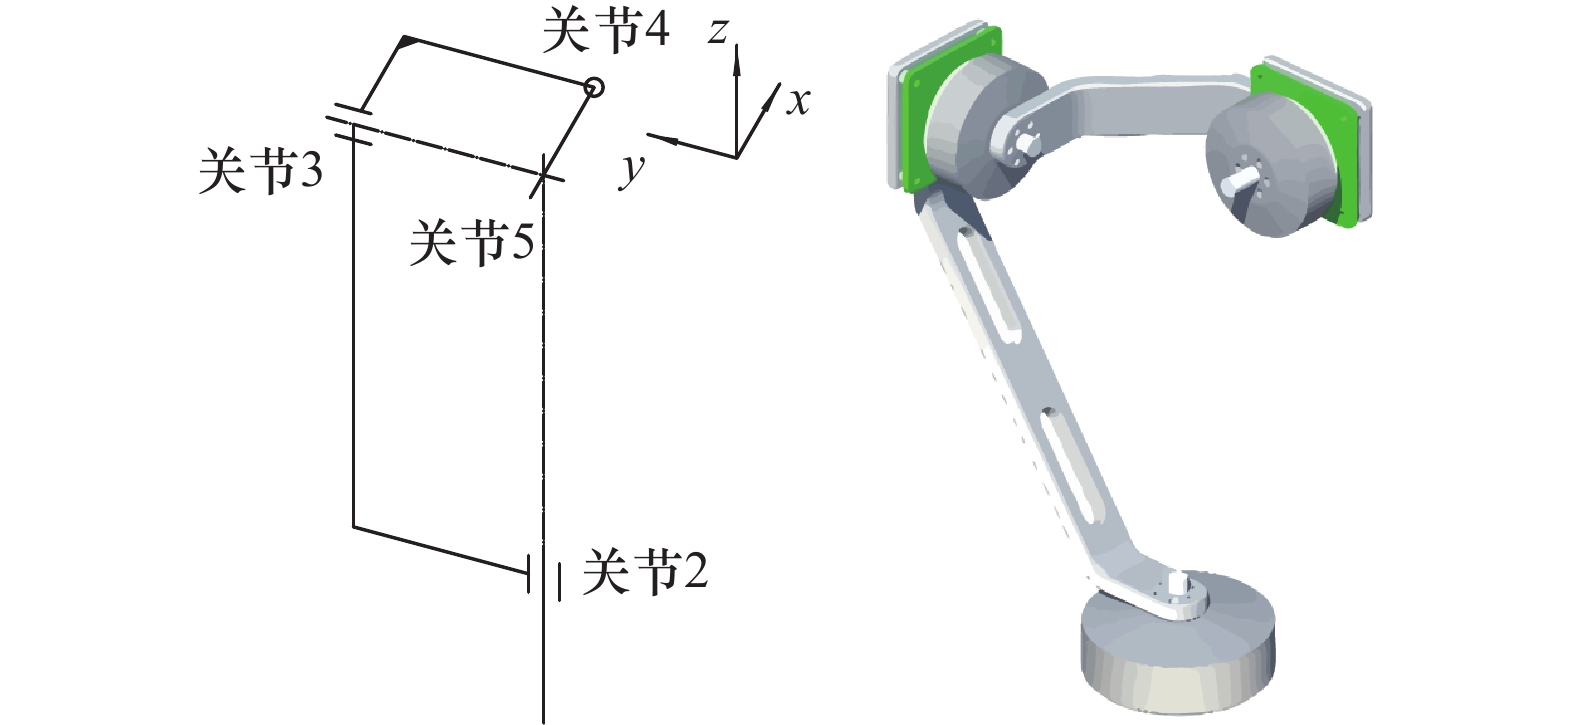
图7
采用MDH方法建立部分坐标系结果"
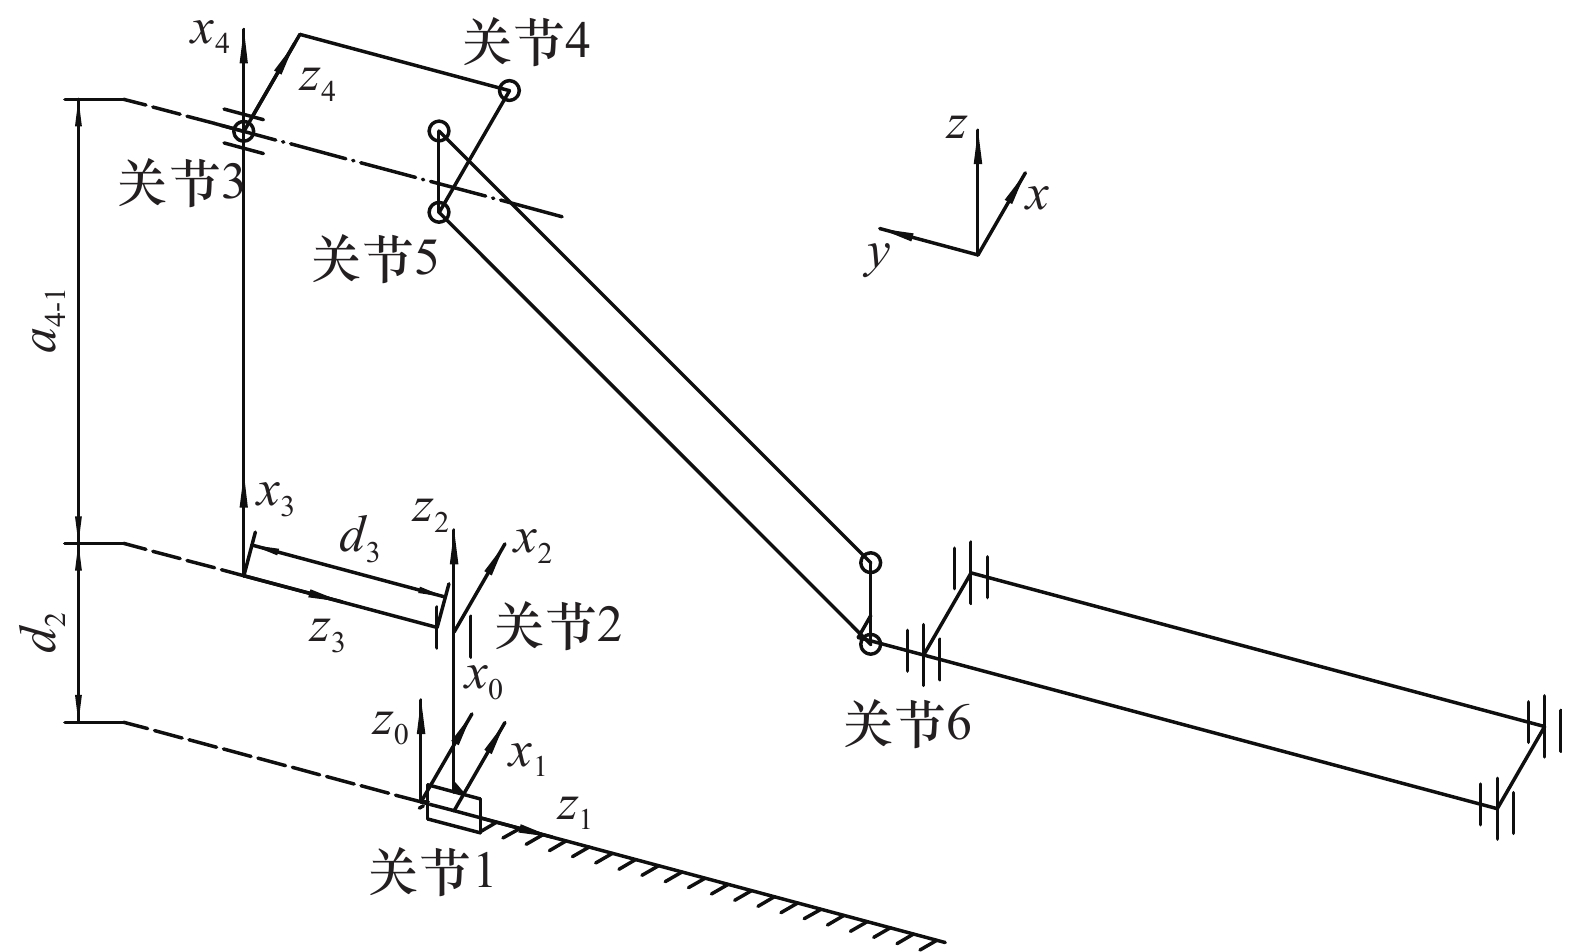
图8
对第2、3关节进行移轴处理"
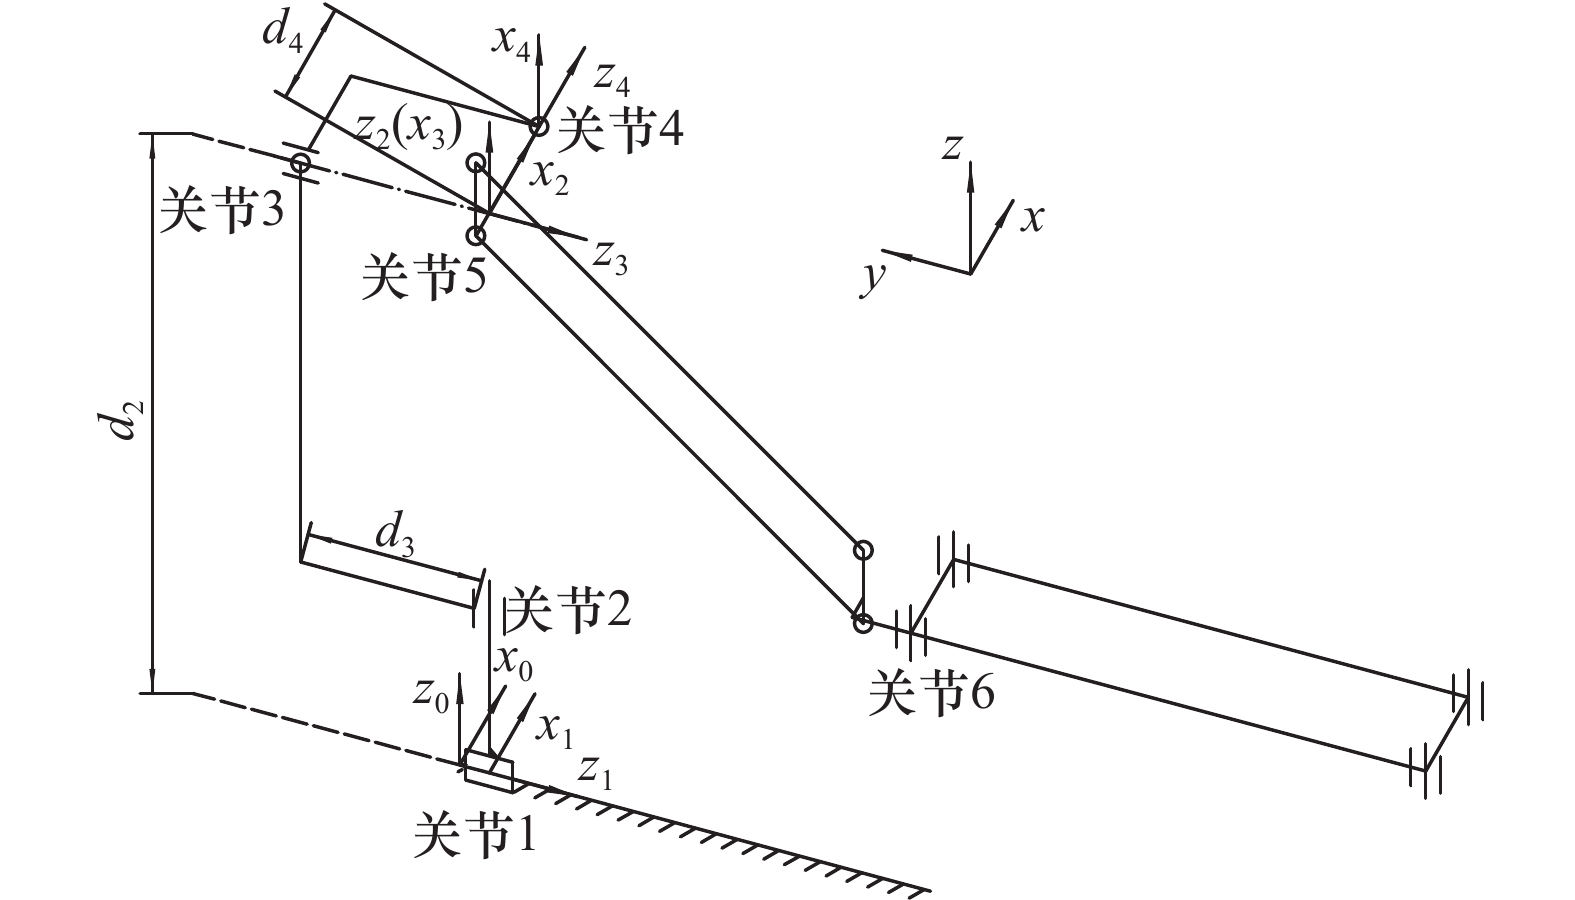
图9
基于MDH的第4~6关节建系结果"
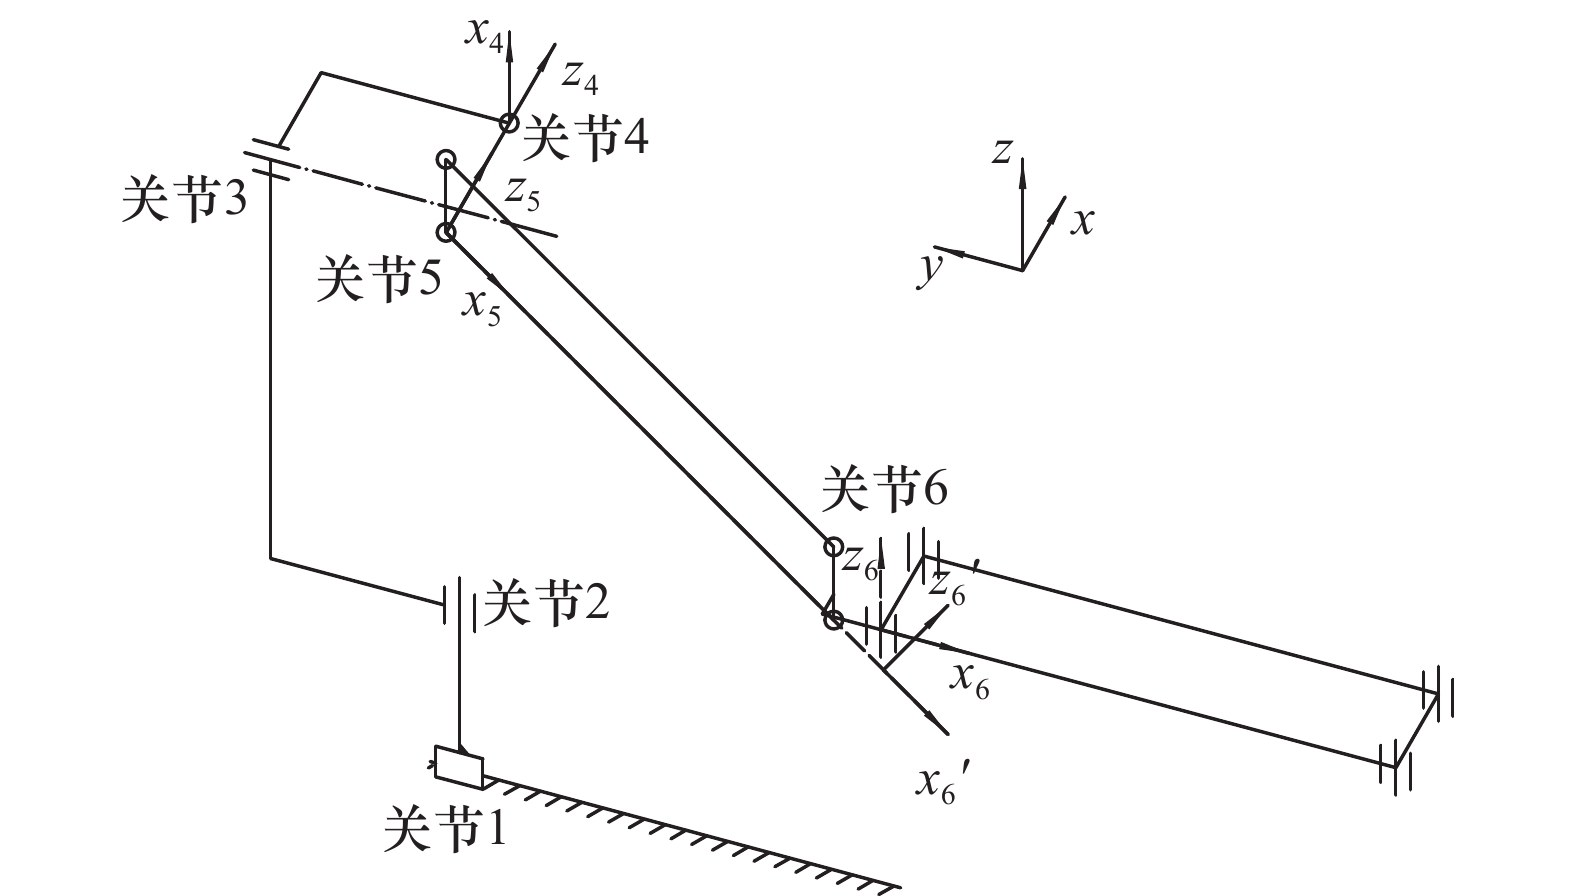
图10
在第5、6关节之间增加虚拟关节"
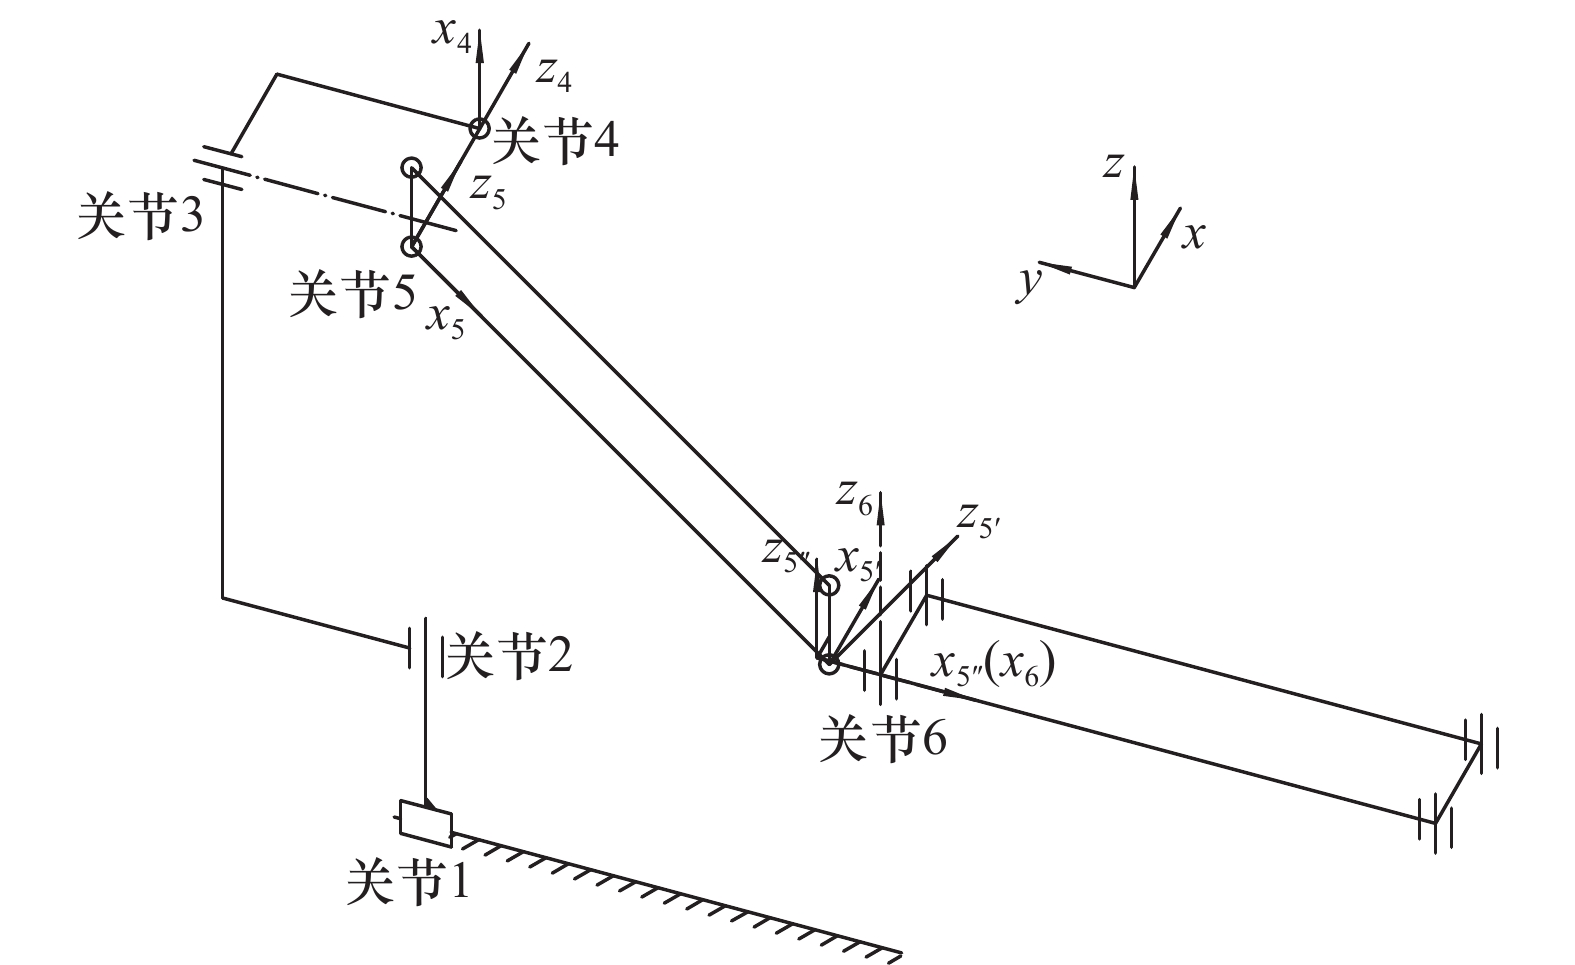
图11
手控器的机构运动学简图"
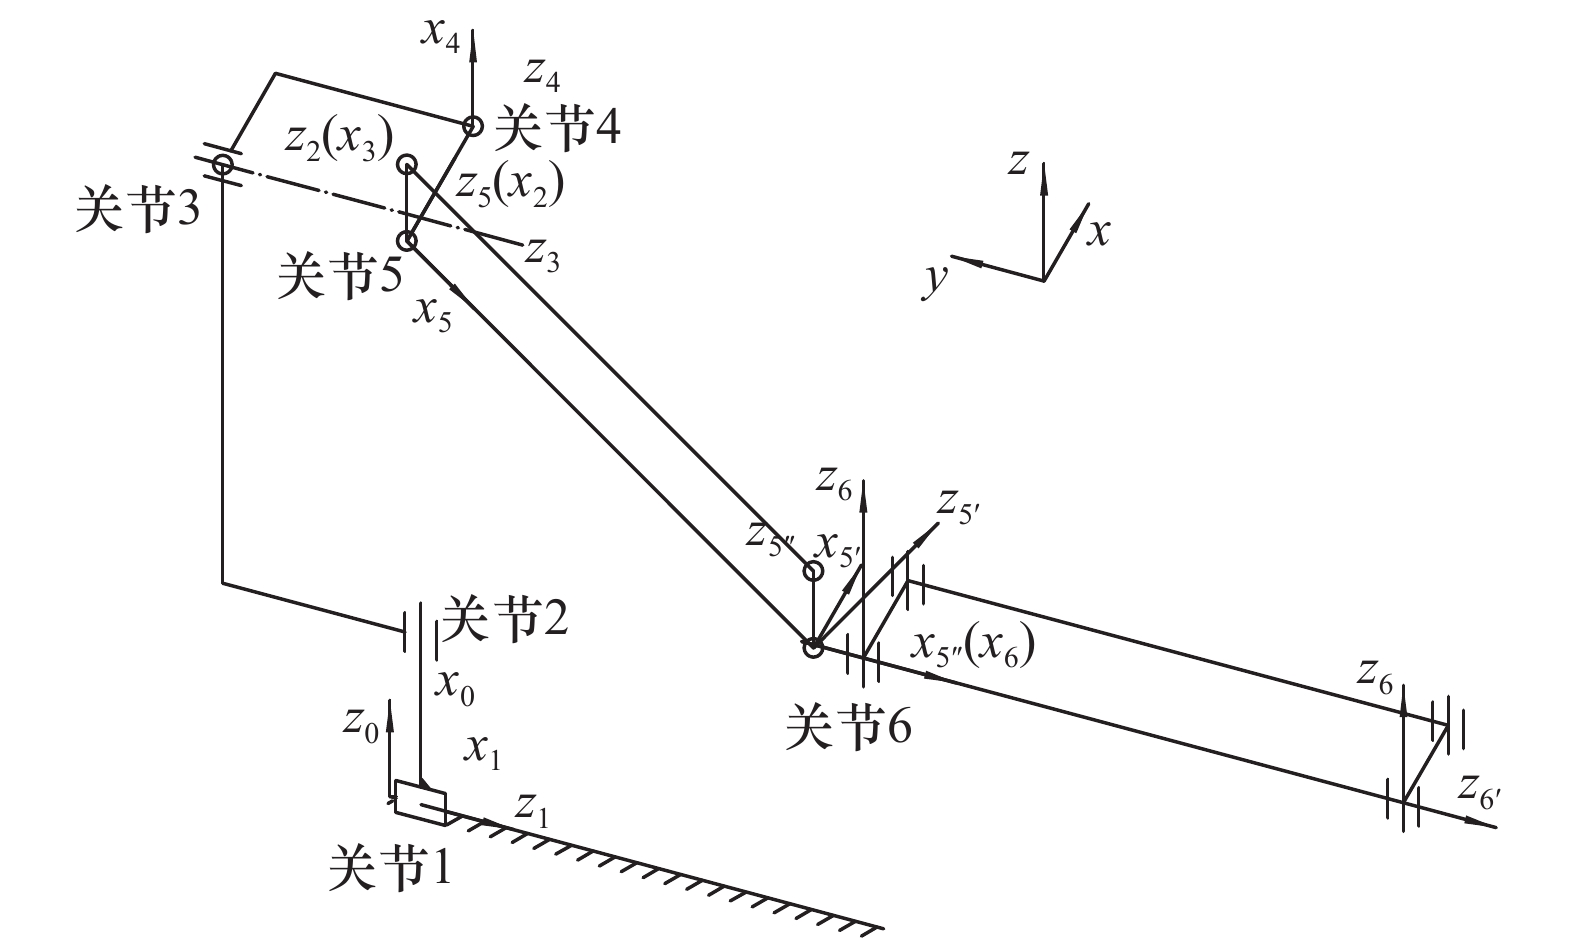
表1
D-H参数"
| i | 关节变量 范围/(°) | ||||
| 1 | 0 | 90 | d1 | 0 | [0, 160] |
| 2 | 0 | −90 | 184.47 | θ2 | [−30, 30] |
| 3 | 0 | 90 | 0 | θ3 | [−30, 210] |
| 4 | 0 | 90 | 33 | θ4 | [0, 90] |
| 5 | 0 | 0 | −41.5 | θ5 | [−90,0] |
| 5’ | 180 | 90 | 0 | 90 | — |
| 5’’ | −7.5 | −(θ5−90) | 15.5 | −90 | — |
| 6 | 20 | 0 | 0 | θ6 | [−45,45] |
| 6’ | 180 | 0 | 0 | −θ6 | — |
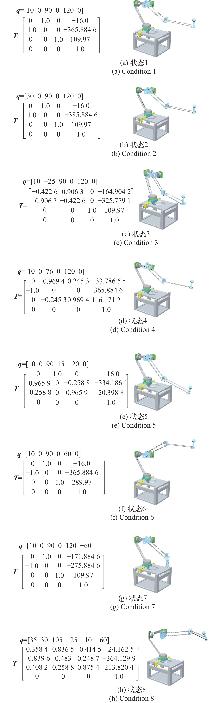
图12
手控器运动学方程可视化验证"
表2
手控器逆运动学方法验证"
| 序号 | 输入位姿矩阵 | 期望输出 | 实际输出(表中仅保留 三位小数) | 误差 |
| 1 | [30 0 90 0 120 0] | [30.0 −3.551×10⁻²⁰ 90.0 −6.157×10⁻¹¹ 120.0 1.464×10⁻¹⁶] | ||
| 2 | [10 −25 90 0 120 0] | [10.0 −25.0 90.0 −6.157×10⁻¹¹ 120.0 1.455×10⁻³] | ||
| 3 | [10 0 76 0 120 0] | [10.0 1.135×10⁻²⁷ 76.0 −6.157×10⁻¹¹ 120.0 −5.229×10⁻⁴] | ||
| 4 | [10 0 90 15 120 0] | [10.0 −9.626×10⁻²⁵ 90.0 15.0 120.0 7.995×10⁻²⁴] | ||
| 5 | [10 0 90 0 60 0] | [10.0 −3.29×10−40 90.0 −6.16×10⁻¹¹ 60.0 3.0×10−39] | ||
| 6 | [10 0 90 0 120 −60] | [10.0 −1.58×10−39 90.0 −6.16×10⁻¹¹ 120.0 −60.0] | ||
| 7 | [35 30 105 −25 110 −60] | [35.001 30.001 105.001 −25.0 109.999 −60.001] |
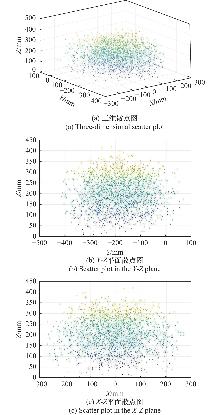
图13
手控器末端工作空间三维散点图"
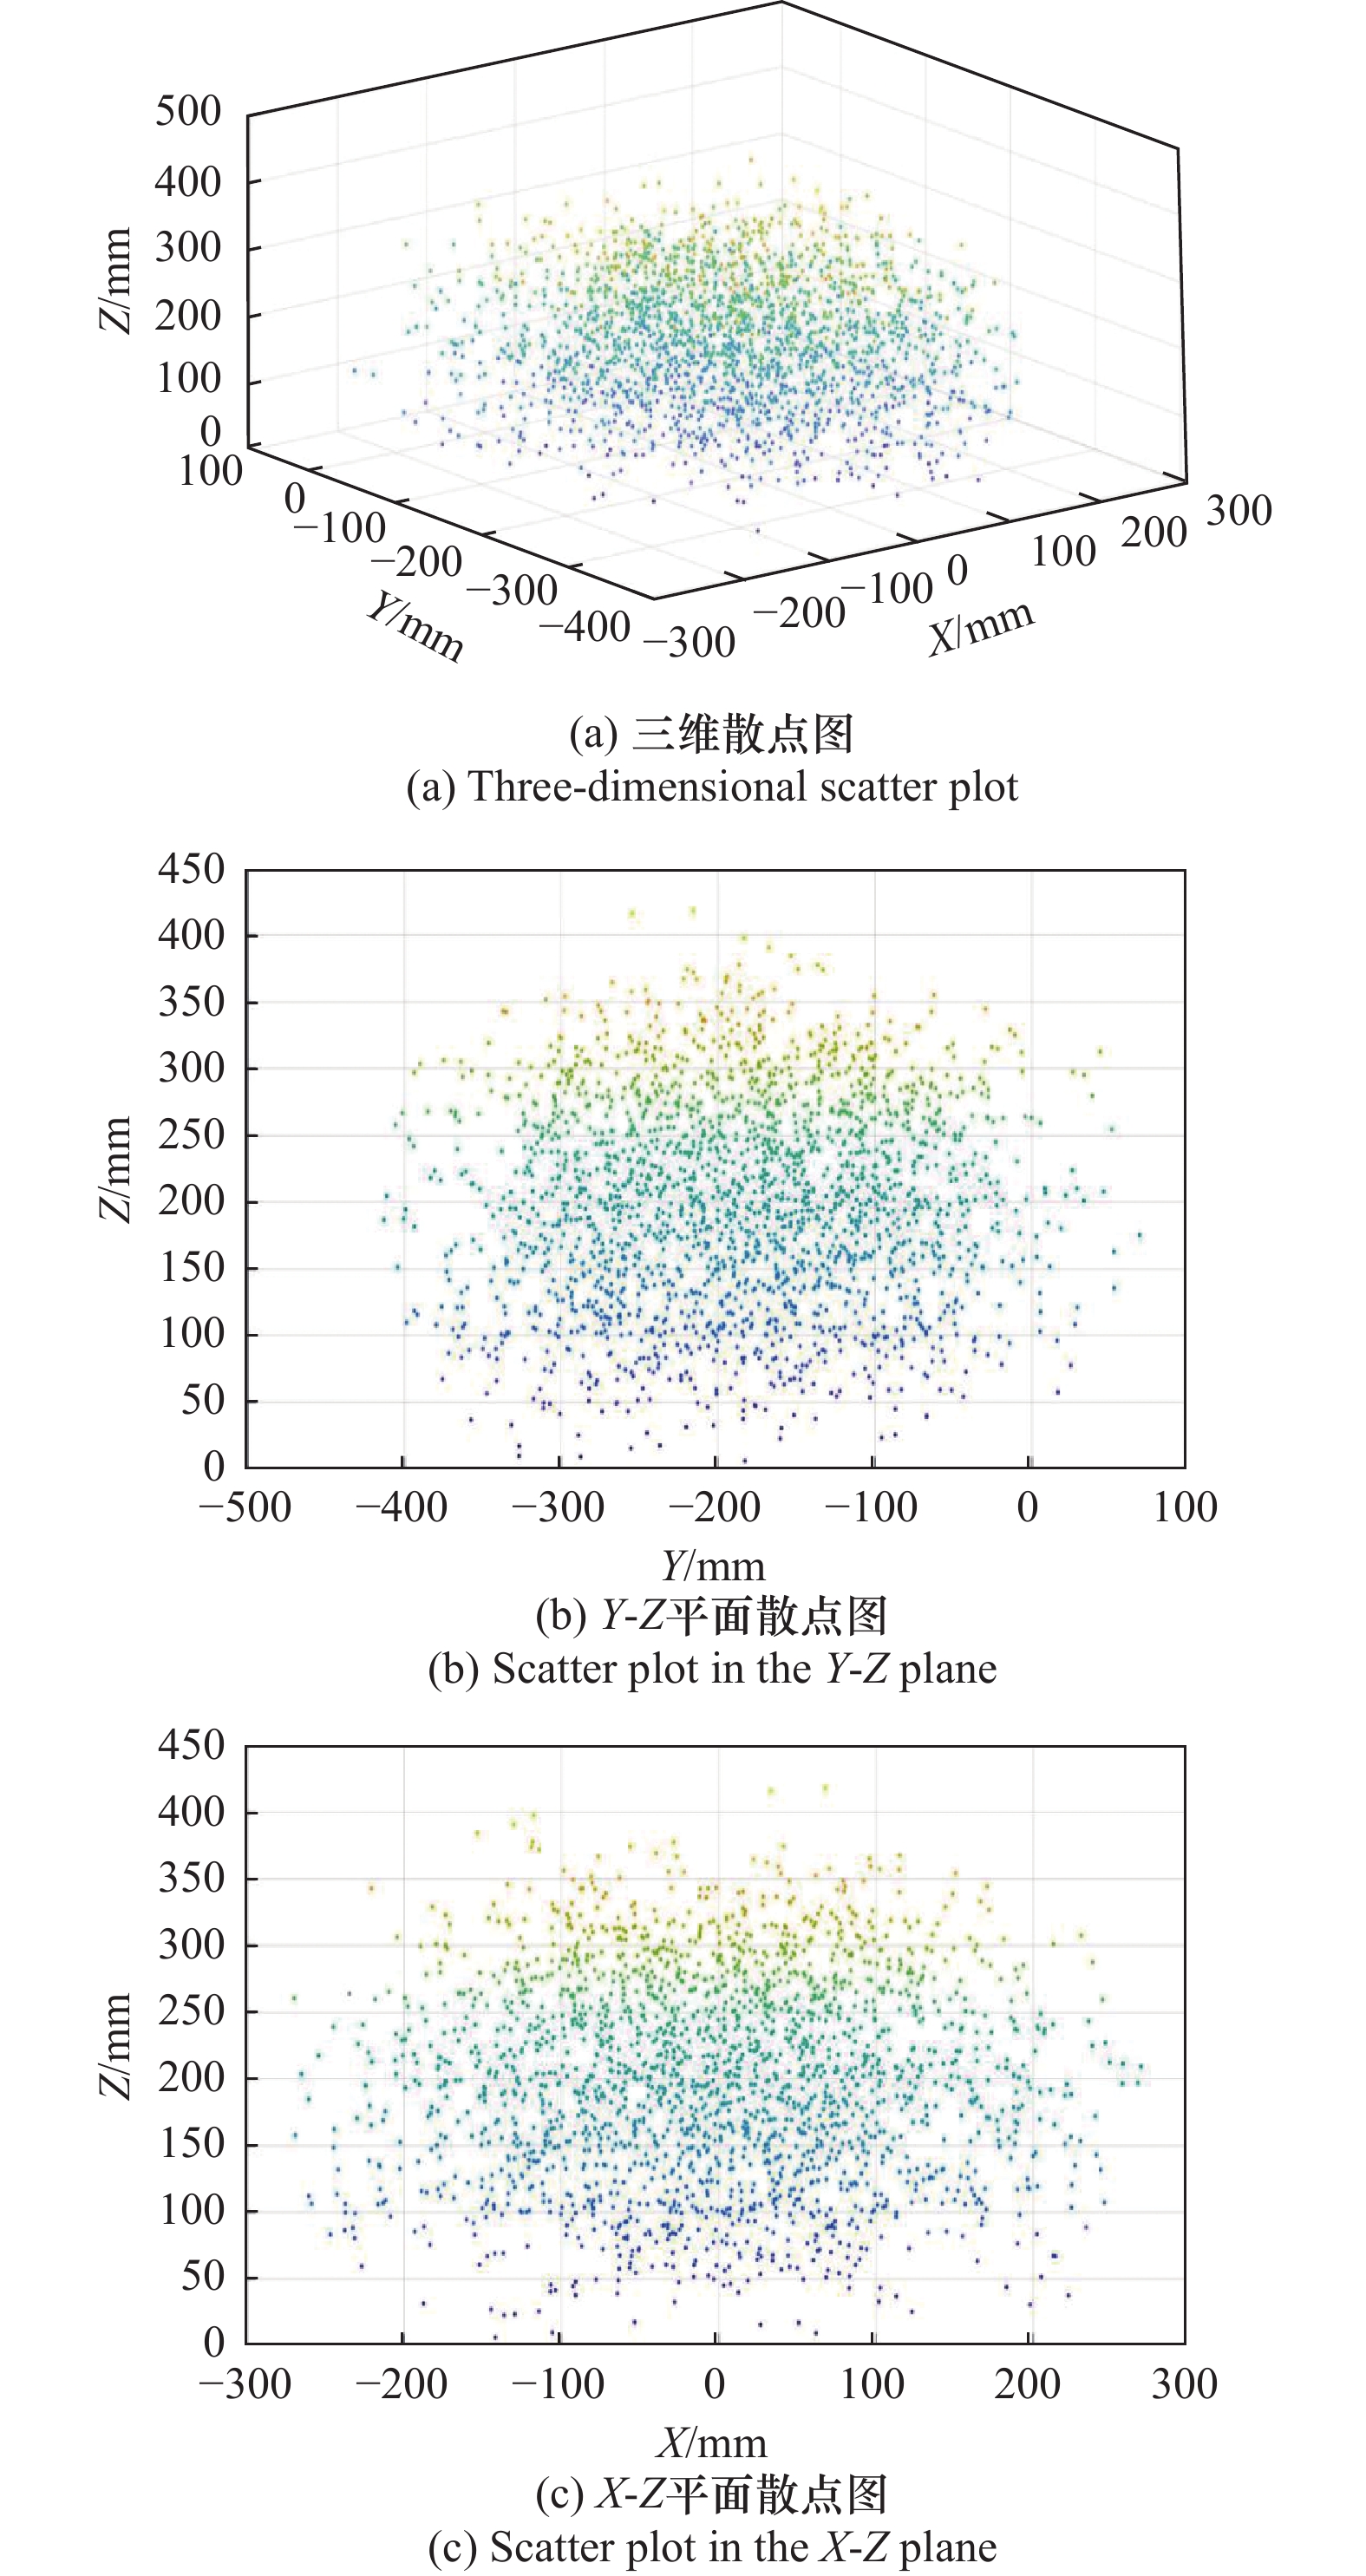
表3
同类手控器构型尺寸与工作空间综合对比"
| 设备规格 | Touch | omega.7 | 本手控器 |
| 构型描述 | 串联式 | 并联式 | 串并联 |
| 复合式 | |||
| 设备外廓尺寸/mm | 203 | 350 | 180 |
| 168 | 300 | 170 | |
| 280 | 400 | 335 | |
| 工作空间/mm | 431 | 550 | |
| 348 | 500 | ||
| 165 | 110 | 400 | |
| 工作空间体积/cm3 | |||
| 工作空间体积/设备体积 |
图14
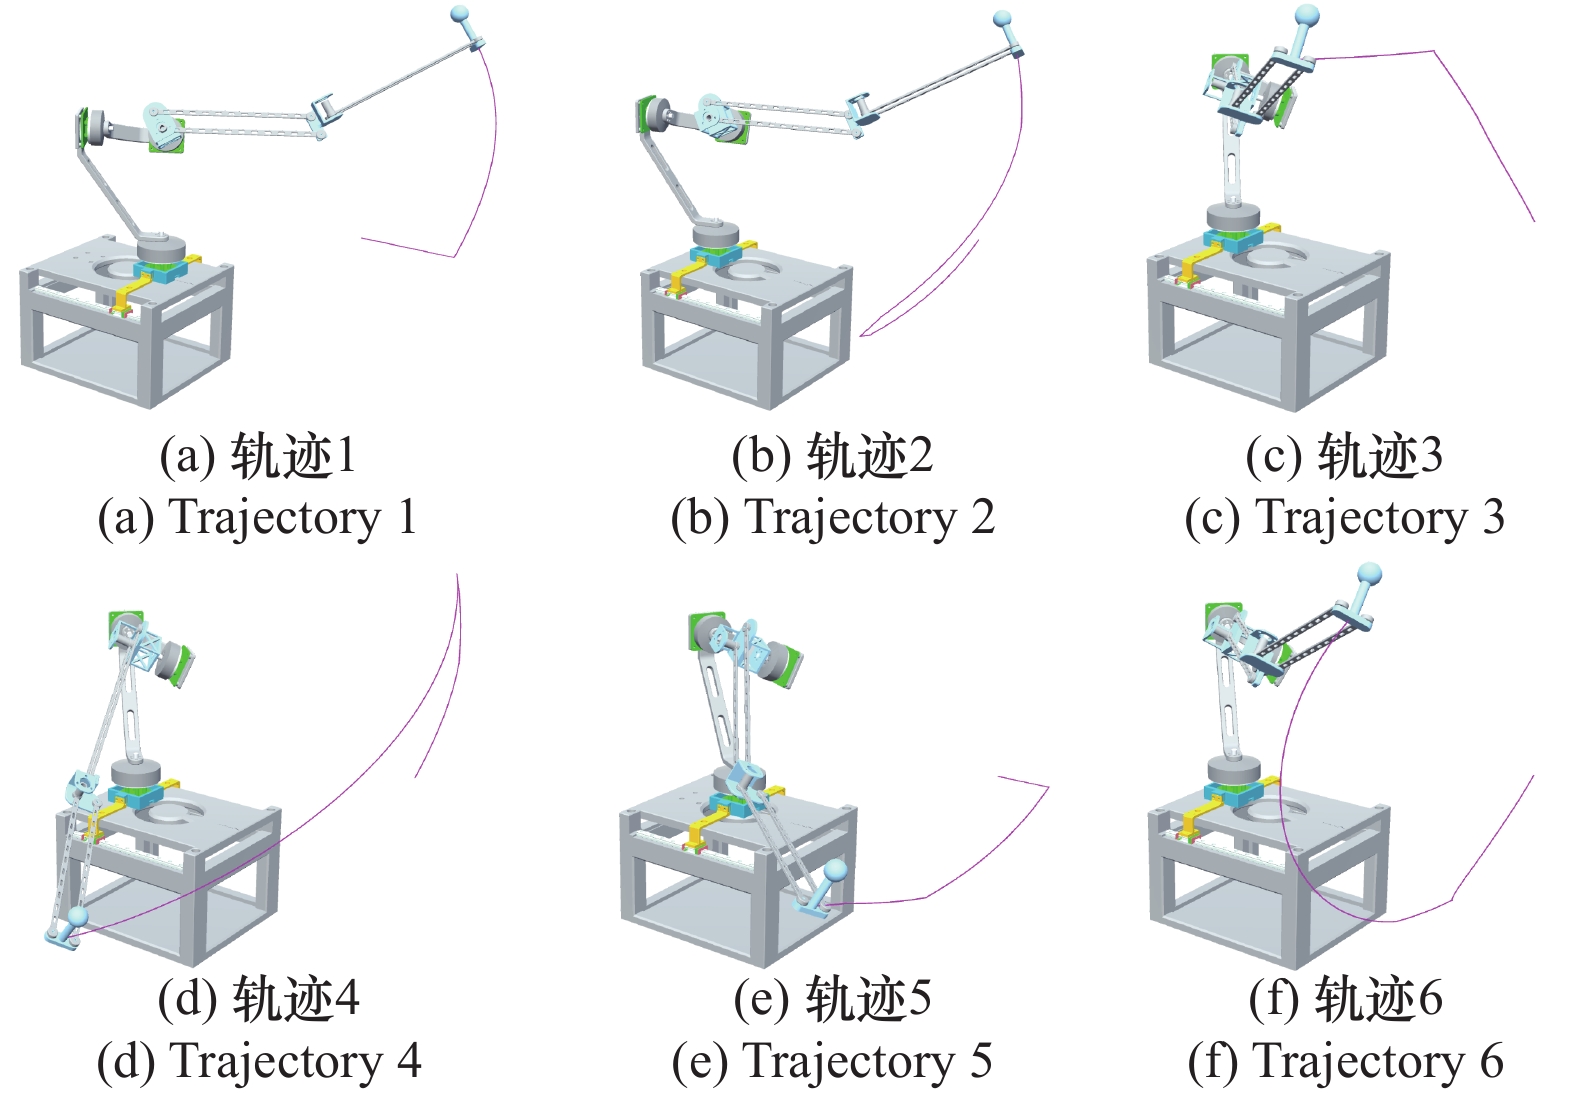
手控器虚拟模型可视化验证场景"
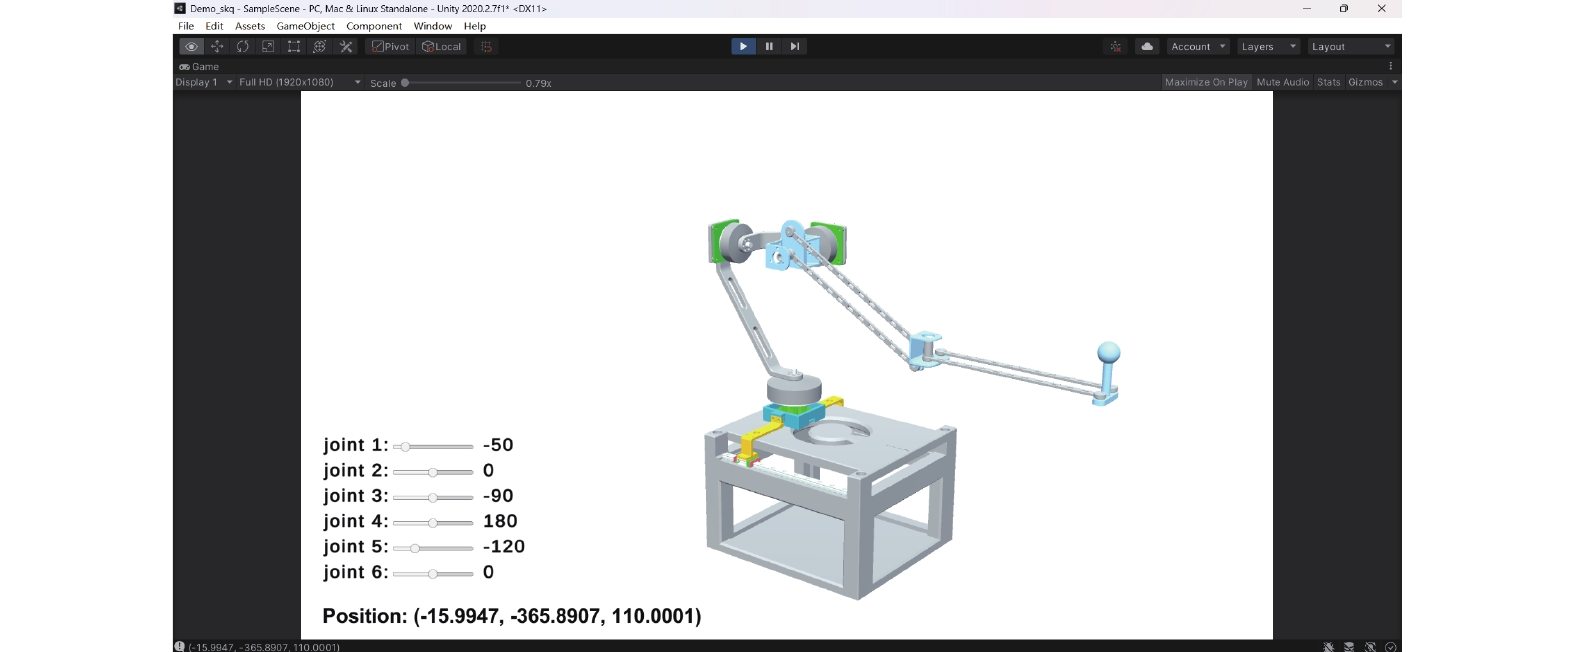
图15
手控器正向运动学可视化验证"
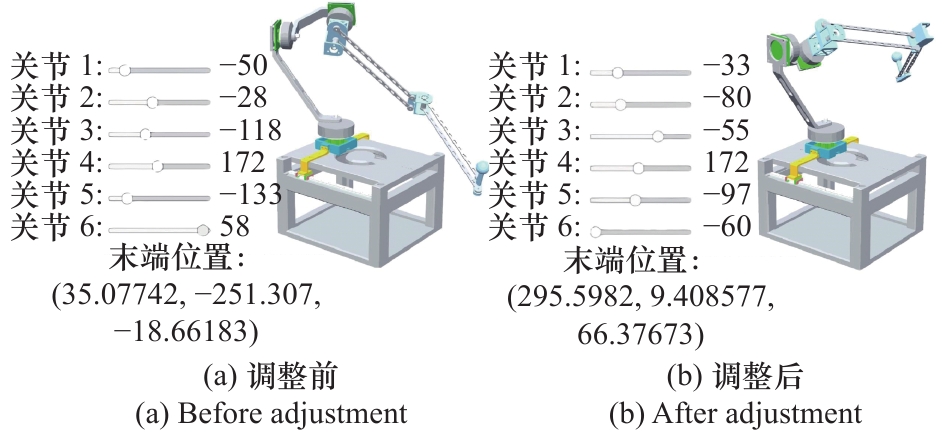
图16
手控器逆向运动学可视化验证"
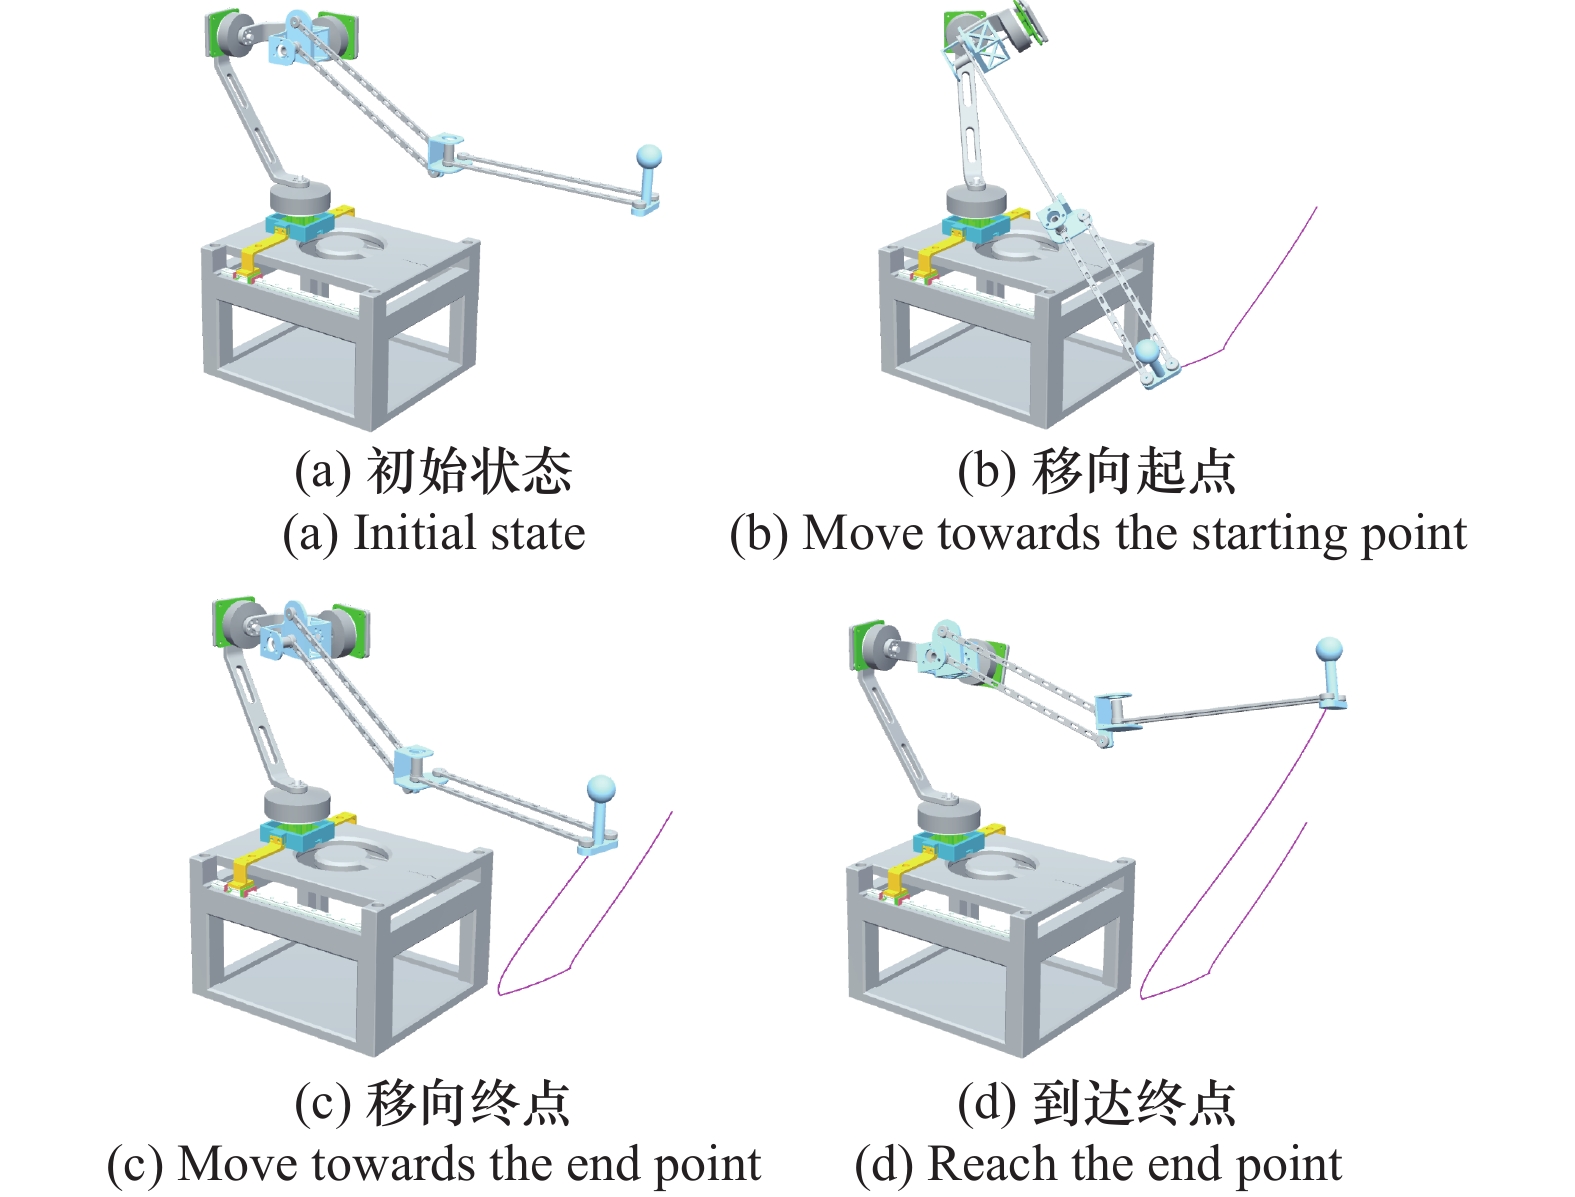
图17
其他逆运动学验证结果"
| 1 | 曾欣. 新型力反馈手控器的设计及应用[D]. 南京: 东南大学, 2020. |
| 2 |
周龙江, 宋爱国, 曾庆军, 等. 遥操作机器人手控器的研究进展[J]. 机器人技术与应用, 2002 (4): 11.
doi: 10.3969/j.issn.1004-6437.2002.04.005 |
| 3 | Diftler M A, Permenter F A, Hargrave B K, et al. Robonaut 2 – the first humanoid robot in space[C]//IEEE International Conference on Robotics and Automation, 2011: 2178. |
| 4 | William B, Zachary K, Mark M, et al. Robonaut 2 and You: specifying and executing complex operations[C]//IEEE Workshop on Advanced Robotics and its Social Impacts, 2017: 83. |
| 5 |
Moustris G, Tzafestas C. Modeling, simulation and control of the double delta surgical robot[J]. Machines, 2024, 12 (9): 620.
doi: 10.3390/machines12090620 |
| 6 |
Papadopoulos K, Koustriava E, Georgoula E, et al. 3D haptic texture discrimination in individuals with and without visual impairments using a force feedback device[J]. Universal Access in the Information Society, 2025, 24, 2433.
doi: 10.1007/s10209-025-01202-w |
| 7 |
Valenzuela-domínguez F A, Munguía‐Martínez L F, Meléndez‐Tiznado S, et al. Design of a two-degrees-of-freedom robotic arm for monitoring applications for teaching robotics and artificial intelligence technology[J]. Computer Applications in Engineering Education, 2024, 32 (6): e22786.
doi: 10.1002/cae.22786 |
| 8 |
Vu M H, Na U J. A new 6-DOF haptic device for teleoperation of 6-DOF serial robots[J]. IEEE Trans. on Instrumentation and Measurement, 2011, 60 (11): 3510.
doi: 10.1109/TIM.2011.2164285 |
| 9 |
Wang Z, Li X L, Shi D, et al. Haptic device for physiologically adaptive handle operation[J]. International Journal of Mechanical Sciences, 2025, 286, 109893.
doi: 10.1016/j.ijmecsci.2024.109893 |
| 10 |
Soltanov S, Roberts R. Design of a novel bio-inspired three degrees of freedom (3DOF) spherical robotic manipulator and its application in human–robot interactions[J]. Robotics, 2025, 14 (2): 8.
doi: 10.3390/robotics14020008 |
| 11 | Lee J, Yu B, Yu S K, et al. Design and control of a 5-DOF manipulator for medium energy ion scattering measuring a 300 mm wafer[J]. International Journal of Control, Automation and Systems, 2025, 23(2): 467. |
| 12 | 于仕泽, 王周义, 戴振东, 等. 一种面向航天需求的仿生柔性机械臂的设计[J]. 机械制造与自动化, 2020, 49 (1): 134. |
| 13 |
崔建伟, 黄惟一, 宋爱国. HC01型通用远程遥操作机器人手控器设计[J]. 机械设计, 2004, 21 (1): 15.
doi: 10.3969/j.issn.1001-2354.2004.01.006 |
| 14 |
Von A D, Fischer C, Torlakcik H, et al. Simultaneous localization and actuation using electromagnetic navigation systems[J]. IEEE Trans. on Robotics, 2023, 40, 1292.
doi: 10.1109/tro.2023.3340324/mm1 |
| 15 |
Gong Y, Mat H H, Erol E, et al. AiroTouch: enhancing telerobotic assembly through naturalistic haptic feedback of tool vibrations[J]. Frontiers in Robotics and AI, 2024, 11, 1355205.
doi: 10.3389/frobt.2024.1355205 |
| 16 |
Hu P X, Huang X, Wang Y L, et al. A novel hand teleoperation method with force and vibrotactile feedback based on dynamic compliant primitives controller[J]. Biomimetics, 2025, 10 (4): 194.
doi: 10.3390/biomimetics10040194 |
| 17 | 安宏雷. 双边遥操作力反馈手控器研制[D]. 长沙: 国防科技大学, 2008. |
| 18 | Siciliano B, Sciavicco L, Villani L, et al. Robotics: modelling, planning and control[M]. London: Springer, 2009. |
| 19 |
Liu X J, Wang J. Some new parallel mechanisms containing the planar four-bar parallelogram[J]. The International Journal of Robotics Research, 2003, 22 (9): 717.
doi: 10.1177/02783649030229003 |
| 20 |
朱小蓉, 赵磊, 沈惠平. 3T1R 解耦并联机构动力学与惯量耦合特性分析[J]. 农业机械学报, 2023, 54 (9): 448.
doi: 10.6041/j.issn.1000-1298.2023.09.045 |
| 21 |
Fang X W. Design of optical pod vibration isolation system based on stewart platform[J]. Noise and Vibration Control, 2022, 42 (6): 279.
doi: 10.1088/1742-6596/2746/1/012008 |
| 22 | Hazem Z B, Ince R, Dilibal S. Joint control implementation of 4-DOF robotic arm using robot operating system[C]//International Conference on Theoretical and Applied Computer Science and Engineering, 2022: 72. |
| 23 |
Wang X H, Sun S, Zhang P L, et al. Model-based kinematic and non-kinematic calibration of a 7R 6-DOF robot with non-spherical wrist[J]. Mechanism and Machine Theory, 2022, 178, 105086.
doi: 10.1016/j.mechmachtheory.2022.105086 |
| 24 | 郭发勇, 梅涛, 赵江海. D-H 法建立连杆坐标系存在的问题及改进[J]. 中国机械工程, 2014, 25 (20): 2710. |
| 25 | 杨逸波, 汪满新. R(RPS&RP)&2-UPS并联机构位置精度可靠性建模与分析[J]. 机械工程学报, 2023, 59 (15): 62. |
| 26 |
Li H M, Liu C K, Yang Y C, et al. Simultaneous compensation of geometric and compliance errors for robotics with consideration of variable payload effects[J]. Mechatronics, 2024, 102, 103228.
doi: 10.1016/j.mechatronics.2024.103228 |
| 27 |
Fu Z, Dai J S, Yang K, et al. Analysis of unified error model and simulated parameters calibration for robotic machining based on Lie theory[J]. Robotics and Computer-Integrated Manufacturing, 2020, 61, 101855.
doi: 10.1016/j.rcim.2019.101855 |
| 28 |
Dumlu A, Erenturk K. Modeling and trajectory tracking control of 6-DOF RSS type parallel manipulator[J]. Robotica, 2014, 32 (4): 643.
doi: 10.1017/S0263574713000908 |
| 29 |
Kouabon A G J, Melingui A, Ahanda J J B M, et al. A learning framework to inverse kinematics of high DOF redundant manipulators[J]. Mechanism and Machine Theory, 2020, 153, 103978.
doi: 10.1016/j.mechmachtheory.2020.103978 |
| 30 | 张栩曼, 张中哲, 王燕波, 等. 基于空间六自由度机械臂的逆运动学数值解法[J]. 导弹与航天运载技术, 2016, 2 (3): 81. |
| 31 | Chaudhury A N, Ghosal A. Determination of workspace volume of parallel manipulators using monte carlo method[C]//7th International Workshop on Computational Kinematics, 2017: 323. |
| [1] | 李航, 侯彦朋, 丑武胜, 孟令达. 面向核事故应急处置的遥操作系统设计与实验研究[J]. 系统工程与电子技术, 2024, 46(5): 1607-1618. |
| [2] | 师明, 高宇辉, 张弓. 基于HTN的巡视器动态规划方法[J]. 系统工程与电子技术, 2024, 46(2): 631-639. |
| [3] | 张浩杰, 梁荣敏, 张玉东. 基于人在回路的地面无人平台仿真系统设计[J]. 系统工程与电子技术, 2022, 44(2): 538-545. |
| [4] | 徐志浩, 周召发, 常振军, 徐梓皓. 载体运动学辅助的双轴旋转调制惯性导航算法[J]. 系统工程与电子技术, 2020, 42(9): 2066-2070. |
| [5] | 刘正雄, 司继康, 陈刚, 黄攀峰. 面向遥操作手眼协调的虚拟仿真交互控制方法[J]. 系统工程与电子技术, 2020, 42(5): 1146-1151. |
| [6] | 刘正雄, 黄攀峰 台健生. 空间遥操作预测仿真快速图形碰撞检测算法[J]. 系统工程与电子技术, 2016, 38(7): 1690-1696. |
| [7] | 魏武, 袁银龙, 王新梅. 基于影响系数原理的六足机器人运动状态分析[J]. 系统工程与电子技术, 2016, 38(2): 375-381. |
| [8] | 赵琳, 苏中华, 郝勇, 吴限德. 基于对偶数和改进EKF的敏捷卫星姿态确定算法[J]. 系统工程与电子技术, 2013, 35(12): 2552-2558. |
| [9] | 瞿师, 吴玲达, 魏迎梅, 李松, 冯晓萌. 基于统计学习的逆向运动学实现方法[J]. Journal of Systems Engineering and Electronics, 2011, 33(8): 1891-1895. |
| [10] | 于振中, 闫继宏, 惠晶, 马勇虎, 赵杰. 多自由度变时延遥操作系统控制的波预测法[J]. Journal of Systems Engineering and Electronics, 2011, 33(11): 2474-2479. |
| 阅读次数 | ||||||
|
全文 |
|
|||||
|
摘要 |
|
|||||
