系统工程与电子技术 ›› 2026, Vol. 48 ›› Issue (10): 3622-3633.doi: 10.12305/j.issn.1001-506X.2026.10.32
• 制导、导航与控制 • 上一篇
刘武君1, 赵慧珍1, 李龙跃1, 王攀荣1, 陈俊峰2
收稿日期:2025-07-21
出版日期:2026-10-25
发布日期:2026-09-30
通讯作者:
李龙跃
作者简介:刘武君(1997—),男,硕士研究生,主要研究方向为无人机航迹规划基金资助:Wujun Liu1, Huizhen Zhao1, Longyue Li1, Panrong Wang1, Junfeng Chen2
Received:2025-07-21
Online:2026-10-25
Published:2026-09-30
Contact:
Longyue Li
摘要:
针对复杂环境下人工势场法规划无人机航迹易陷入局部极小值的难题,提出一种智能链式改进人工势场无人机航迹规划方法。通过在航迹中设置利用蚁群算法智能生成的链式子目标点,避免陷入局部最优,解决局部极小值问题;但传统蚁群算法规划航迹转弯点多、收敛速度慢,通过构造多因素启发函数、优化信息素更新方法、设置自适应权重、设计航迹清洗策略,平滑航迹,加快收敛速度。针对人工势场法目标不可达问题,引入相对距离改进斥力函数,使目标可达。仿真结果表明,改进算法能在局部极小值点快速逃脱,实现复杂动态环境下的无人机航迹规划。
中图分类号:
刘武君, 赵慧珍, 李龙跃, 王攀荣, 陈俊峰. 基于智能链式改进人工势场的无人机航迹规划[J]. 系统工程与电子技术, 2026, 48(10): 3622-3633.
Wujun Liu, Huizhen Zhao, Longyue Li, Panrong Wang, Junfeng Chen. Unmanned aerial vehicle trajectory planning based on intelligent chain-based modified artificial potential field[J]. Systems Engineering and Electronics, 2026, 48(10): 3622-3633.
图1
IC-IAPF算法流程"
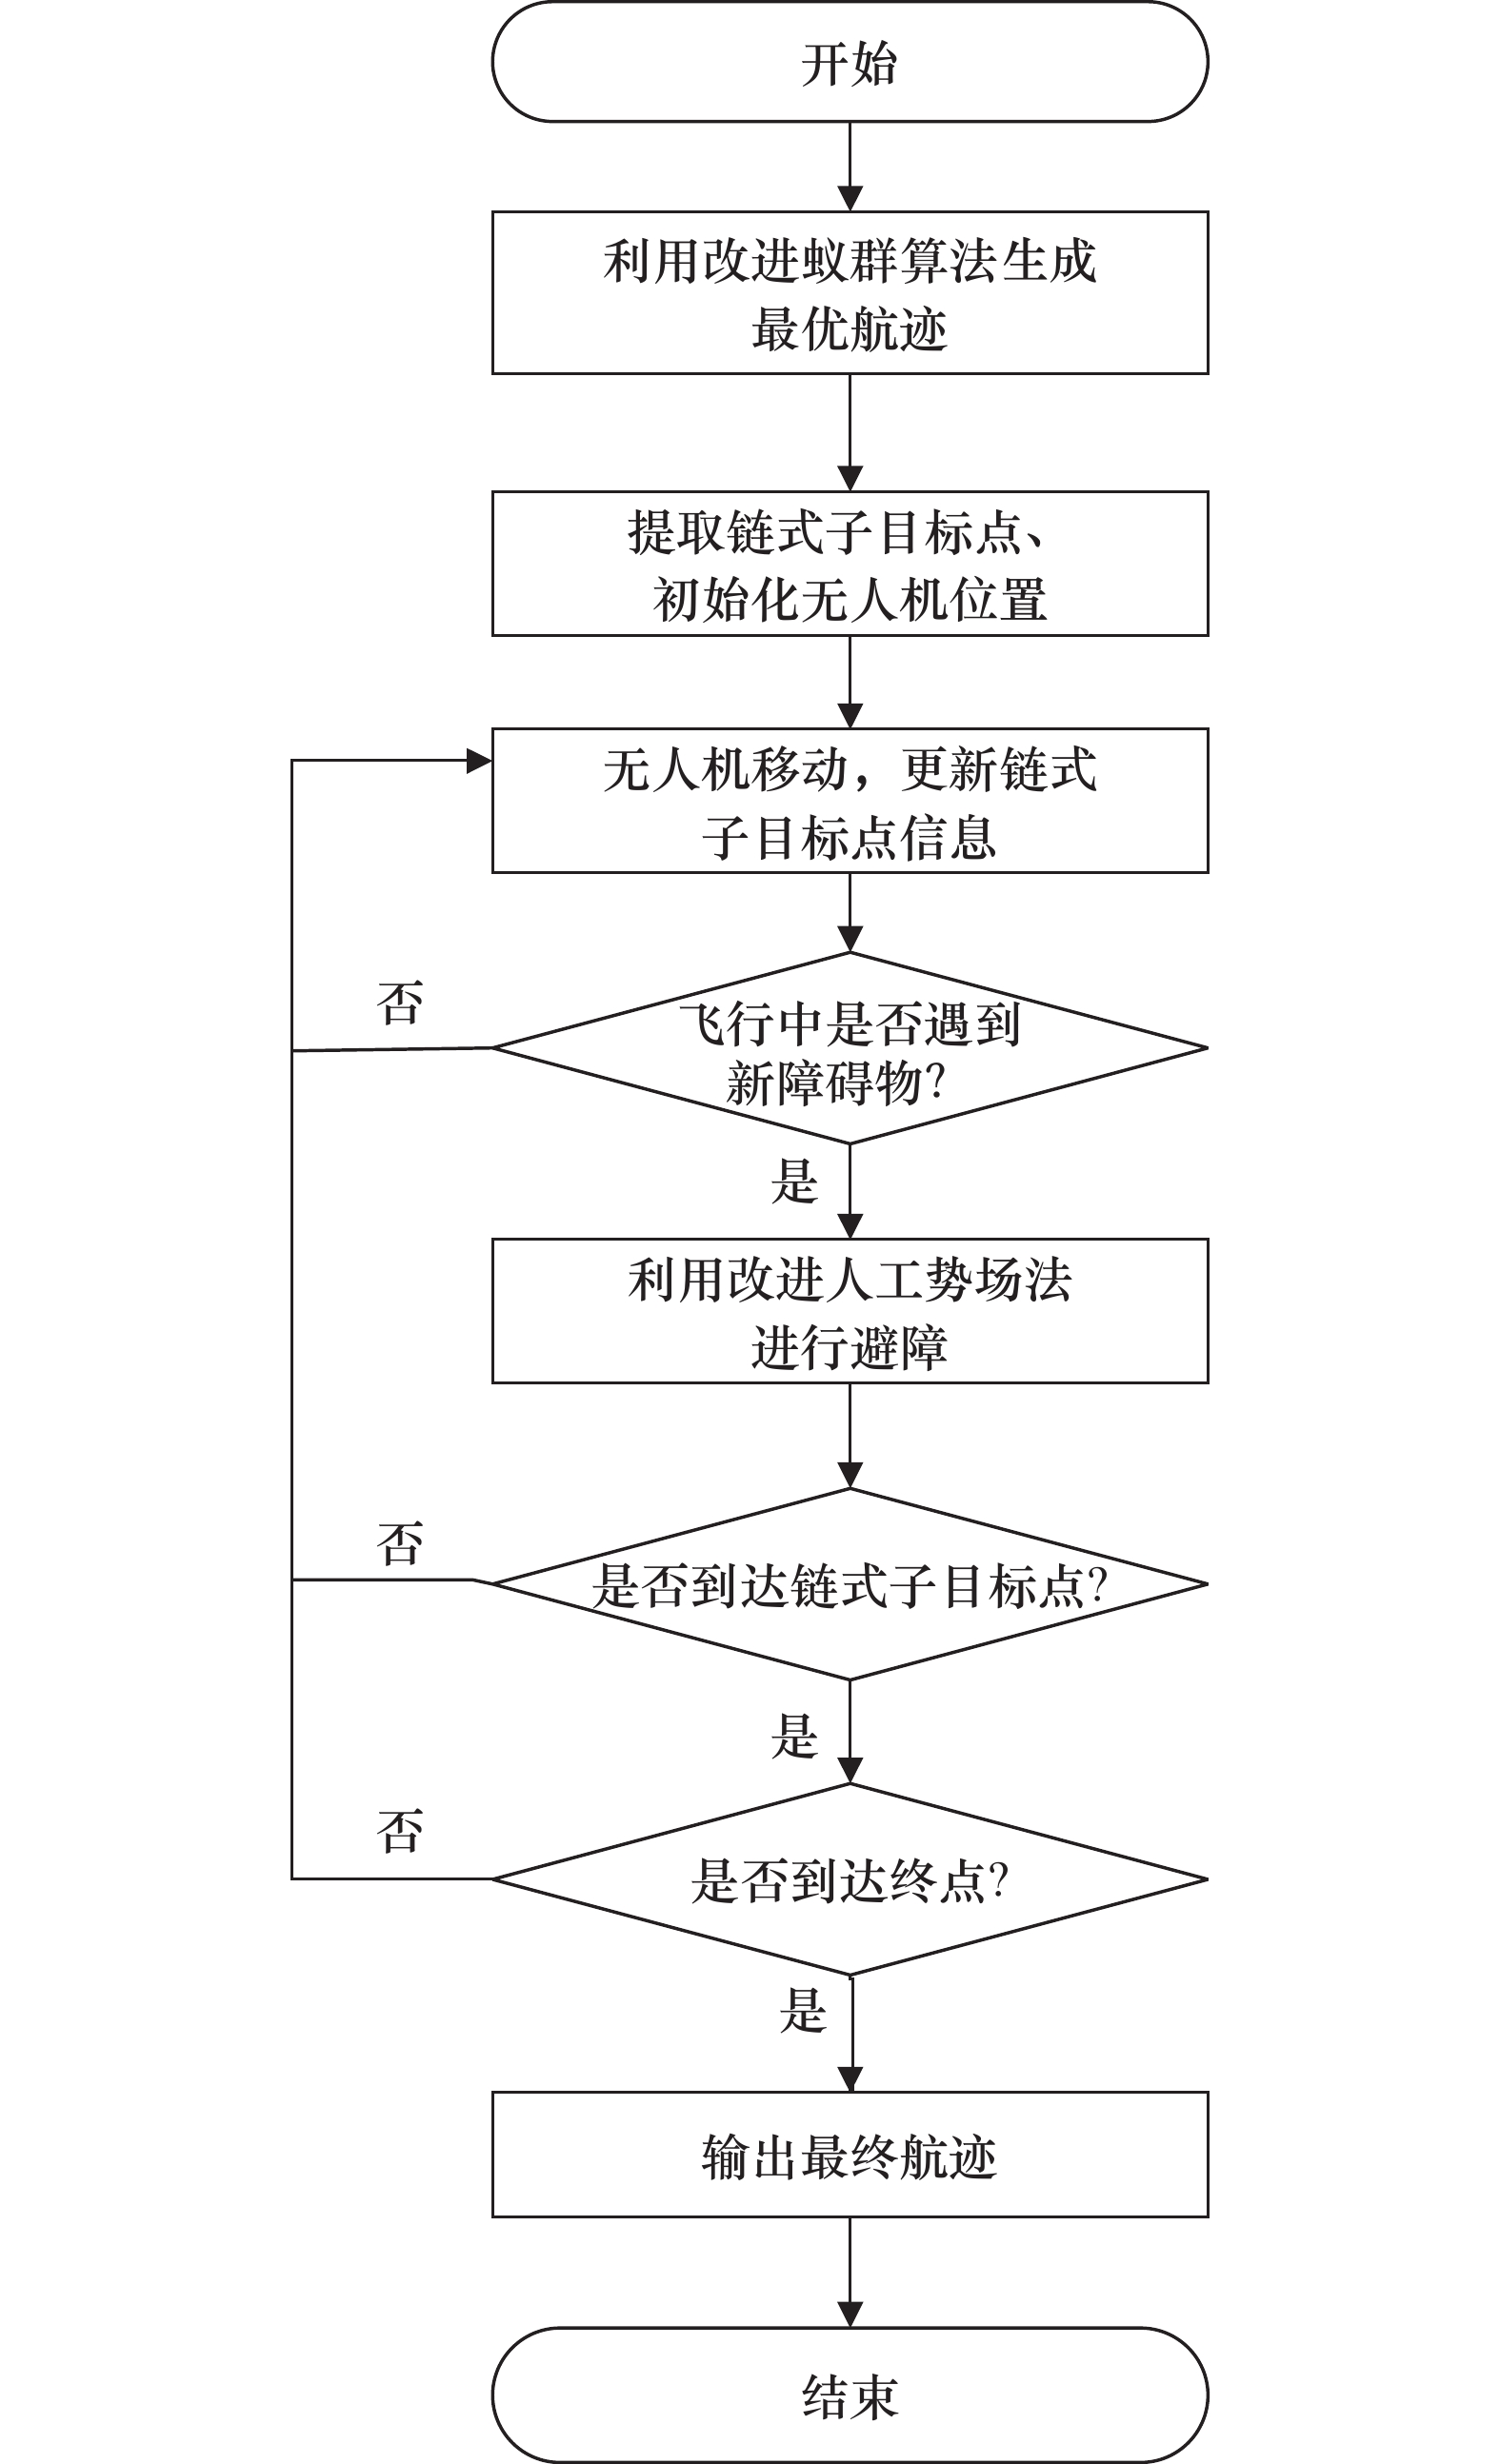
表1
参数大小作用效果"
| 类型 | 对算法产生的影响 |
选择之前走过的航迹,收敛速度快 | |
增加可选航迹,收敛速度慢 | |
选择局部最优航迹,陷入局部最优 | |
收敛速度过慢,难以找到最优解 |
图2
改进蚁群算法流程"
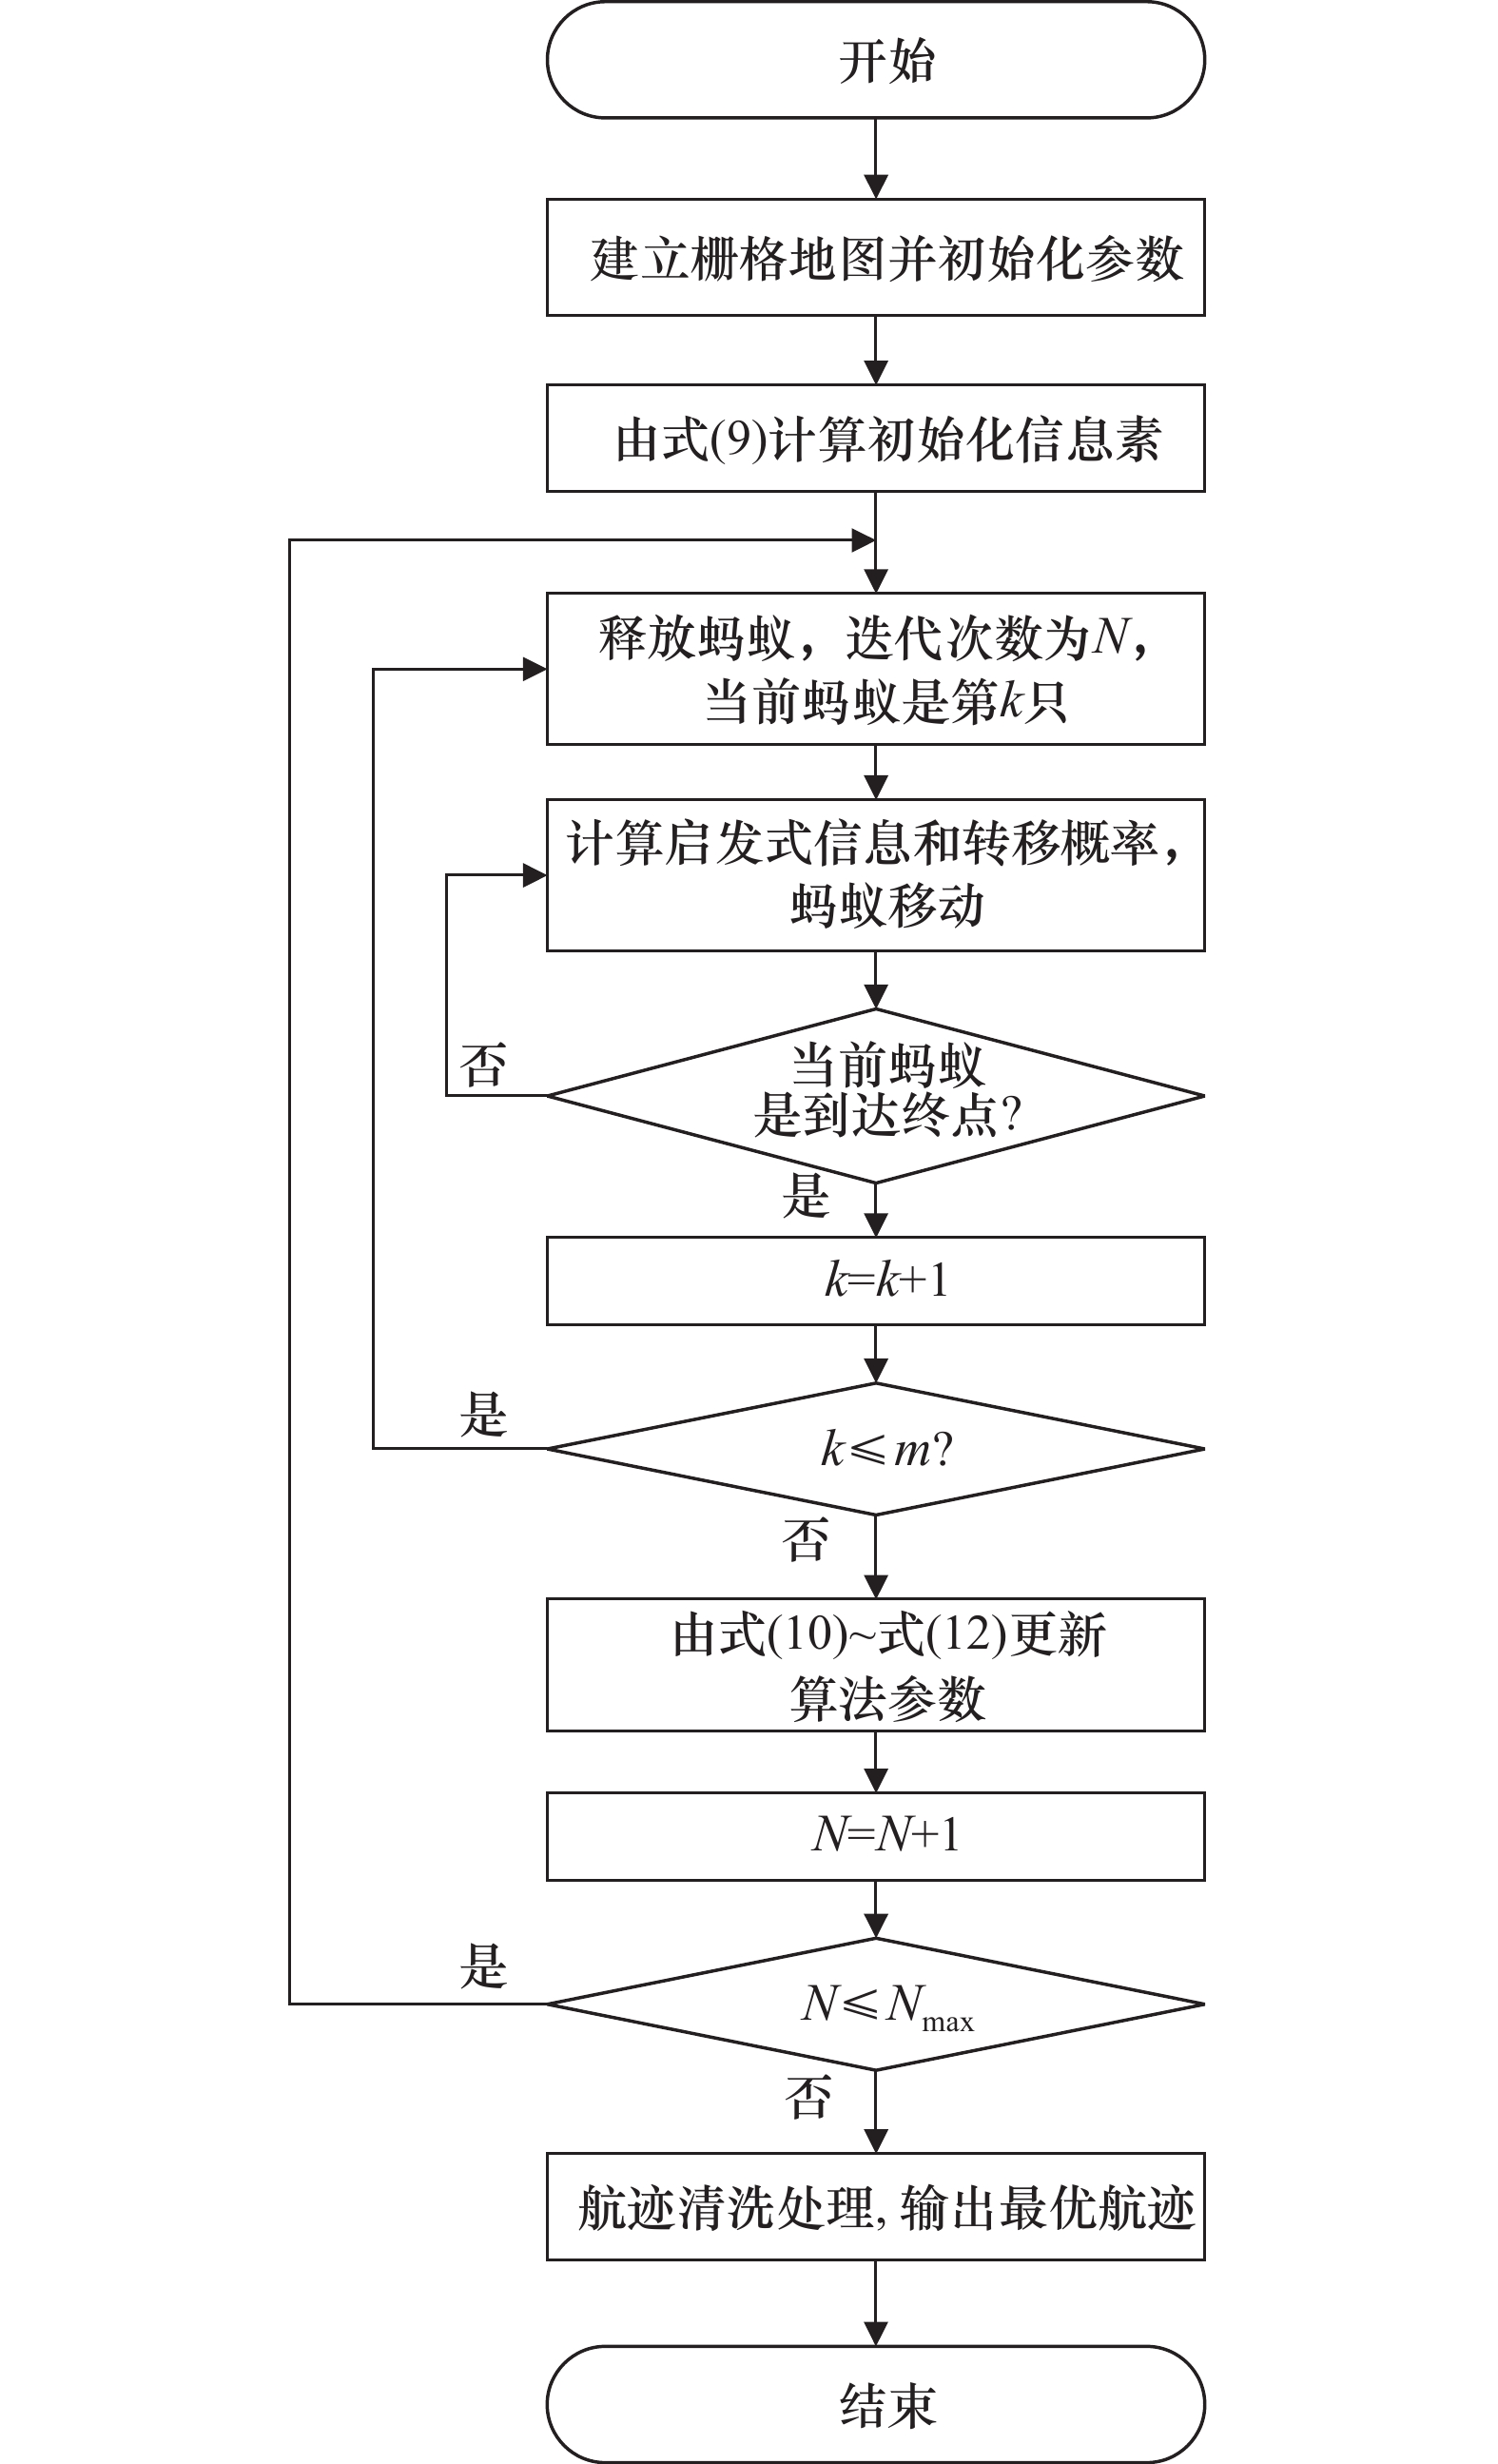
图3
改进人工势场法流程"
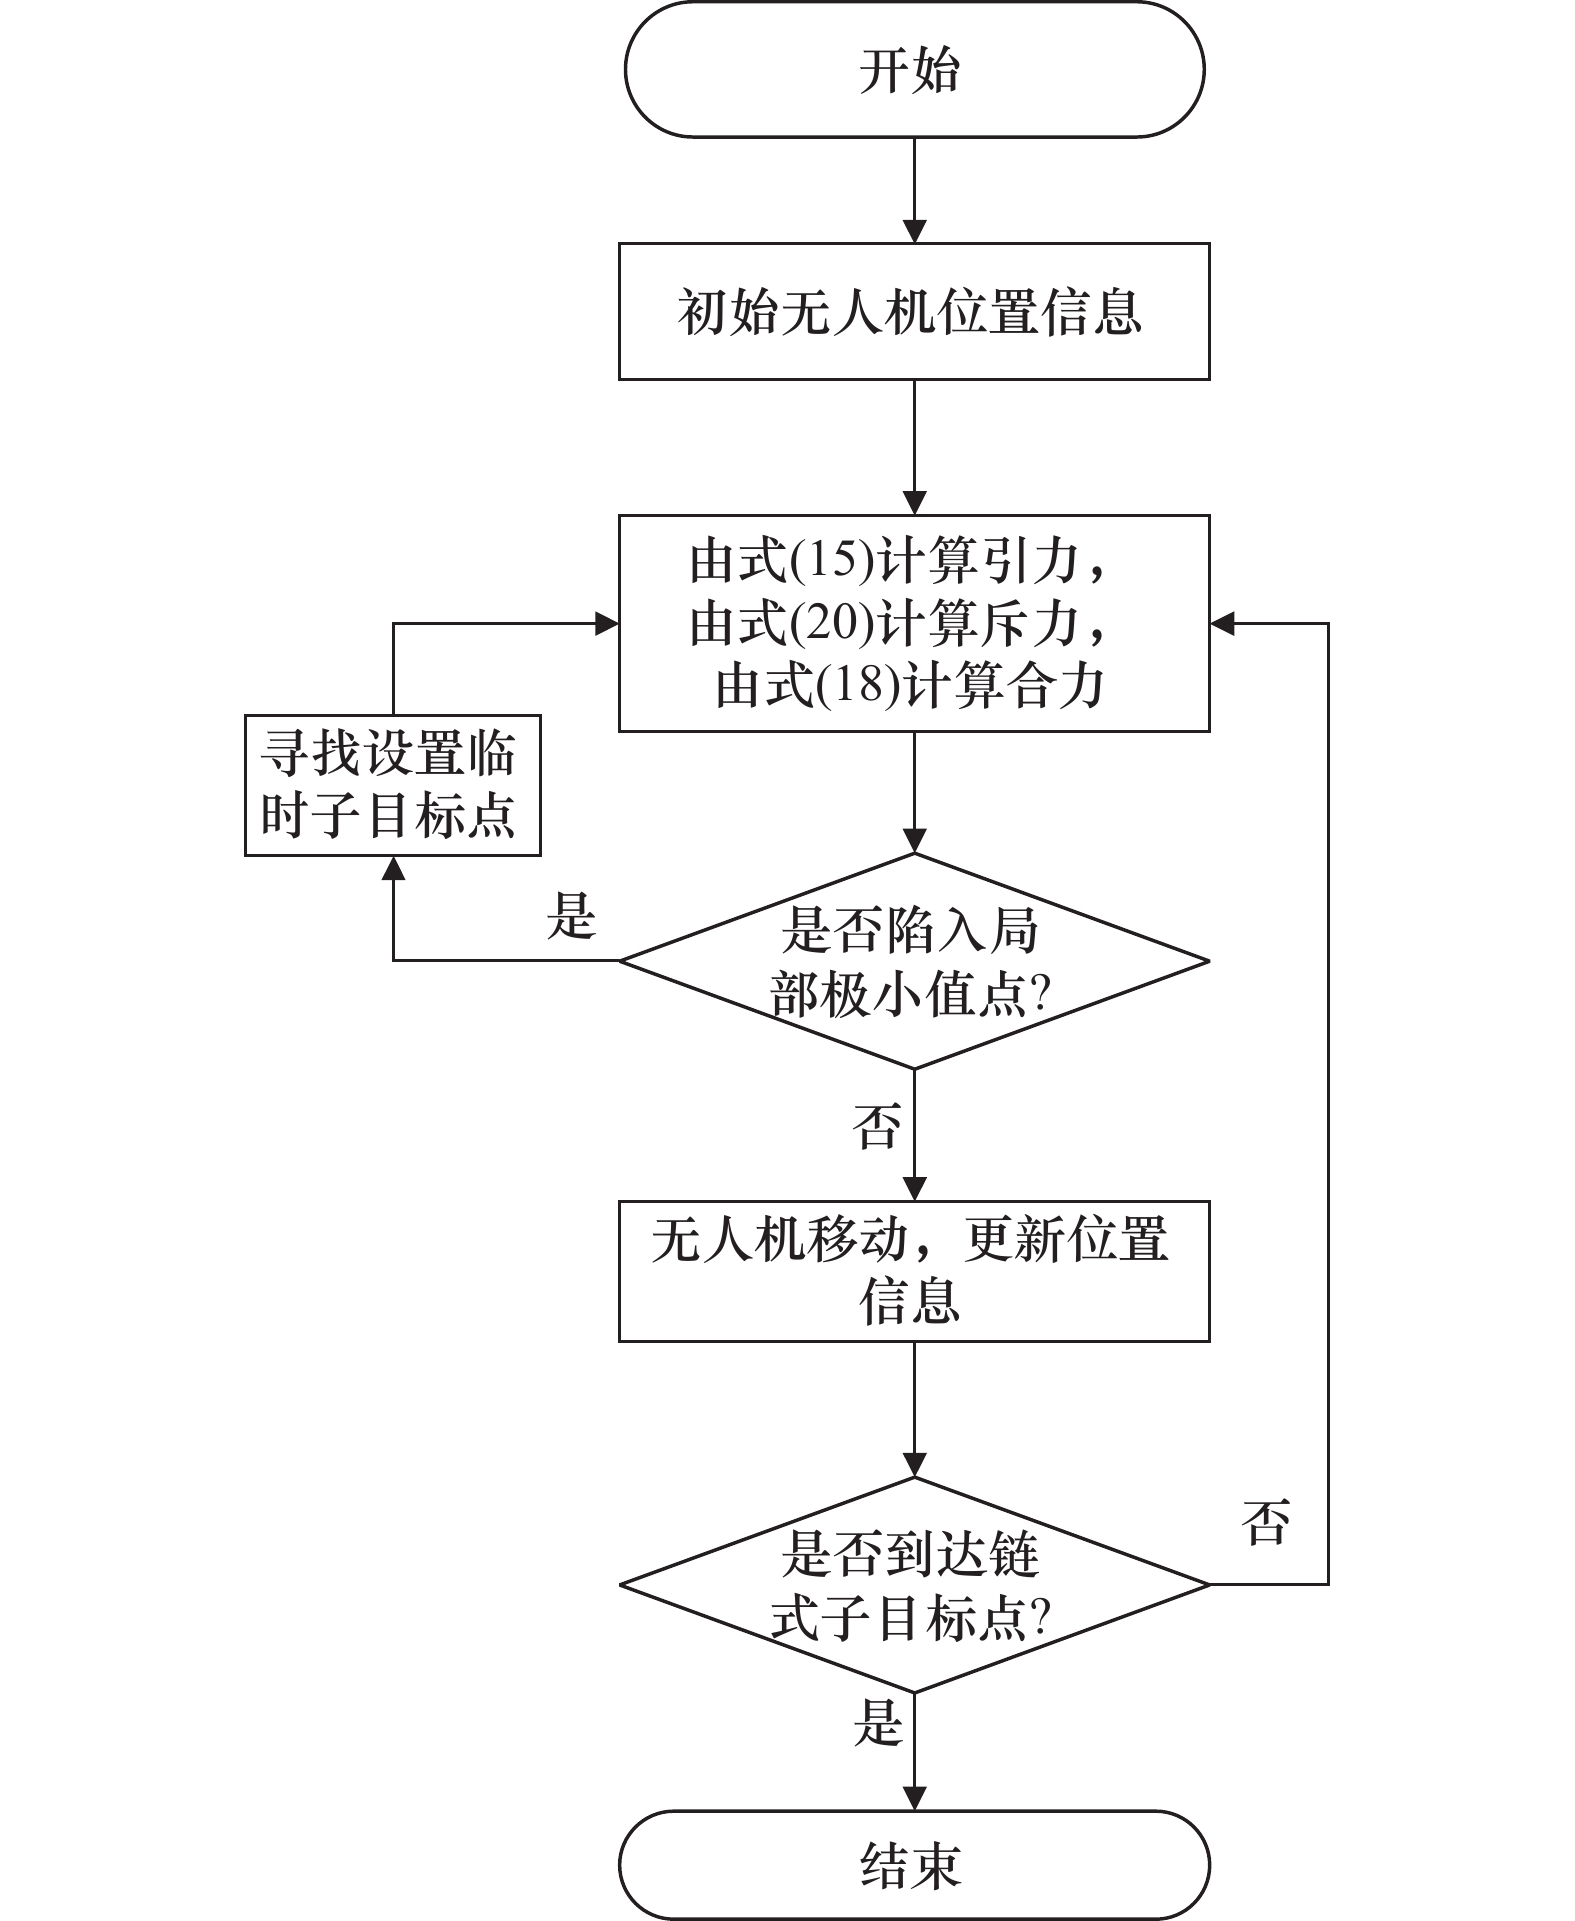
图4
栅格地图"
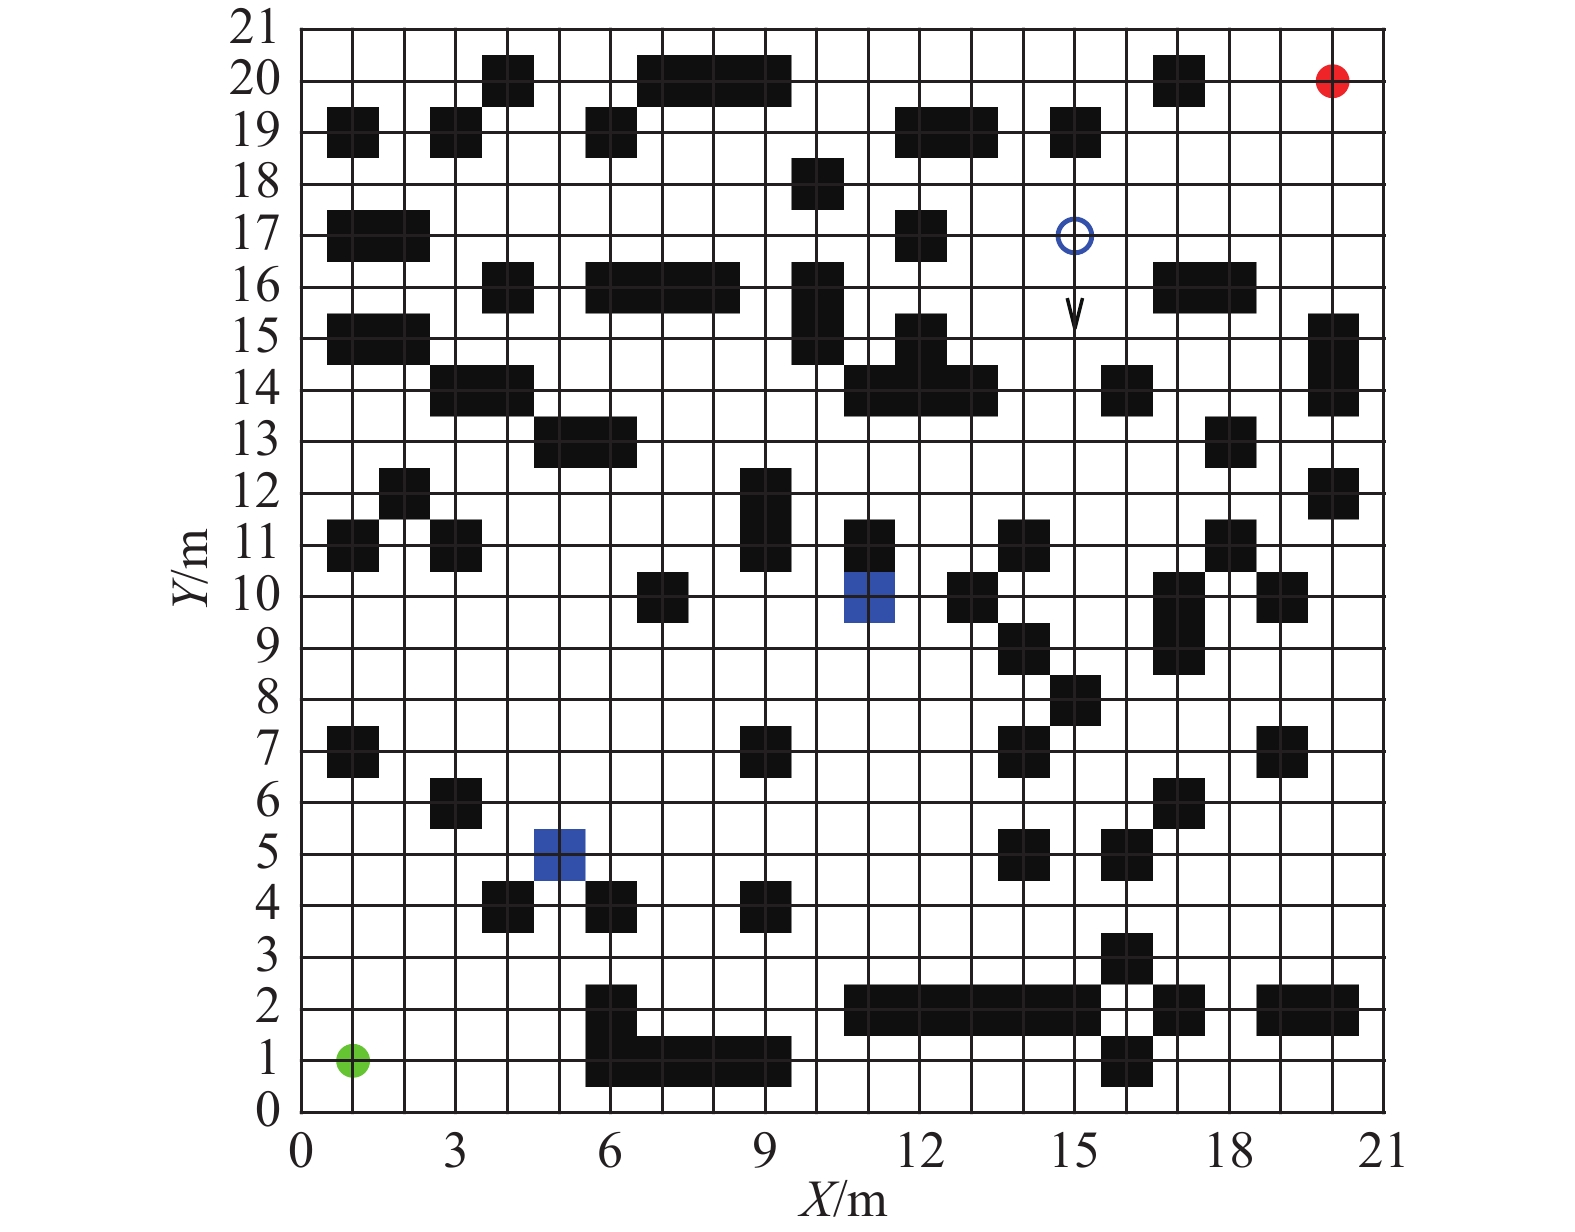
表2
改进蚁群算法参数"
| 参数 | 数值 |
| 蚂蚁数量 | 50 |
| 最大迭代次数 | 100 |
| 信息素权重最小值 | 1 |
| 信息素权重最大值 | 4 |
| 启发函数权重最小值 | 3 |
| 启发函数权重最大值 | 8 |
| 信息素挥发系数 | 0.7 |
| 迭代界限量 | 30 |
| 信息素常量 | 100 |
| 平滑因子 | 10 |
| 归一化距离常数 | 0.01 |
| 初始化信息素常数 | 0.01 |
| 归一化距离权重 | 0.8 |
| 航迹平滑度权重 | 0.2 |
图5
航迹规划结果1对比"
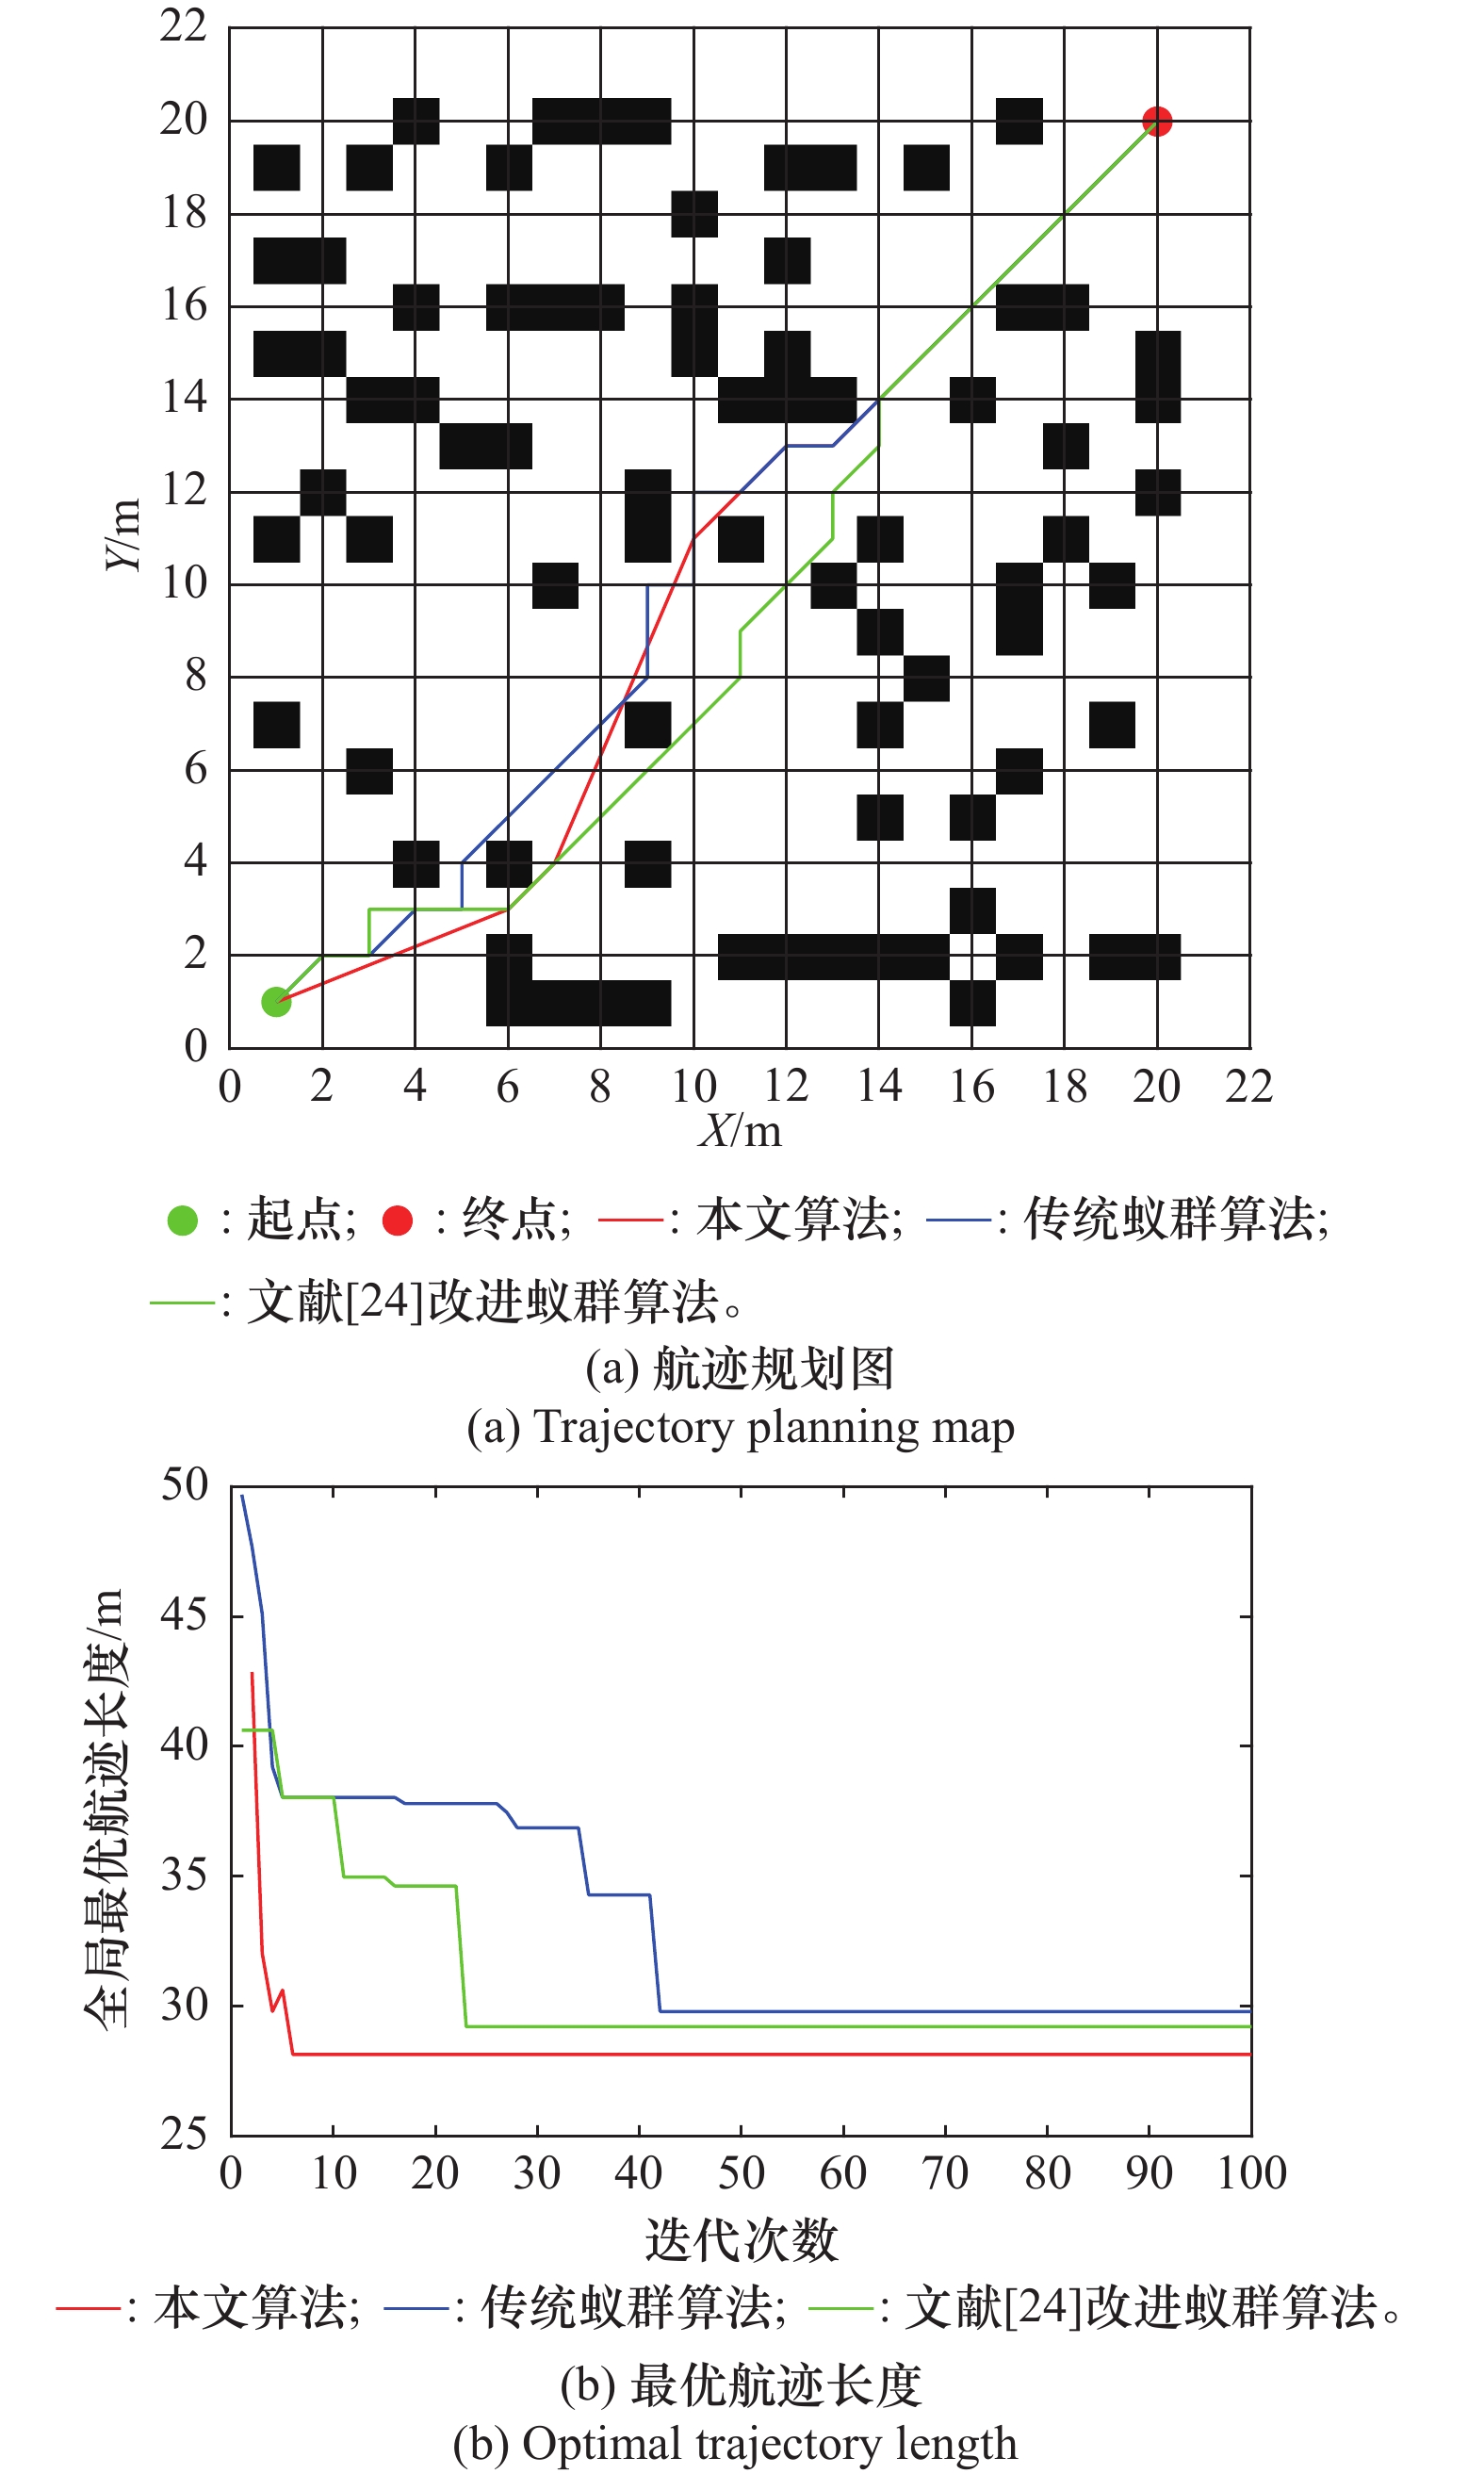
表3
算法仿真结果1"
| 算法 | 最优航迹长度/m | 迭代次数 | 转弯次数 |
| 本文算法 | 28.1 | 6 | 5 |
| 传统蚁群算法 | 29.8 | 42 | 12 |
| 文献[ | 29.2 | 23 | 10 |
图6
航迹规划结果2对比"
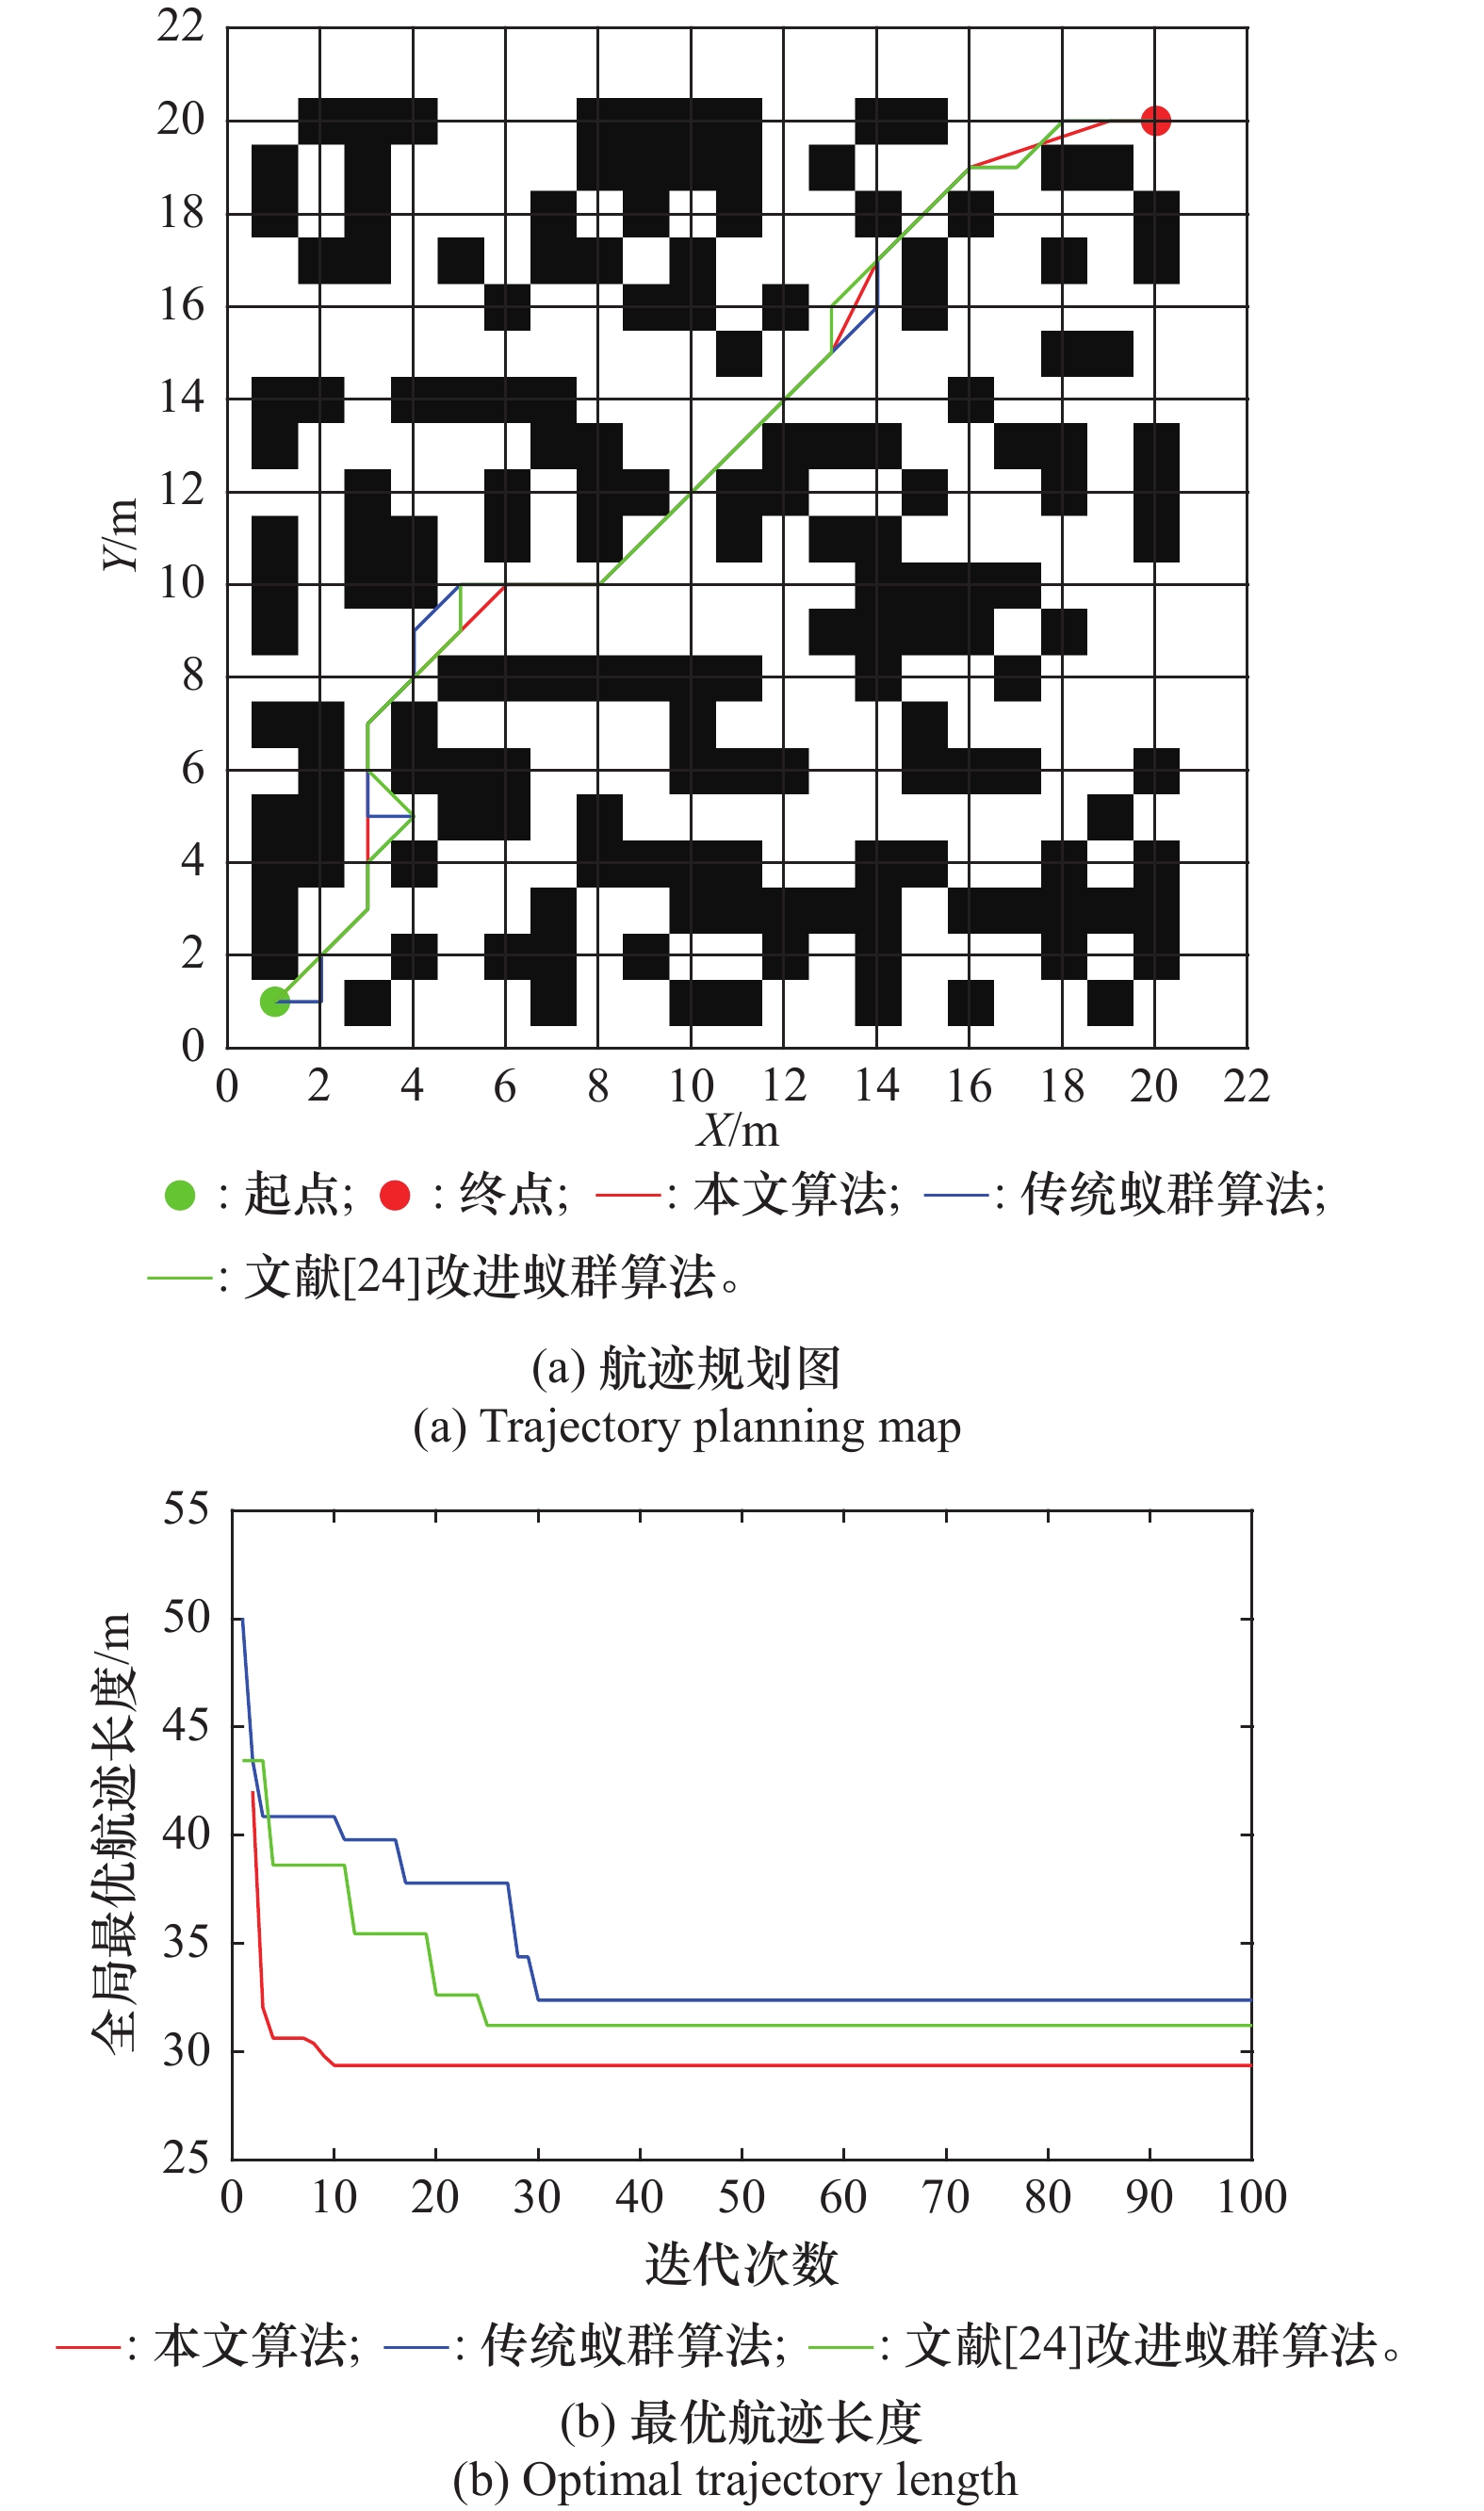
表4
算法仿真结果2"
| 算法 | 最优航迹长度/m | 迭代次数 | 转弯次数 |
| 本文算法 | 29.3 | 10 | 8 |
| 传统蚁群算法 | 32.3 | 30 | 16 |
| 文献[ | 31.2 | 25 | 13 |
表5
改进人工势场法参数"
| 参数 | 数值 |
| 引力系数 | 5 |
| 斥力系数 | 15 |
| 斥力作用范围 | 1.5 |
| 步长 | 0.1 |
| 起点位置 | (1,1) |
| 终点位置 | (18,19) |
图7
改进人工势场法航迹规划"
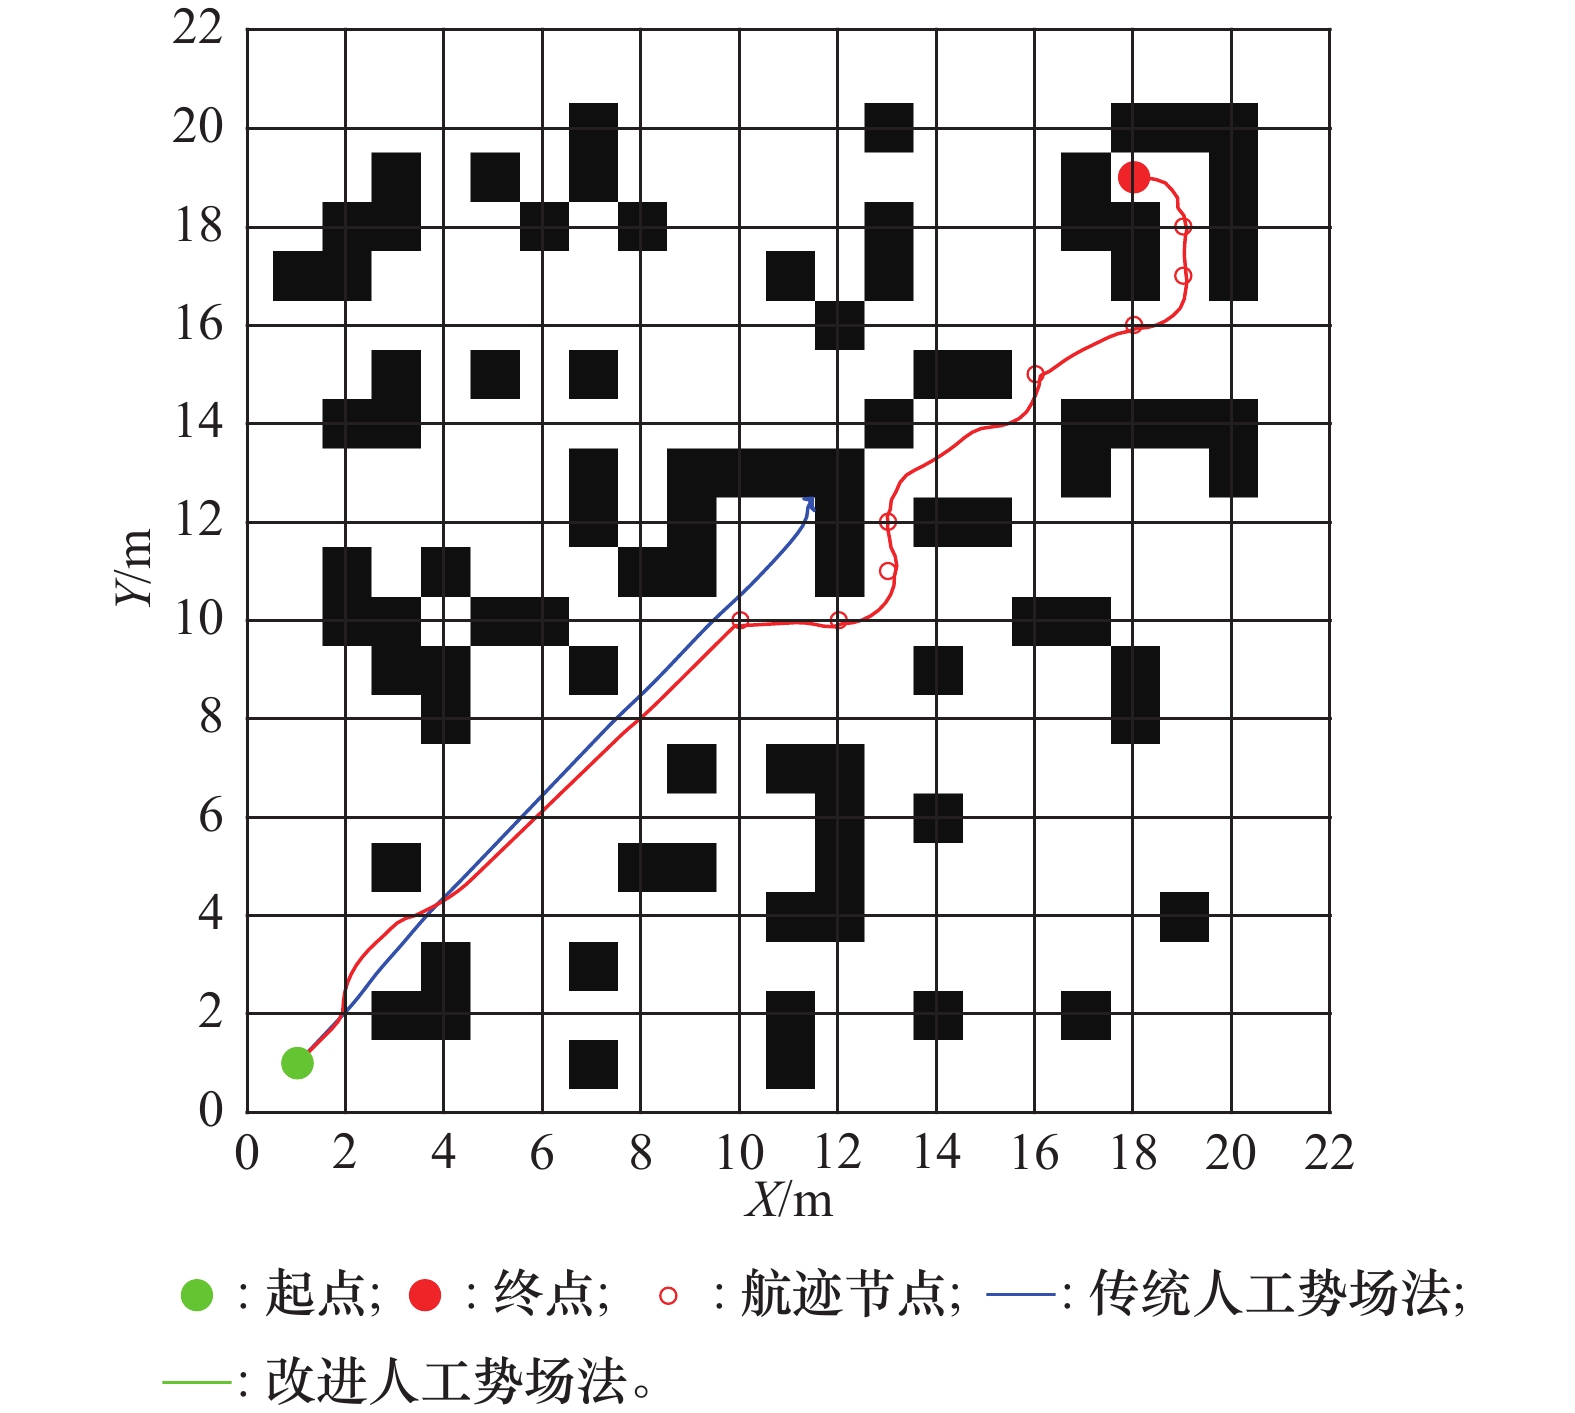
表6
链式子目标点坐标"
| 节点序号 | 位置坐标 |
| 1 | (1,1) |
| 2 | (6,3) |
| 3 | (7,4) |
| 4 | (10,11) |
| 5 | (12,13) |
| 6 | (13,13) |
| 7 | (20,20) |
图8
1个静态障碍物"
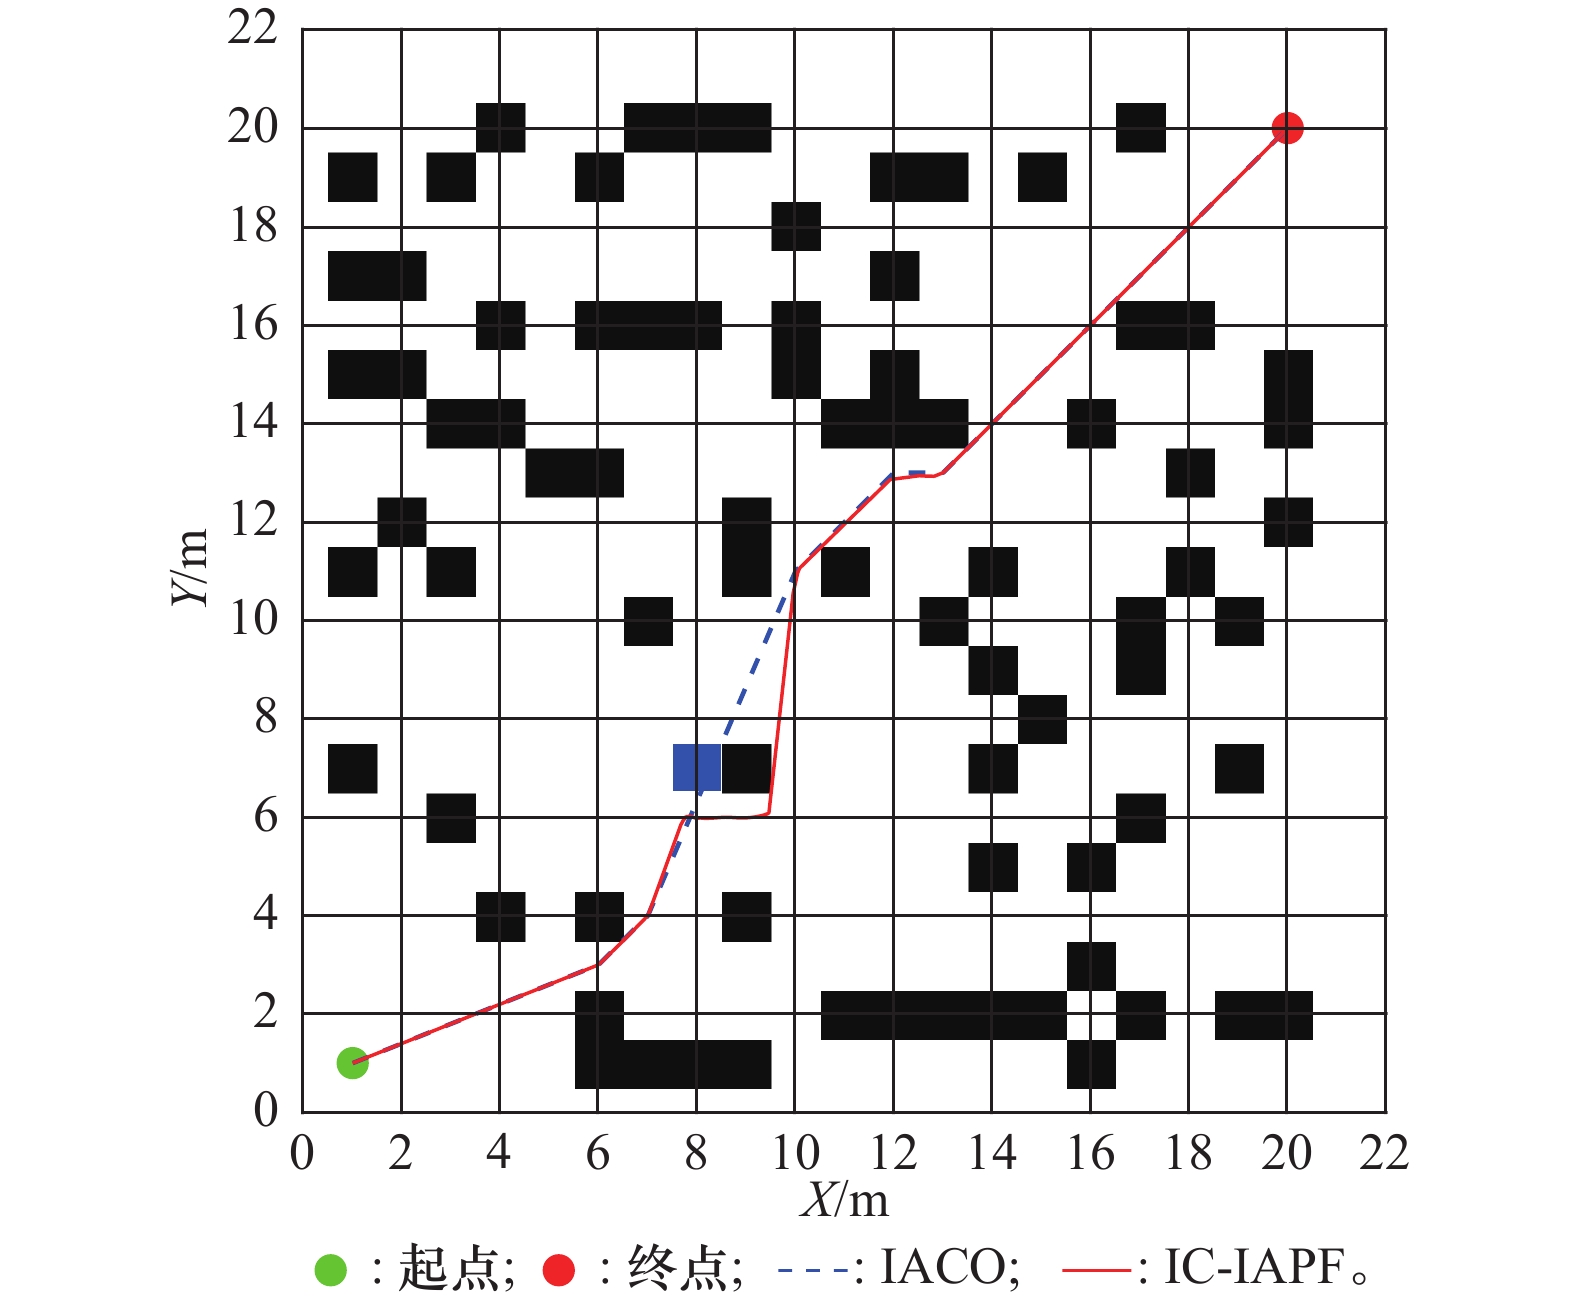
表7
静态障碍物坐标"
| 编号 | 位置坐标 |
| 1 | (8,7) |
| 2 | (10,11) |
| 3 | (12,13) |
| 4 | (16,16) |
图9
4个静态障碍物"
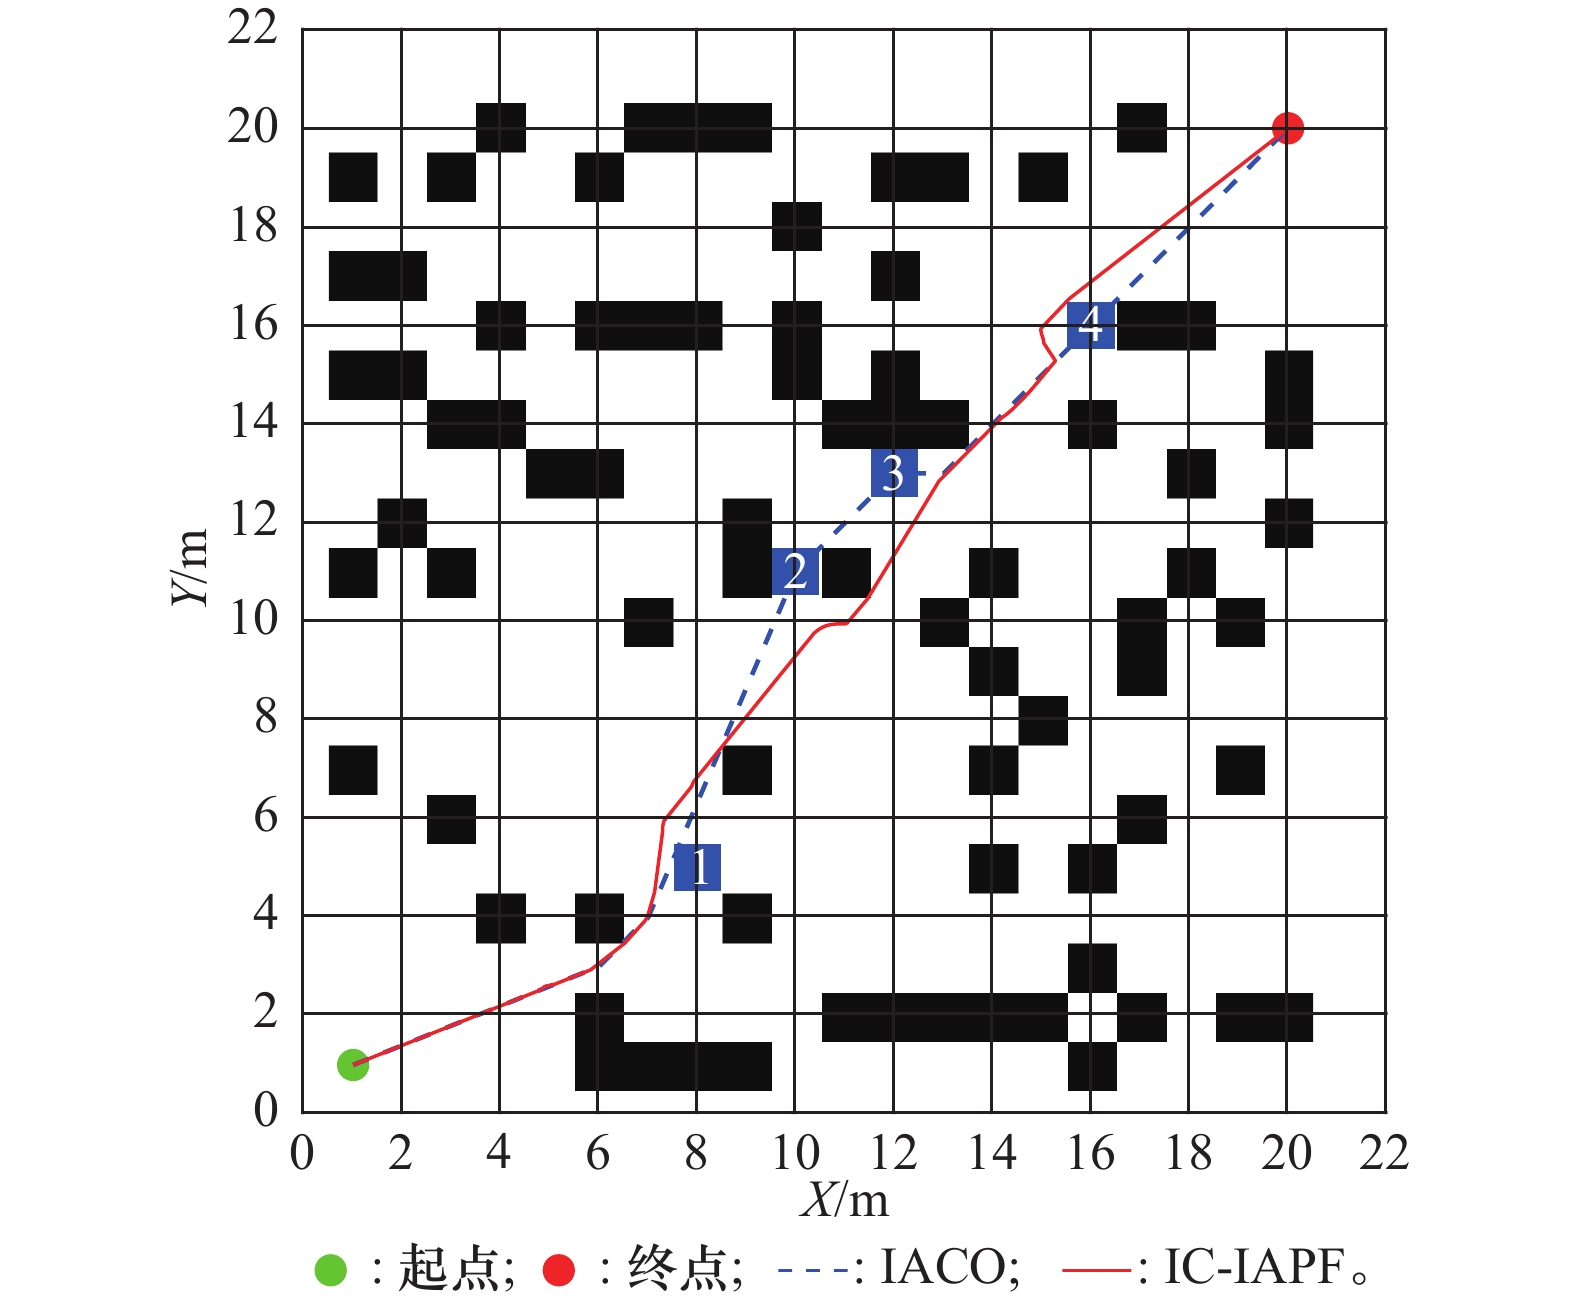
图10
1个动态障碍物"
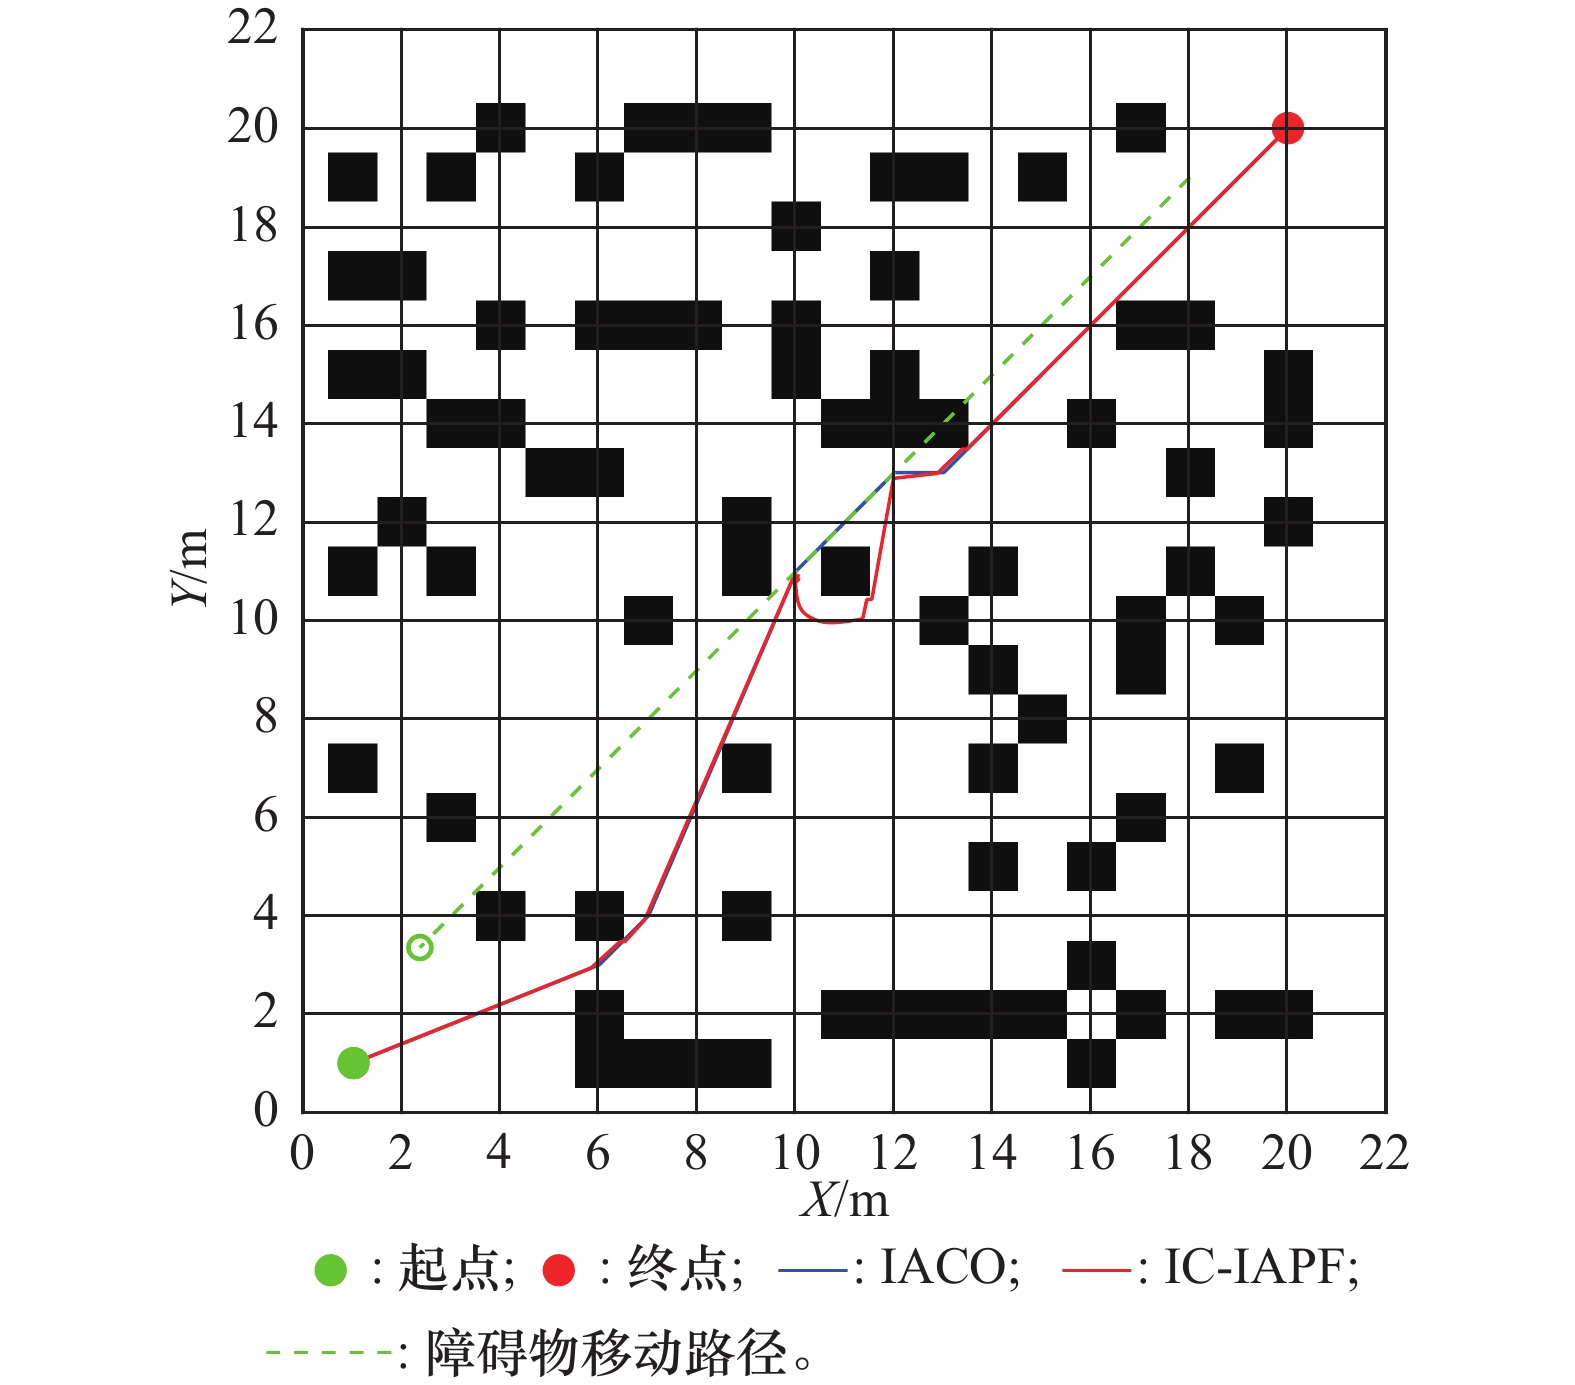
表8
动态障碍物信息"
| 编号 | 初始位置坐标 | 初始速度/(m/s) |
| 1 | (18,19) | (−0.05,−0.05) |
| 2 | (5,5) | (0.04,0) |
| 3 | (15,15) | (0,0.05) |
图11
3个动态障碍物"
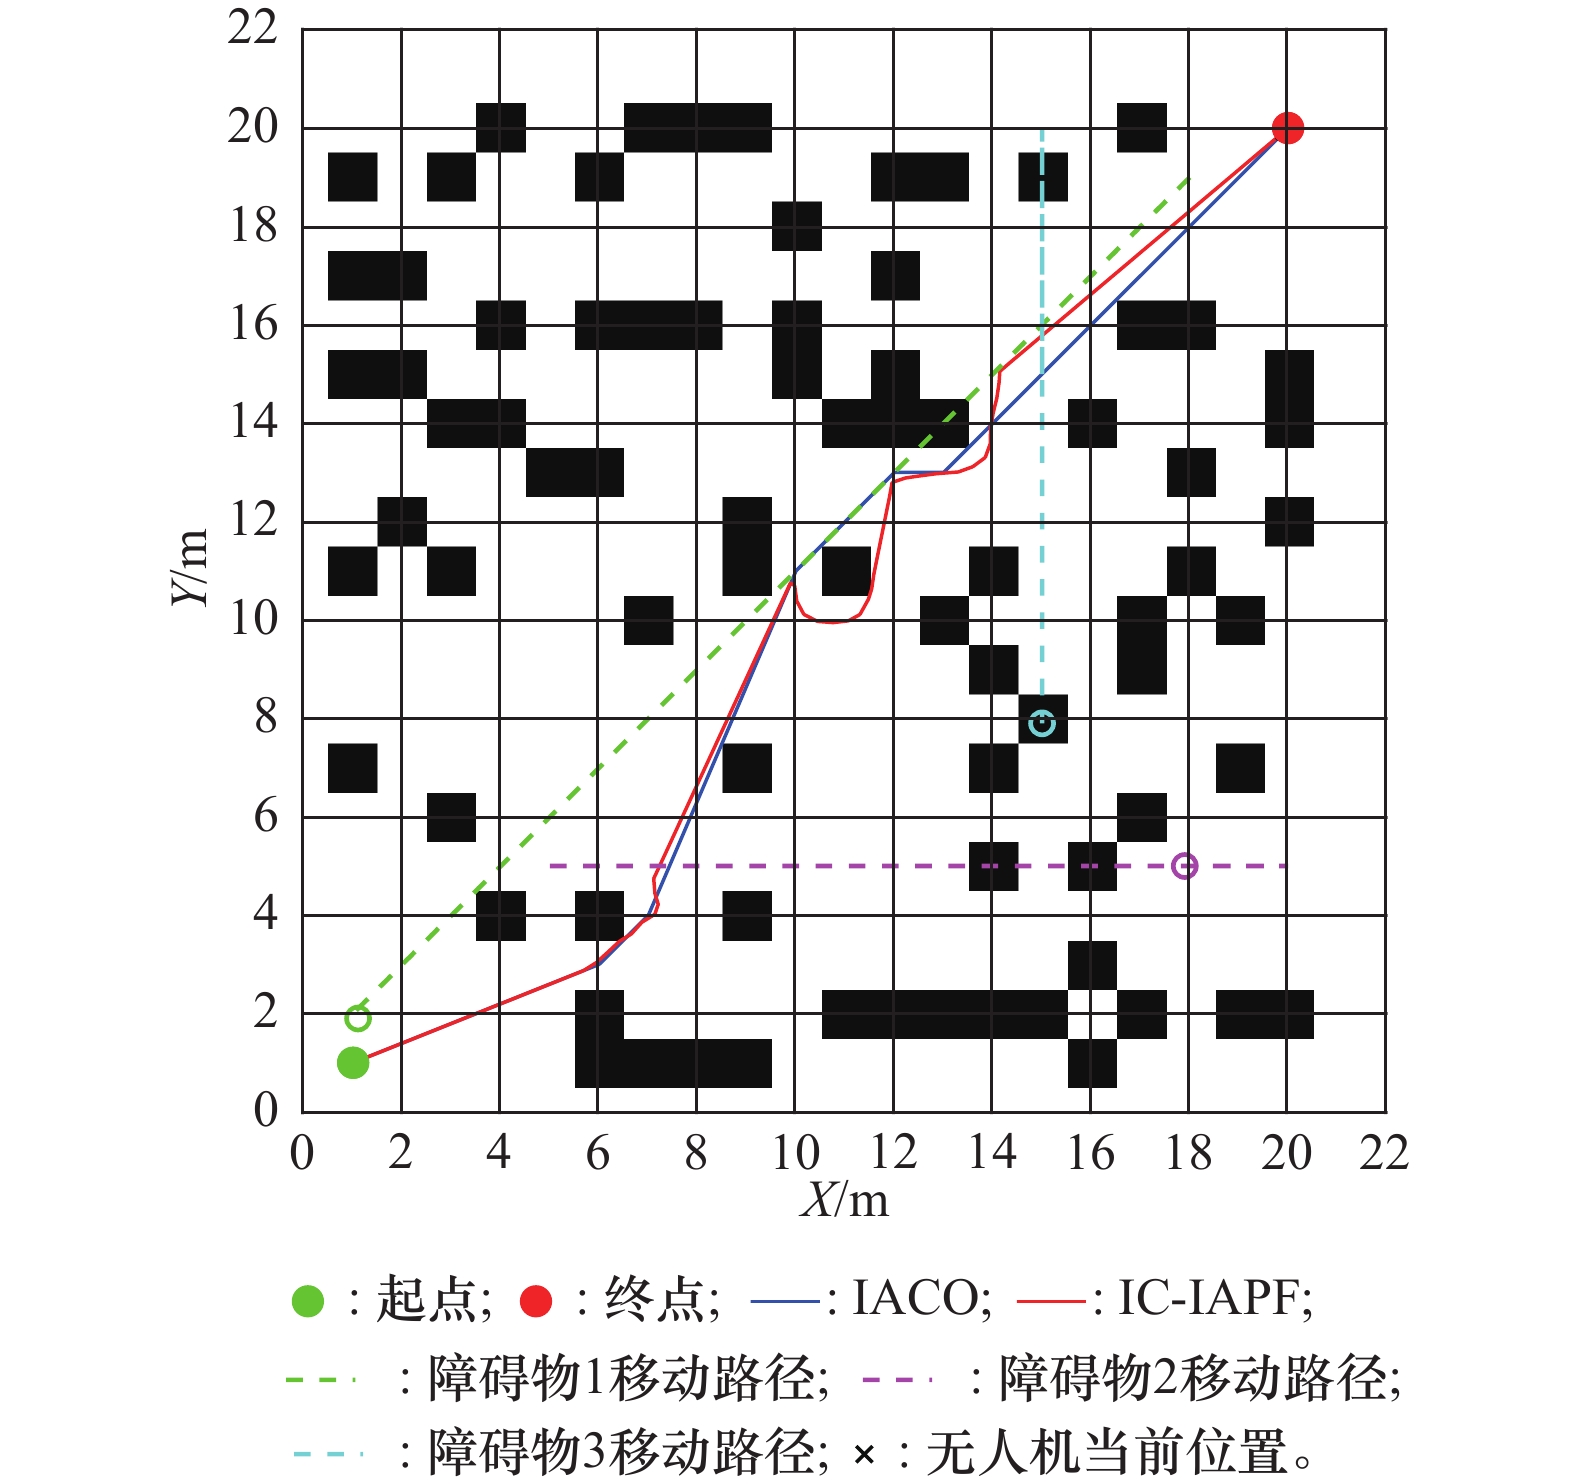
图12
无人机与障碍物之间距离"
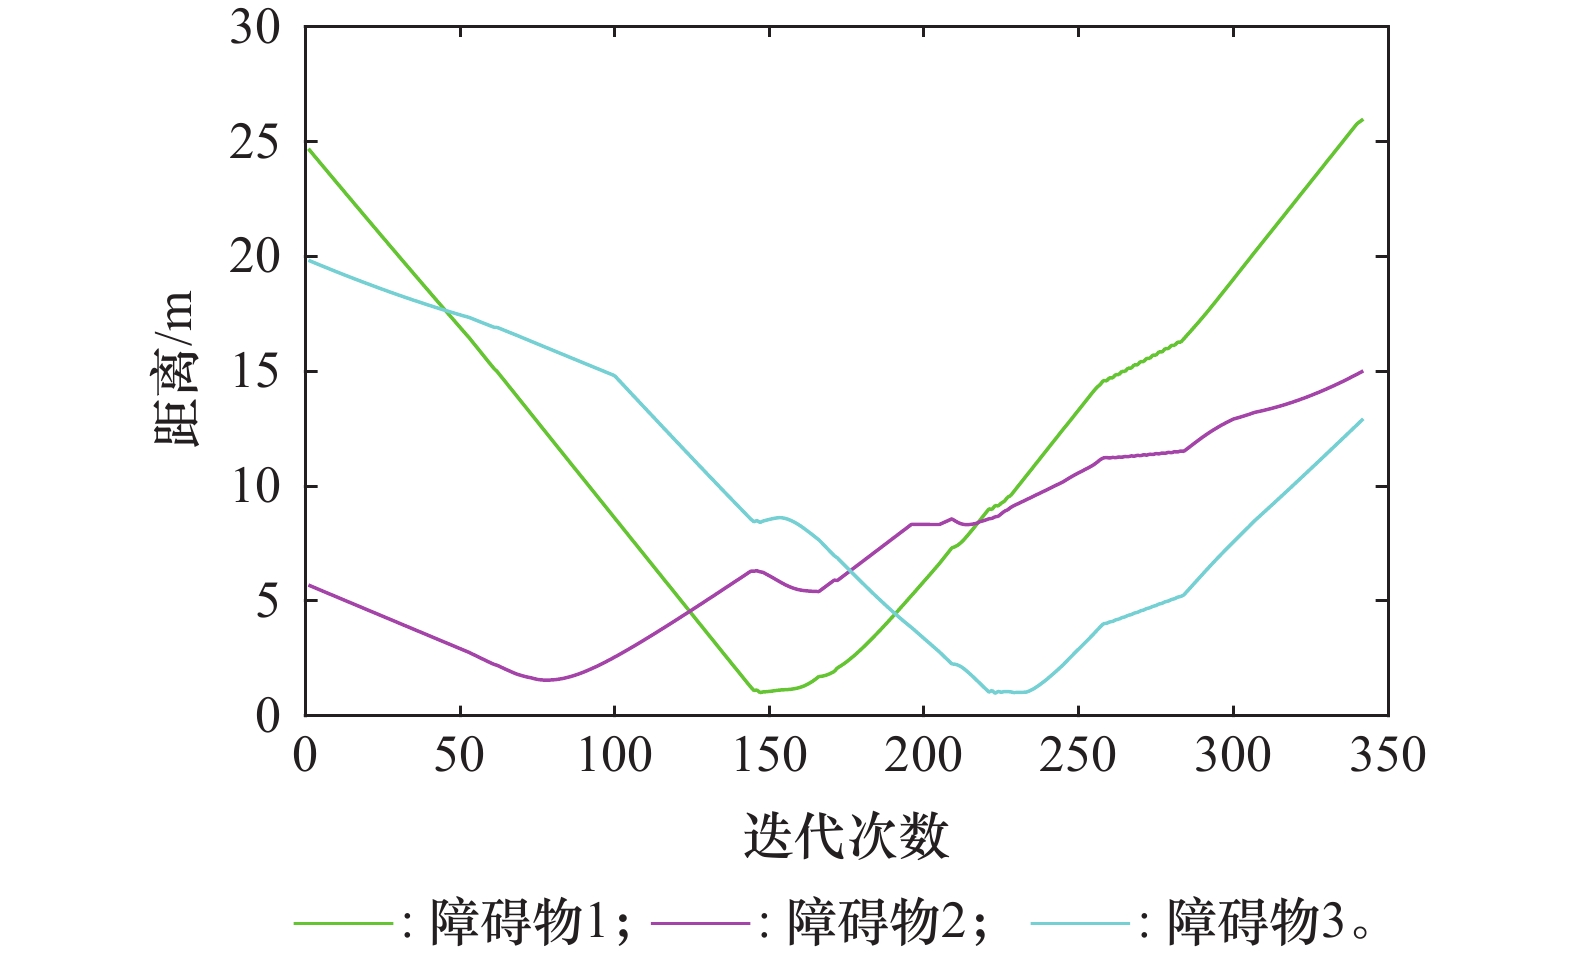
图13
避让动态障碍物"
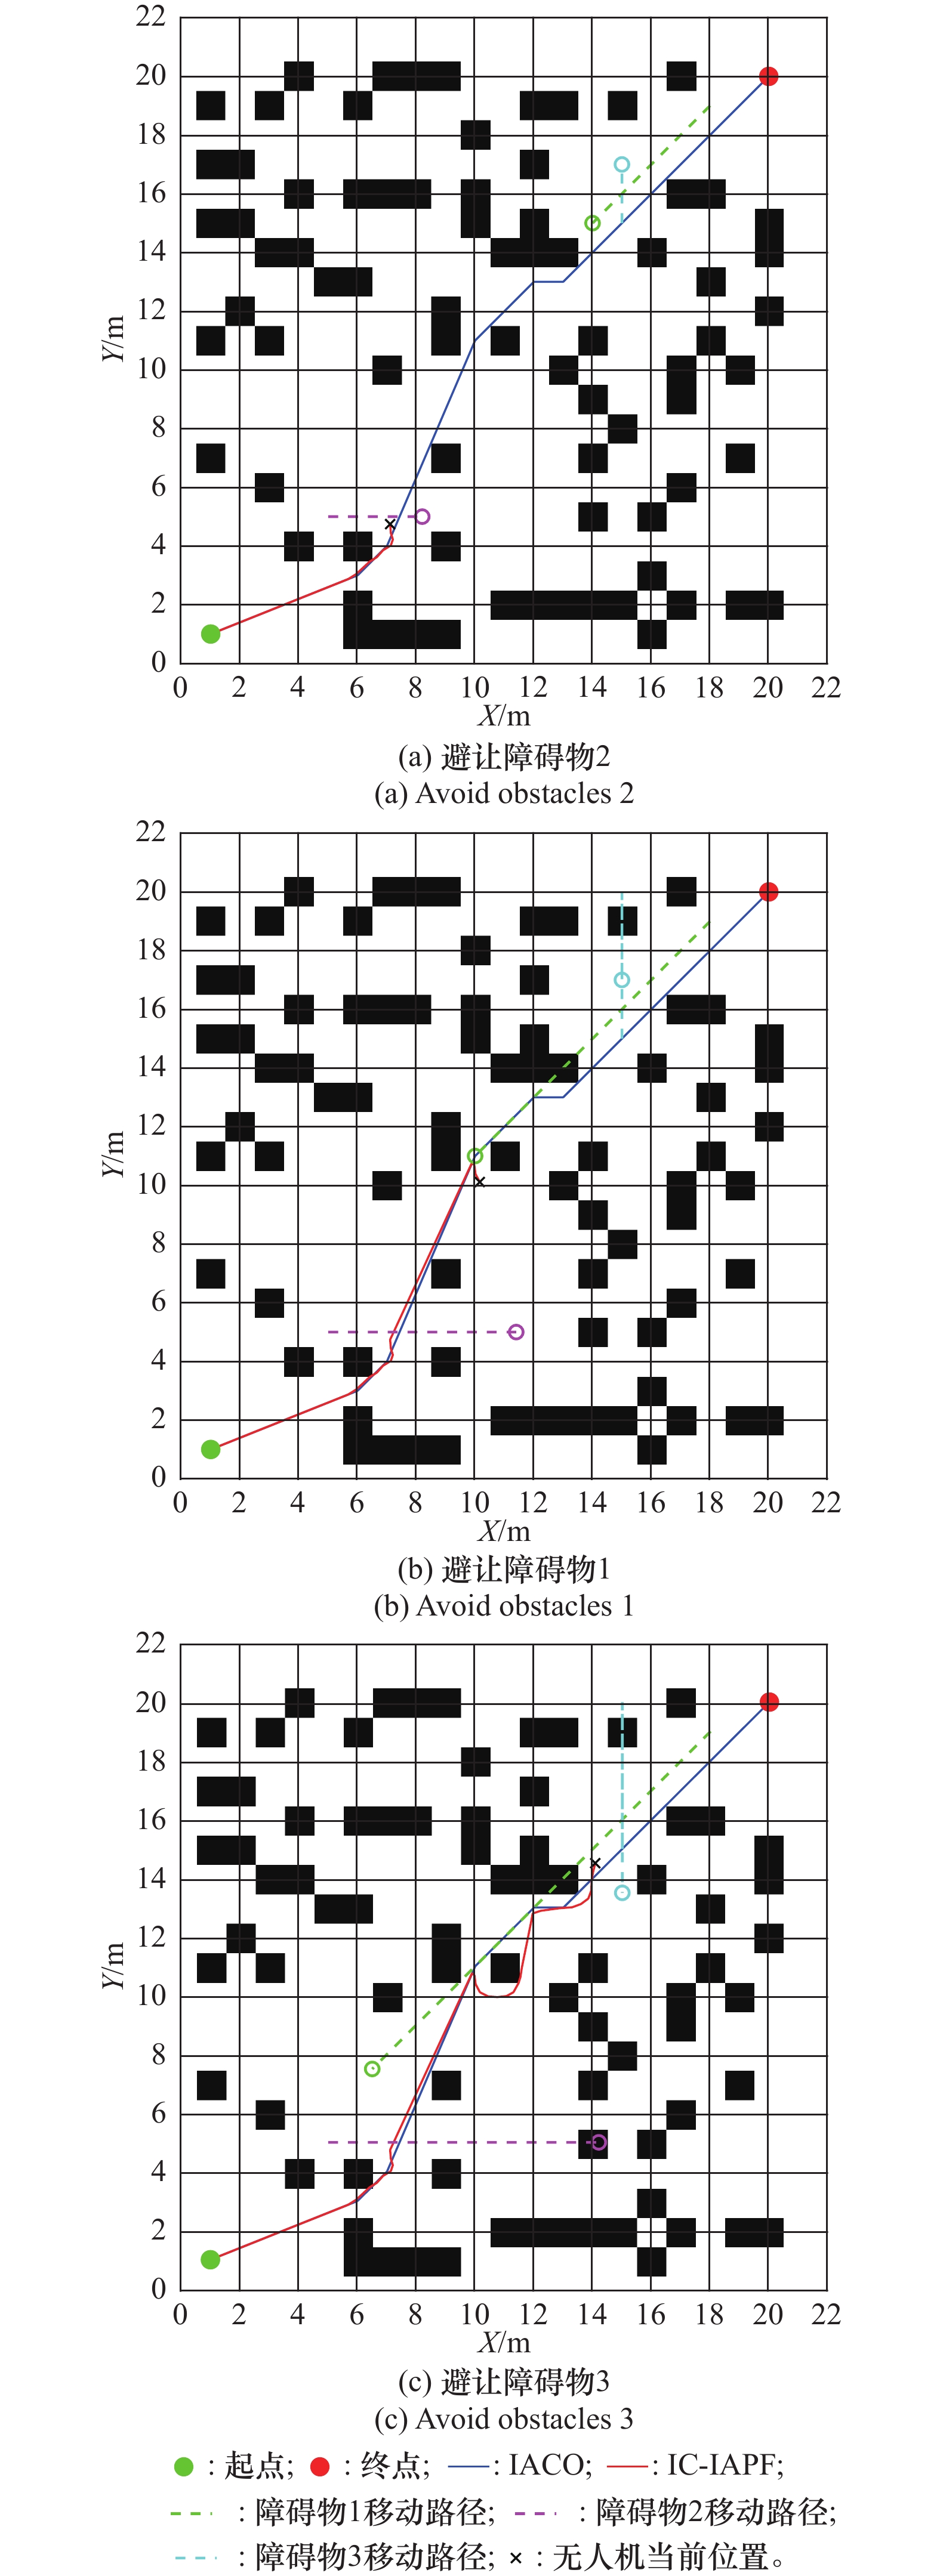
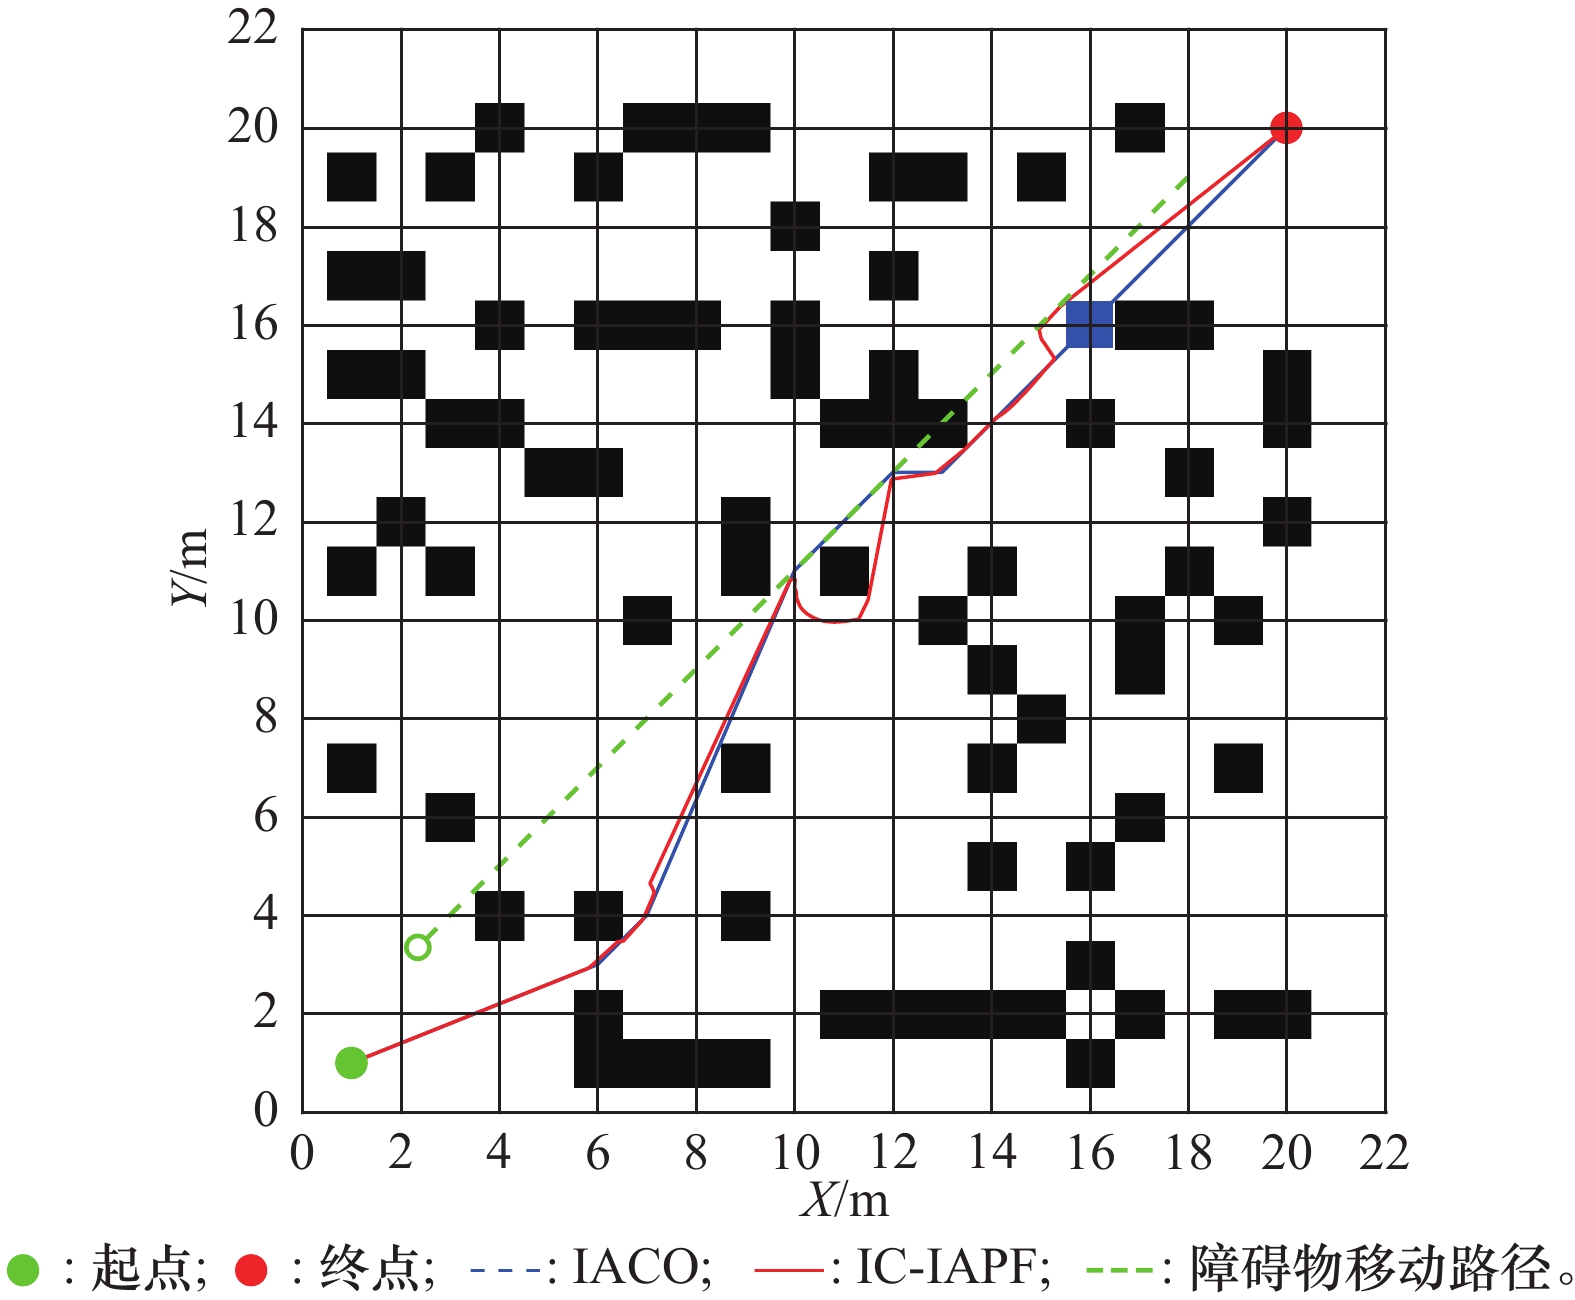
图14
静态和动态障碍物"
| 1 |
Fei C, Lu Z, Jiang W W. Heuristic optimization-based trajectory planning for UAV swarms in urban target strike operations[J]. Drones, 2024, 8 (12): 777.
doi: 10.3390/drones8120777 |
| 2 |
Alam M M, Arafat M Y, Moh S, et al. Topology control algorithms in multi-unmanned aerial vehicle networks: an extensive survey[J]. Journal of Network and Computer Applications, 2022, 207, 103495.
doi: 10.1016/j.jnca.2022.103495 |
| 3 |
Zhou C Y, Liu J Y, Qu K G, et al. Delay-aware UAV computation offloading and communication assistance for post-disaster rescue[J]. IEEE Trans. on Wireless Communications, 2024, 23 (12): 19110.
doi: 10.1109/TWC.2024.3479709 |
| 4 |
Huang J B, Chen C M, Shen J J, et al. A self-adaptive neighborhood search A-star algorithm for mobile robots global path planning[J]. Computers and Electrical Engineering, 2025, 123, 110018.
doi: 10.1016/j.compeleceng.2024.110018 |
| 5 |
Farid G, Cocuzza S, Younas T, et al. Modified A-star (A*) approach to plan the motion of a quadrotor UAV in three-dimensional obstacle-cluttered environment[J]. Applied Sciences, 2022, 12 (12): 5791.
doi: 10.3390/app12125791 |
| 6 |
Gutierrez-martinez M A, Rojo-rodriguez E G, Cabriales-ramirez L E, et al. Genetic algorithm-based path planning of quadrotor UAVs on a 3D environment[J]. The Aeronautical Journal, 2025, 129 (1334): 902.
doi: 10.1017/aer.2024.132 |
| 7 |
Yang Y, Fu Y J, Lu D Y, et al. Three-dimensional unmanned aerial vehicle trajectory planning based on the improved whale optimization algorithm[J]. Symmetry, 2024, 16 (12): 1561.
doi: 10.3390/sym16121561 |
| 8 |
Xiang F T, Chen K X, Su J M, et al. Penetration planning and design method of unmanned aerial vehicle inspired by biological swarm intelligence algorithm[J]. Wireless Communications and Mobile Computing, 2021, 2021 (1): 4312592.
doi: 10.1155/2021/4312592 |
| 9 |
Xu C, Xu Z B, Xia M Y. Obstacle avoidance in a three-dimensional dynamic environment based on fuzzy dynamic windows[J]. Applied Sciences, 2021, 11 (2): 504.
doi: 10.3390/app11020504 |
| 10 |
Heidari H, Saska M. Collision-free trajectory planning of multi-rotor UAVs in a wind condition based on modified potential field[J]. Mechanism and Machine Theory, 2021, 156, 104140.
doi: 10.1016/j.mechmachtheory.2020.104140 |
| 11 |
Shao M Z, Liu X, Xiao C S, et al. Research on UAV trajectory planning algorithm based on adaptive potential Field[J]. Drones, 2025, 9 (2): 79.
doi: 10.3390/drones9020079 |
| 12 |
Kelner J M, Burzynski W, Stecz W. Modeling UAV swarm flight trajectories using rapidly-exploring random tree algorithm[J]. Journal of King Saud University-Computer and Information Sciences, 2024, 36 (1): 101909.
doi: 10.1016/j.jksuci.2023.101909 |
| 13 |
Gómez A C, Zamarreño S M, Pérez M F, et al. Path planning for unmanned aerial vehicles in complex environments[J]. Drones, 2024, 8 (7): 288.
doi: 10.3390/drones8070288 |
| 14 | 韩尧, 李少华. 基于改进人工势场法的无人机航迹规划[J]. 系统工程与电子技术, 2021, 43 (11): 3305- 3311. |
| 15 |
Hao G Q, Lv Q, Huang Z, et al. UAV path planning based on improved artificial potential field method[J]. Aerospace, 2023, 10 (6): 562.
doi: 10.3390/aerospace10060562 |
| 16 | 王庆禄, 吴冯国, 郑成辰, 等. 基于优化人工势场法的无人机航迹规划[J]. 系统工程与电子技术, 2023, 45 (5): 1461. |
| 17 |
Goricanec J, Milas A, Markovic L, et al. Collision-free trajectory following with augmented artificial potential field using UAVs[J]. IEEE Access, 2023, 11, 83492.
doi: 10.1109/ACCESS.2023.3303109 |
| 18 | Ren C X, Fu F F, Yin C C, et al. Improved artificial potential field method based on robot local path information[J]. International Journal of Advanced Robotic Systems, 2024, 21(5). DOI: 10.1177/17298806241278172. |
| 19 |
Liu J L, Yan Y H, Yang Y H, et al. An improved artificial potential field UAV path planning algorithm guided by RRT under environment-aware modeling: theory and simulation[J]. IEEE Access, 2024, 12, 12080.
doi: 10.1109/ACCESS.2024.3355275 |
| 20 |
Sun M X, Xiao X T, Luan T T, et al. The path planning algorithm for UUV based on the fusion of grid obstacles of artificial potential field[J]. Ocean Engineering, 2024, 306, 118043.
doi: 10.1016/j.oceaneng.2024.118043 |
| 21 |
Shan D R, Zhang S S, Wang X F, et al. Path-planning strategy: adaptive ant colony optimization combined with an enhanced dynamic window approach[J]. Electronics, 2024, 13 (5): 825.
doi: 10.3390/electronics13050825 |
| 22 | 余婧, 吴晓军, 蒋安林, 等. 基于多精度规划窗口的无人机航迹规划方法研究[J]. 系统工程与电子技术, 2024, 46 (5): 1767. |
| 23 | Nie J, Xie W Q, Zhang H, et al. Research on optimal vehicle path algorithm based on improved ant colony algorithm[C]// SPIE International Conference on Optics, Electronics, and Communication Engineering, 2024: 604. |
| 24 | 时维国, 宁宁, 宋存利, 等. 基于蚁群算法与人工势场法的移动机器人路径规划[J]. 农业机械学报, 2023, 54 (12): 407. |
| 25 | Wang S C, Zhang Z A, Huang X G. Research on path planning based on improved ant colony algorithm[C]// SPIE Third International Conference on Artificial Intelligence and Computer Engineering, 2023: 1402. |
| 26 |
Tian Y, Zhang J, Wang Q, et al. Application of hybrid algorithm based on ant colony optimization and sparrow search in UAV path planning[J]. International Journal of Computational Intelligence Systems, 2024, 17 (1): 286.
doi: 10.1007/s44196-024-00652-z |
| 27 | Wu J K, Luo Y, Zhang X F. Path planning of mobile robot based on ant colony algorithm-improved genetic algorithm[C]// SPIE Conference on Optical Metrology and Inspection for Industrial Applications XI, 2024: 311. |
| 28 |
Ma J W, Ma X Y, Zang S F. Multidestination path planning based on ant colony decision and rolling control[J]. IEEE Trans. on Aerospace and Electronic Systems, 2024, 60 (6): 8667.
doi: 10.1109/TAES.2024.3434777 |
| 29 | Yang F, Fang X, Gao F, et al. Obstacle avoidance path planning for UAV based on improved RRT algorithm[J]. Discrete Dynamics in Nature and Society, 2022, 2022 (1): 4544499. |
| 30 | Feng K, He X Y, Wang M L, et al. Path optimization of agricultural robot based on immune ant colony: B-spline interpolation algorithm[J]. Mathematical Problems in Engineering, 2022, 2022 (1): 2585910. |
| 31 |
Yang L W, Fu L X, Li P, et al. An effective dynamic path planning approach for mobile robots based on ant colony fusion dynamic windows[J]. Machines, 2022, 10 (1): 50.
doi: 10.3390/machines10010050 |
| [1] | 周思岐, 王良明, 傅健. 基于改进红鸢算法的巡飞弹航迹规划[J]. 系统工程与电子技术, 2026, 48(9): 3191-3201. |
| [2] | 林文斌, 时晨光, 严牧, 汪飞, 周建江. 面向欺骗干扰组网雷达的无人机集群稳健航迹规划算法[J]. 系统工程与电子技术, 2026, 48(5): 1551-1563. |
| [3] | 胡杰, 褚瑞峰, 朱倚娴, 陈平, 鲍帆. 基于VPPSO算法的无人机三维航迹规划[J]. 系统工程与电子技术, 2026, 48(5): 1738-1751. |
| [4] | 陆则宇, 王瑶, 吴蔚楠, 孙亦鸣, 龚春林. 三维动态环境下的无人机集群双层航迹规划[J]. 系统工程与电子技术, 2026, 48(1): 132-143. |
| [5] | 闻雯, 时晨光, 周建江. 多元威胁环境下无人机集群隐身航迹规划算法[J]. 系统工程与电子技术, 2025, 47(9): 2971-2984. |
| [6] | 杨知沐, 张绍杰, 张朝原, 王浩宇, 赵卯卯. 基于微分博弈的导弹避撞协同制导律设计[J]. 系统工程与电子技术, 2025, 47(8): 2667-2675. |
| [7] | 刘伊婕, 姜斌, 马亚杰, 李文博, 刘成瑞. 无人艇编队避碰路径规划与重规划[J]. 系统工程与电子技术, 2025, 47(6): 1964-1974. |
| [8] | 熊子淳, 刘永善. 针对低速目标的飞行器中段航迹快速规划[J]. 系统工程与电子技术, 2024, 46(7): 2424-2436. |
| [9] | 李杰, 谭跃进. 基于集成改进蚁群算法的作战环推荐方法[J]. 系统工程与电子技术, 2024, 46(6): 2002-2012. |
| [10] | 余婧, 吴晓军, 蒋安林, 雍恩米. 基于多精度规划窗口的无人机航迹规划方法研究[J]. 系统工程与电子技术, 2024, 46(5): 1767-1776. |
| [11] | 张海阔, 孟秀云. 基于改进RRT*算法的无人机在线航迹规划[J]. 系统工程与电子技术, 2024, 46(12): 4157-4164. |
| [12] | 金鑫, 贺宇峰. 基于SysML的空间有效载荷测试路径自动生成方法[J]. 系统工程与电子技术, 2024, 46(10): 3416-3426. |
| [13] | 刘玉杰, 李樾, 韩维, 崔凯凯. 基于改进凸优化算法的多机编队突防航迹规划[J]. 系统工程与电子技术, 2023, 45(9): 2819-2830. |
| [14] | 陈子豪, 李娟, 刘畅, 李杰, 刘笑宇. 时间约束下对地面目标协同攻击任务规划方法[J]. 系统工程与电子技术, 2023, 45(8): 2353-2360. |
| [15] | 权申明, 王松艳, 晁涛, 杨明. 基于改进人工势场法的再入制导方法[J]. 系统工程与电子技术, 2023, 45(7): 2158-2169. |
| 阅读次数 | ||||||
|
全文 |
|
|||||
|
摘要 |
|
|||||
